Related Experiment Video
Updated: May 25, 2025


Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
An improved A* algorithm for generating four-track trajectory planning to adapt to longitudinal rugged terrain
Zhi-Guang Liu1, Hai-Nan Yang1, Qin-Cong Wang1
1School of Control and Mechanical Engineering, Tianjin Chengjian University, Tianjin, 300384, China.

Abstract:
A four-wheeled robot can stride through longitudinal trenches to adapt to terrain challenges and effectively reach the target position in unstructured space, thus achieving navigation in rough terrain. Establishing a trajectory planning method to plan four paths simultaneously is necessary. Firstly, a grid map is based on the longitudinal trench terrain. Secondly, according to the robot's four-wheel size and chassis height, the robot can safely stand in the grid sequence. Finally, the minimum chassis and road height and the maximum roll Angle are added to the objective cost function of the traditional A* algorithm. An improved A* algorithm plans a four-wheel straddling path through the longitudinal ditch in the safe standing sequence. Simulation experiments prove that proposed method can effectively plan the four-wheel path on complex terrain. The planned path can be changed according to the adjustment of the weight values corresponding to the distance to the target, the minimum distance from the chassis to the ground, and the roll Angle. Such changes prove that the proposed method can effectively plan the path according to the actual situation, focusing on the speed (whether the path planning can be carried out) and the safety (whether the bottom dragging and rollover can be considered). The actual experiment proves that the robot can cross the longitudinal ditch in the form of left and right wheels. When the distance is about 10.5 m, the robot can pass through the longitudinal ditch quickly and safely in 19.8 s at a speed of 0.53 m/s, keeping the robot's tilt angle less than 20°.

Related Concept Videos
 01:12
Adjusting a Traverse
 01:25
Design Example: Traverse Angle Computations
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:27
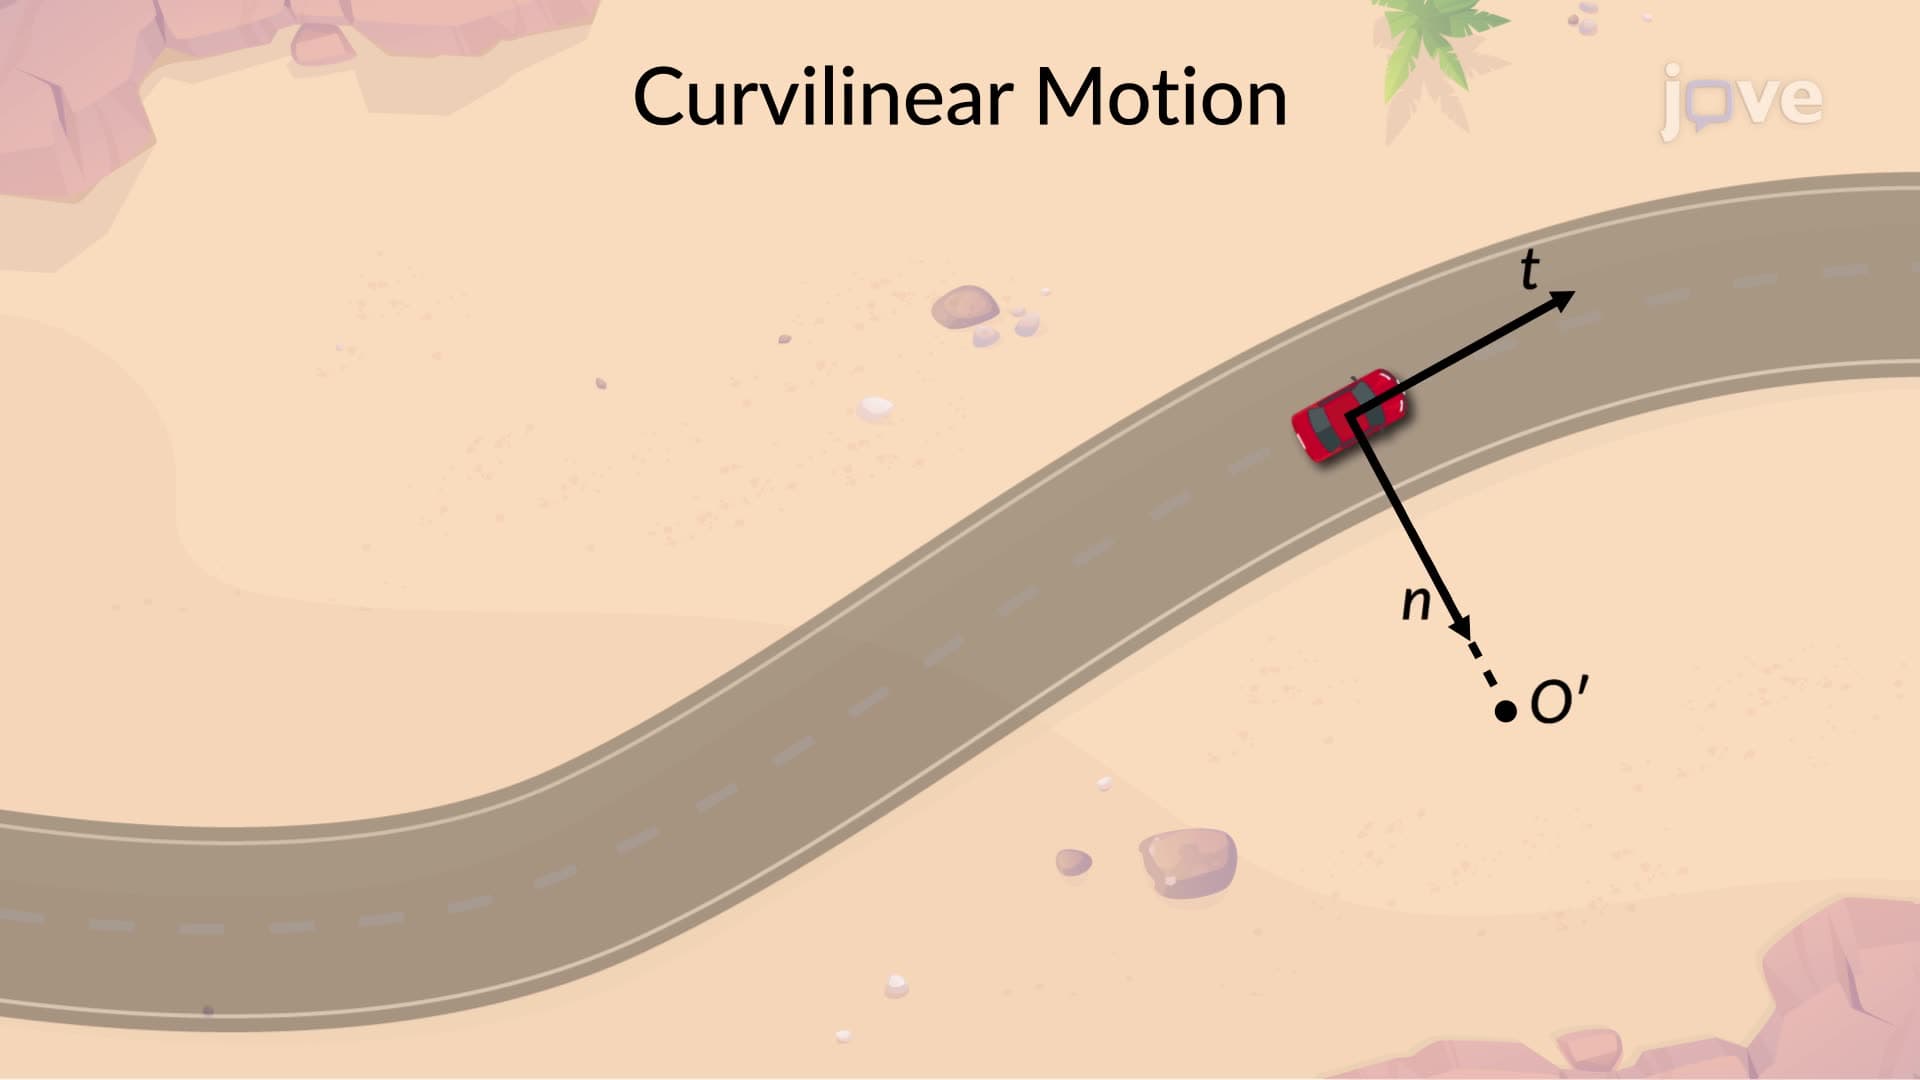
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:10
Relative Motion Analysis - Acceleration