Related Experiment Video
Updated: May 24, 2025
Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
Three-dimensional computational musculoskeletal model for estimating force-impedance control during dynamic upper

Abstract:
The human neuromusculoskeletal system learns and adapts the upper limb impedance to new task dynamics, enhancing task performance and stability. This study aimed to develop and validate a realistic neuromusculoskeletal model of the upper limb capable of predicting stiffness modulation and motor adaptation to newly introduced environments and force fields. We employed an inverse task space dynamics approach with a multipriority task control framework for an existing upper limb model in OpenSim (Stanford, CA, USA). The task space controller was responsible for planning and executing muscle-driven goal-oriented movements for the arm while stabilizing these movements against disturbances. We performed simulations involving longitudinal and transverse reaching movements in a horizontal plane at the shoulder level and used the concept of short-range-stiffness to map the stiffness of muscle-tendon units onto end-limb stiffness. Additionally, we studied motor adaptations for longitudinal reaching movements in presence of three position-based divergent force fields and a velocity-dependent force field. Qualitatively, the proposed model and simulations accurately predicted previously reported, experimental end-limb stiffness properties. Our preliminary results indicated the potential of the proposed computational approach for estimating end-limb stiffness parameters. Future studies are needed to more rigorously validate the model by quantifying the level of agreement between the model and experimental measurements for more upper extremity tasks.
More Related Videos

Related Concept Videos
 01:30
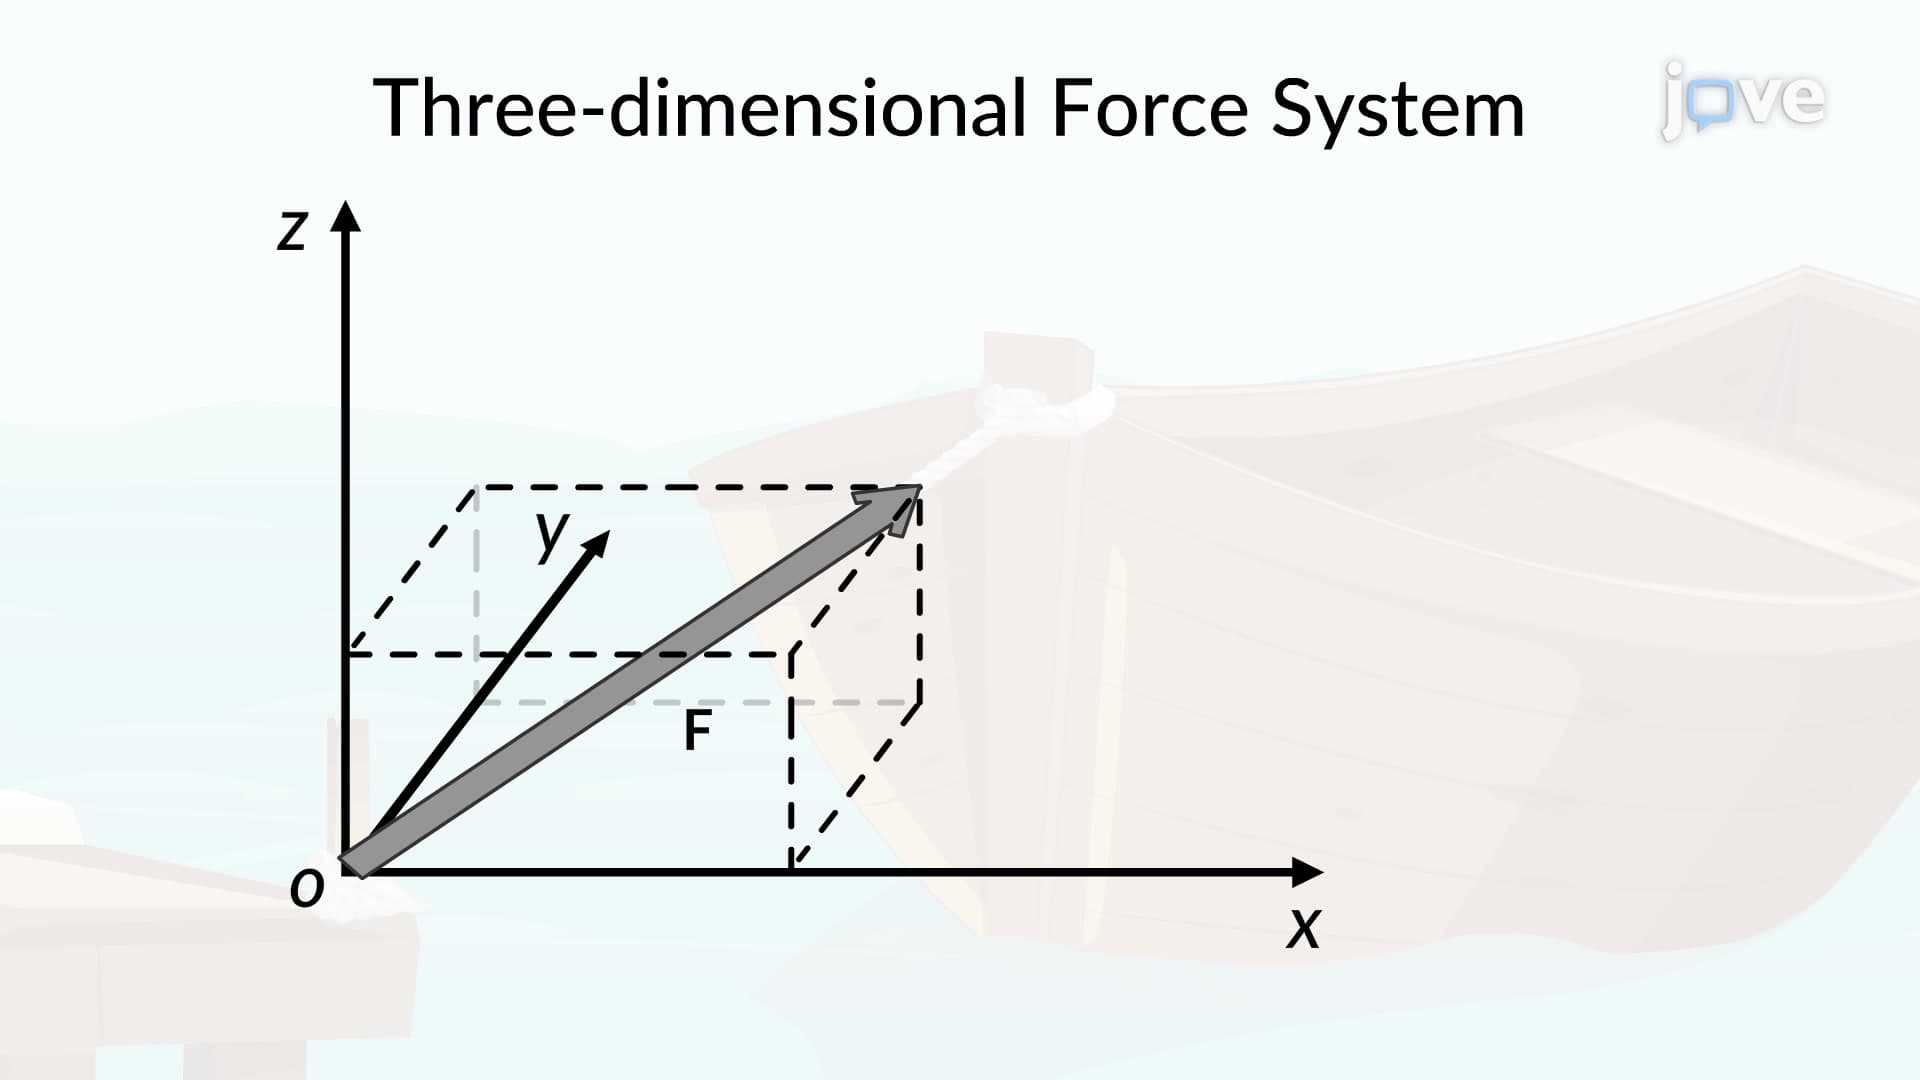
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:20
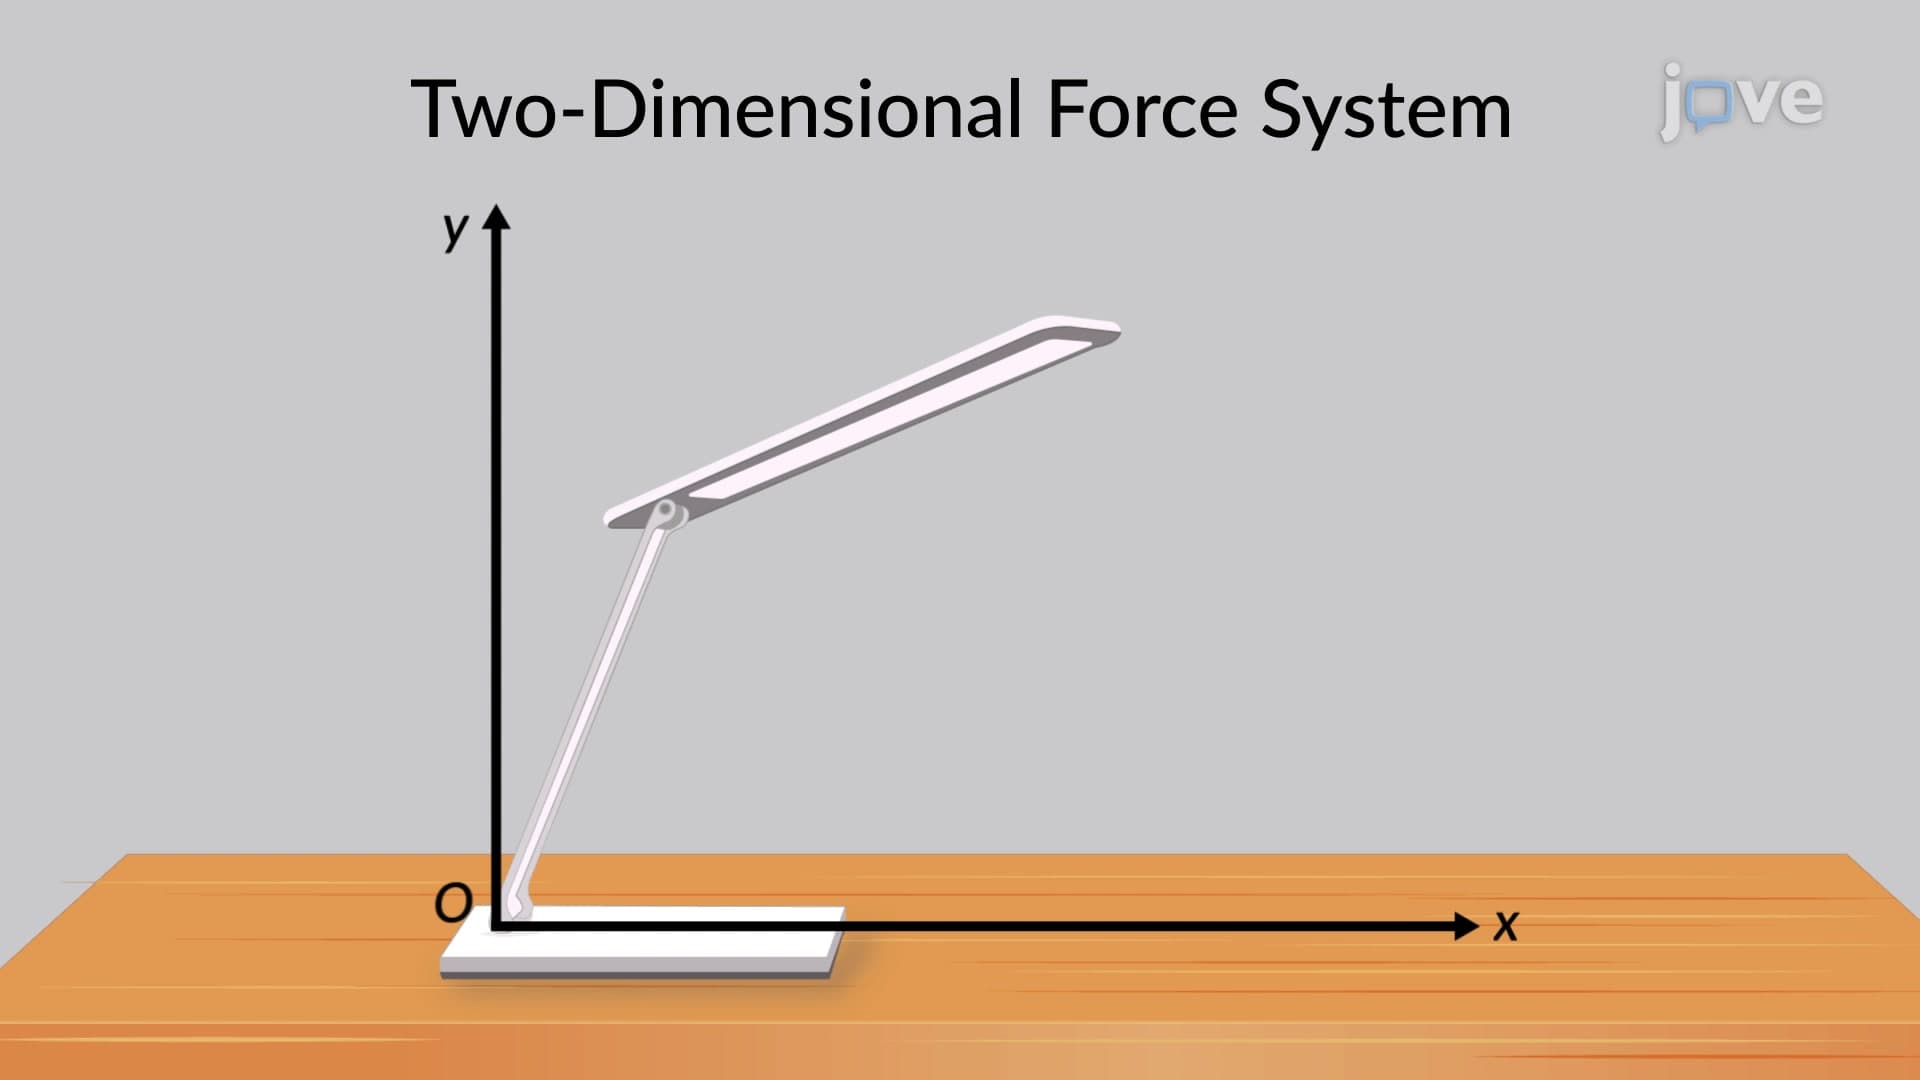
Two-Dimensional Force System