Related Experiment Video
Updated: May 24, 2025


Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
Estimating model parameters of a mathematical model for hand motion during cylindrical grasps

Abstract:
This paper presents parameter estimation for the passive moment and musculoskeletal scaling coefficients of a mathematical model describing the equations of motion of human finger segments. A novel musculoskeletal model was used as the actuator and parameter estimation was performed by least squares optimization of the differences between angular data from a motion capture system, and the solutions to the equations of motion of our model. The parameter estimates determined are unique to the individual and the dataset. Model fits show good agreement with filtered data R2 = 0.98. The hope is that this model and approach can be used to determine the passive moment and musculoskeletal scaling coefficients for all types of grasps.

Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:13
Angle of Twist: Problem Solving
 00:49
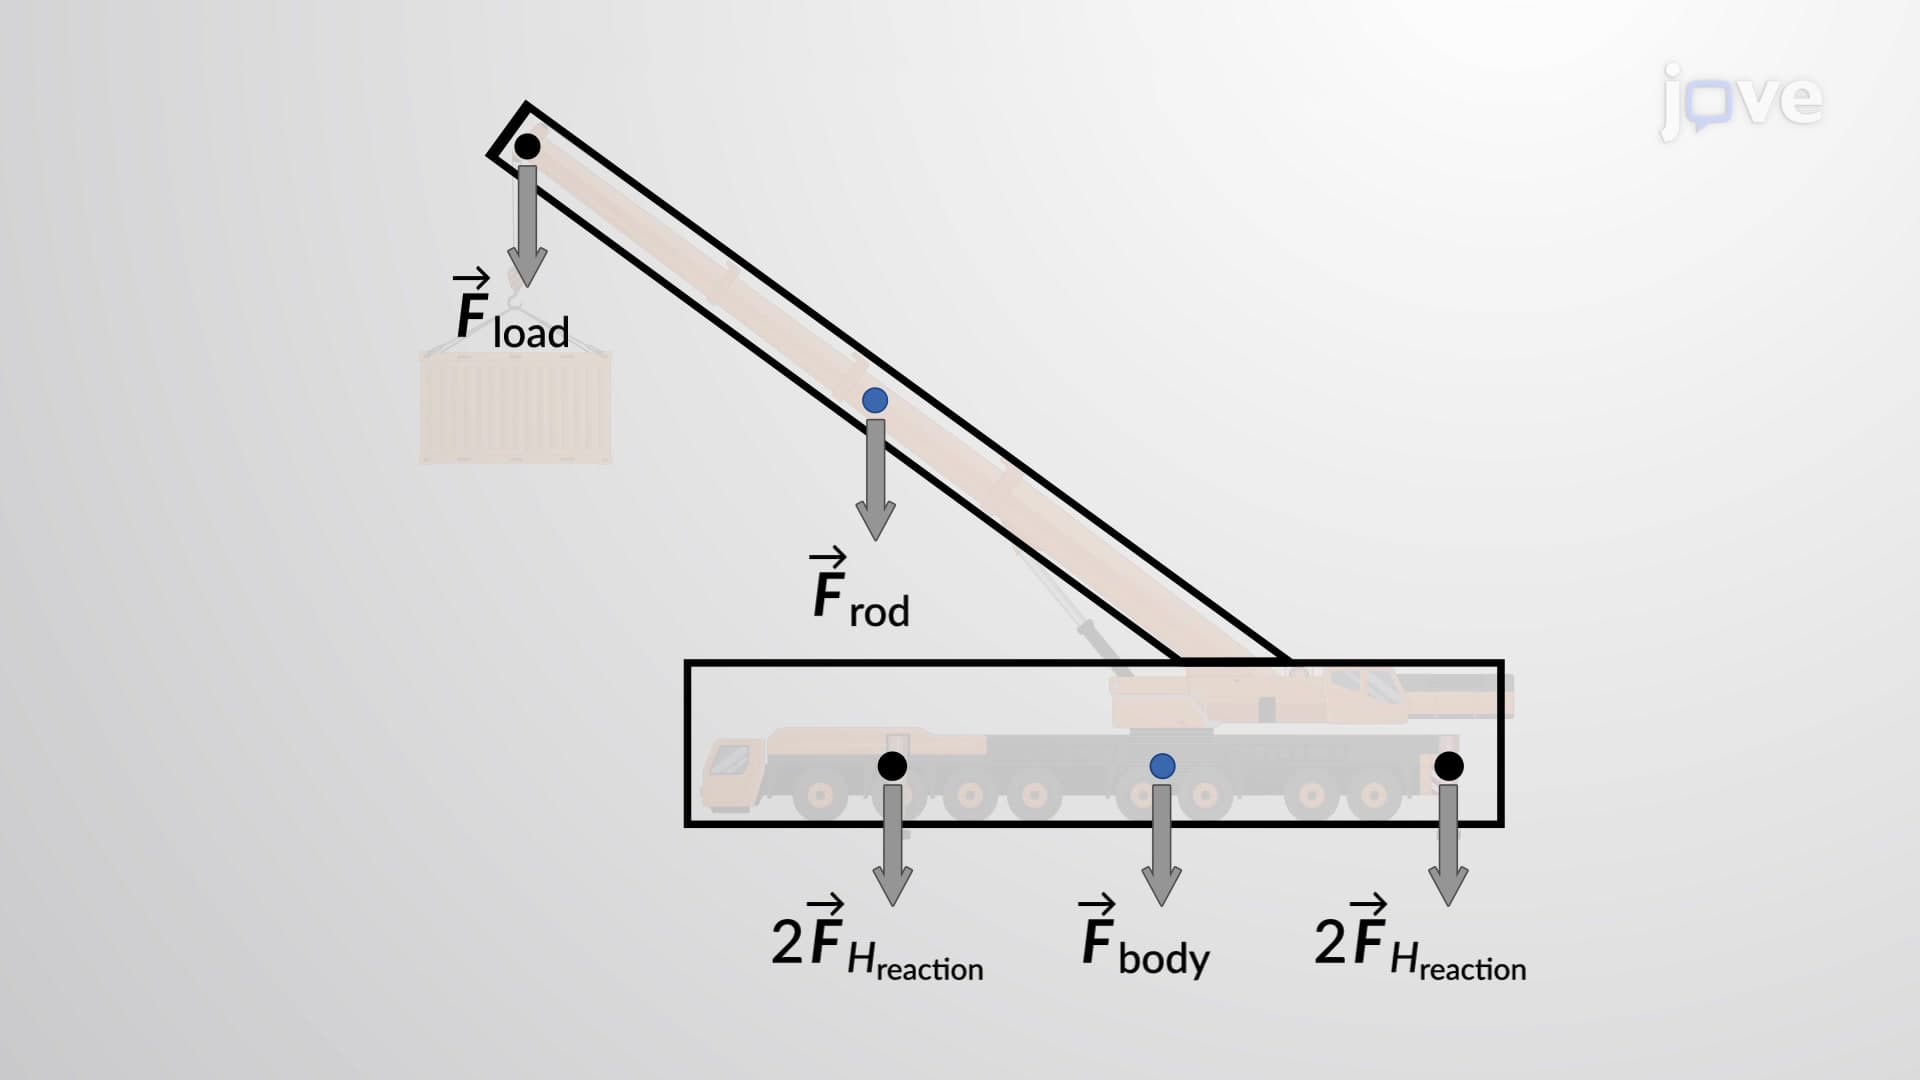
Rigid Body Equilibrium Problems - I
 01:17
Rolling Resistance: Problem Solving