Related Experiment Video
Updated: May 24, 2025
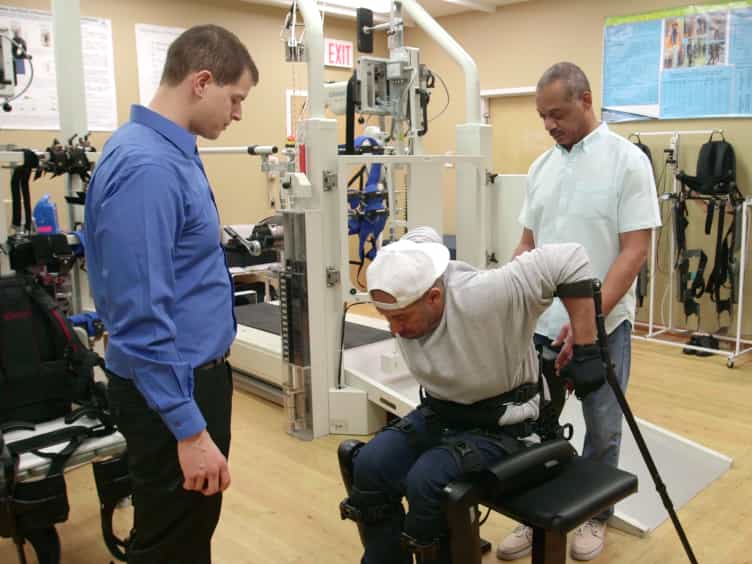

Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
Exploring the Impact of Continuous Mediolateral Torque Application by Hip Exoskeleton on the Gait Balance of

Abstract:
This preliminary study investigates the potential of mediolaterally active robotic hip exoskeleton to influence mediolateral balance of non-disabled individuals. As no prior study has specifically demonstrated their impact on frontal plane gait balance, the primary objective was to examine the effects of a hip exoskeleton applying continuous mediolateral torque on predominant balance metrics commonly used in balance evaluation. Participants experienced continuous abduction/adduction torque application under 5 experimental conditions. In the first condition, they walked without any torque application. Then subjects allowed exoskeleton to alter their step width, while in the other two conditions, they actively resisted any change in step width. In walking modes where step width changed, the results showed significant impacts on balance metrics, indicating consistent trends in frontal plane when evaluated using net external moment, trunk sway, and Margin of Stability. Notably, hip exoskeleton resulted in step width changes inducing pronounced effects, while resisting torque with maintained step width showed less pronounced alterations. This research can provide valuable insights for designing and implementing control methods for mediolaterally active robotic hip exoskeletons, with the potential to enhance mediolateral balance for individuals with compromised sensorimotor integration or disrupted hip muscle strength.

