Unsupervised Non-Rigid Human Point Cloud Registration Based on Deformation Field Fusion
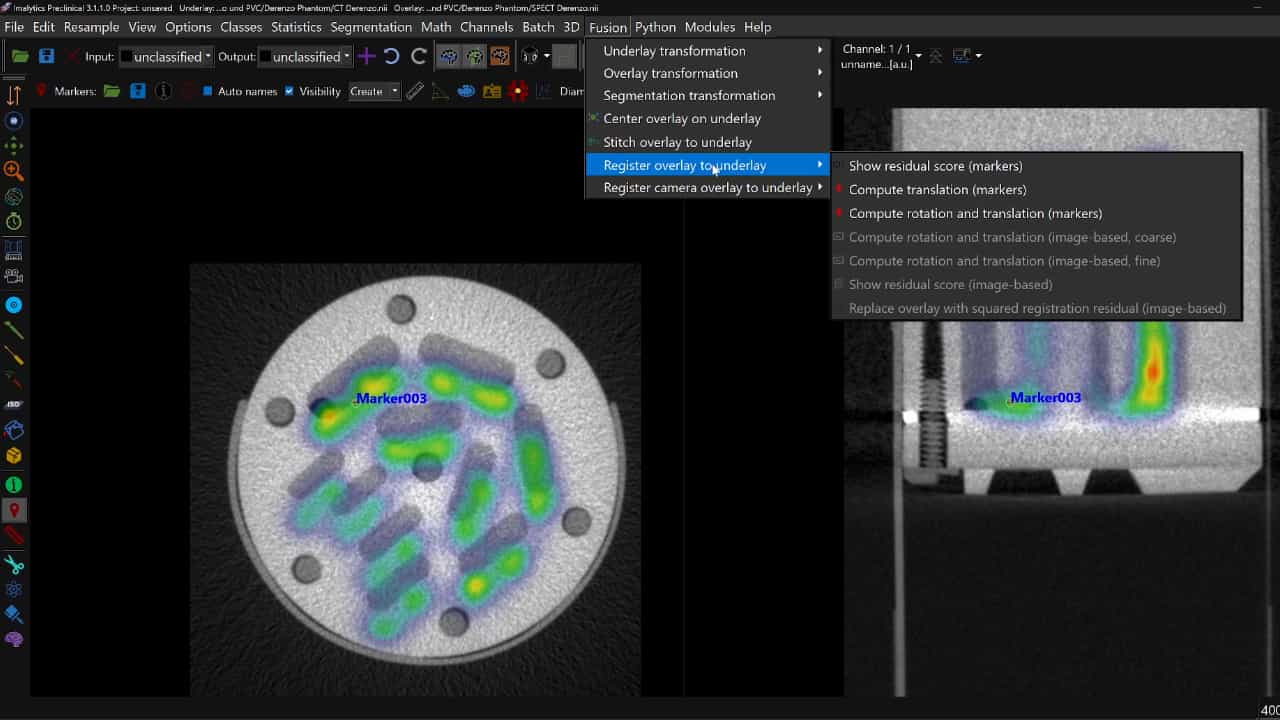
Related Experiment Video
Updated: Jul 15, 2026
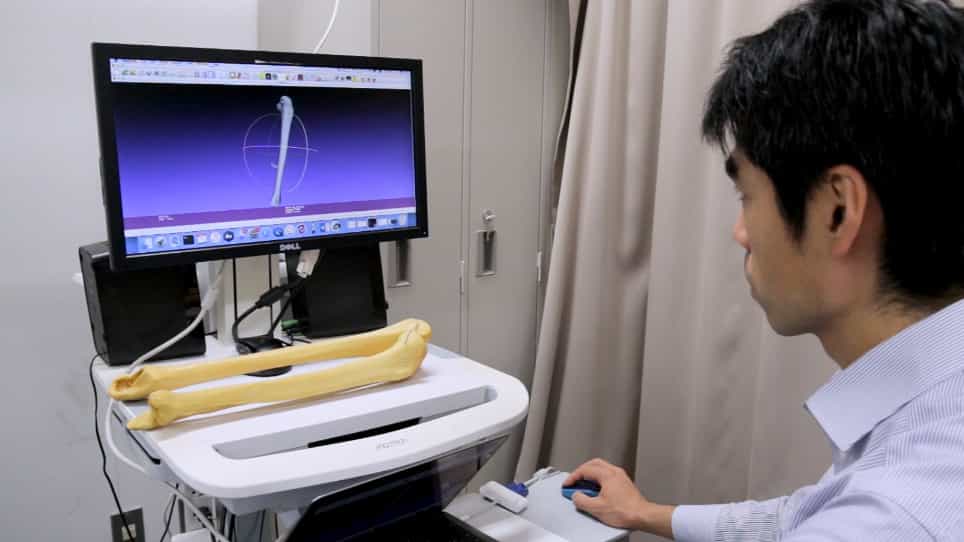
Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019

Abstract:
Human point cloud registration is a critical problem in the fields of computer vision and computer graphics applications. Currently, due to the presence of joint hinges and limb occlusions in human point clouds, point cloud alignment is challenging. To address these two limits, this paper proposes an unsupervised non-rigid human point cloud registration method based on deformation field fusion. The method mainly consists of the deep dynamic link deformation field estimation module and the probabilistic alignment deformation field estimation module. The deep dynamic link deformation field estimation module uses a time series network to convert non-rigid deformation into multiple rigid deformations. Then, feature extraction is performed to estimate the deformation field based on the rigid deformations. The probabilistic alignment deformation field estimation module builds on a Gaussian mixture model and adds local and global constraint conditions for deformation field estimation. Finally, the two deformation fields are fused into the total deformed field by aligning them, which enhances the sensitivity to both global and local feature information. The experimental results on public datasets and real private datasets demonstrate that the proposed method has higher accuracy and better robustness under joint hinges and limb adhesion conditions.
Related Concept Videos
 01:11
Deformation of Member under Multiple Loadings
In the case of a member with a variable cross-section, the strain is not constant but depends on the position. The deformation of an...
 01:12
Temperature Dependent Deformation
 01:18
Deformations in a Symmetric Member in Bending
When the member is segmented into tiny cubic elements, it is observed that the primary stress...