Related Experiment Video
Updated: May 6, 2026
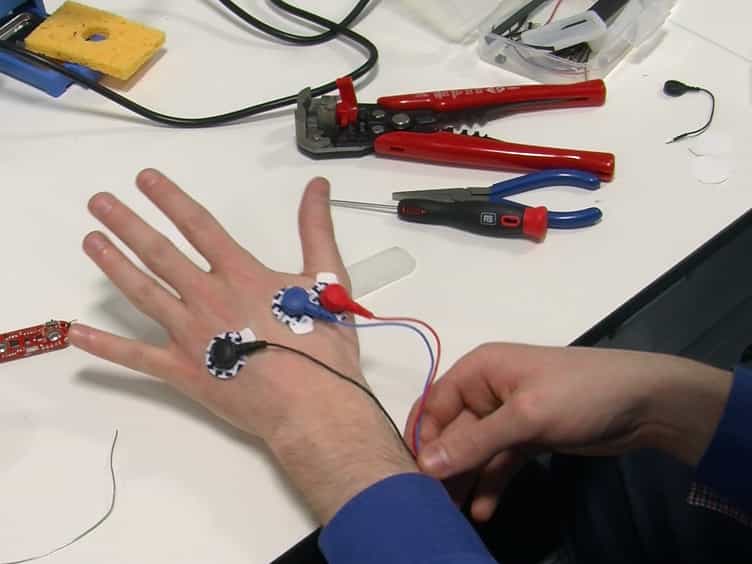

The Bionic Clicker Mark I & II
Published on: August 14, 2017
Soft robotic hand with tactile palm-finger coordination
Ningbin Zhang1, Jieji Ren1, Yueshi Dong1
1Robotics Institute, School of Mechanical Engineering, Shanghai Jiao Tong University, Shanghai, China.

Abstract:
Soft robotic hands with integrated sensing capabilities hold great potential for interactive operations. Previous work has typically focused on integrating sensors with fingers. The palm, as a large and crucial contact region providing mechanical support and sensory feedback, remains underexplored due to the currently limited sensing density and interaction with the fingers. Here, we develop a sensorized robotic hand that integrates a high-density tactile palm, dexterous soft fingers, and cooperative palm-finger interaction strategies. The palm features a compact visual-tactile design to capture delicate contact information. The soft fingers are designed as fiber-reinforced pneumatic actuators, each providing two-segment motions for multimodal grasping. These features enable extensive palm-finger interactions, offering mutual benefits such as improved grasping stability, automatic exquisite surface reconstruction, and accurate object classification. We also develop palm-finger feedback strategies to enable dynamic tasks, including planar object pickup, continuous flaw detection, and grasping pose adjustment. Furthermore, our development, augmented by artificial intelligence, shows improved potential for human-robot collaboration. Our results suggest the promise of fusing rich palm tactile sensing with soft dexterous fingers for advanced interactive robotic operations.


Related Concept Videos
 01:16
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi...
 01:14
Design Example: Resistive Touchscreen
When a user touches the screen, the two layers make contact at a specific point known as the touchpoint. This contact reduces the resistance between...