Related Experiment Video
Updated: Jun 23, 2026


Rod-based Fabrication of Customizable Soft Robotic Pneumatic Gripper Devices for Delicate Tissue Manipulation
Published on: August 2, 2016
Enhancing dexterity: Soft pneumatic actuation utilizing granular jamming for a human finger flexo-extension
X Yamile Sandoval-Castro1, J German Cortes-Gonzalez2, Maximiano F Ruiz-Torres2
1Department of Mechatronics, School of Engineering and Sciences, Tecnologico de Monterrey, Santiago de Querétaro, México.

Abstract:
This article presents a bioinspired pneumatic soft actuator designed to mimic the flexo-extension movement of the human finger, with a particular focus on stiffness modulation through granular jamming. Three-chamber geometries - honeycomb, rectangular, and half-round - were evaluated to optimize curvature performance, utilizing Mold Star 15 Slow elastomer for actuator fabrication. Granular jamming, both passive and active, was implemented within the inextensible layer using chia and quinoa grains to enhance stiffness modulation. Experimental results revealed that the honeycomb geometry most closely aligned with the natural index finger trajectory. Stiffness evaluations demonstrated a range of 0-0.47 N/mm/° for quinoa and 0-0.9 N/mm/° for chia. The actuator's force output increased by 16% for quinoa and 71% for chia compared to the nonjammed configuration. This enhanced performance is particularly beneficial for applications such as hand rehabilitation, where adaptive stiffness and force modulation are critical. Granular jamming, especially with active chia, provided superior adaptability for tasks requiring variable stiffness and resistance, making it a promising candidate for wearable robotic applications in rehabilitation.


Related Concept Videos
 01:05
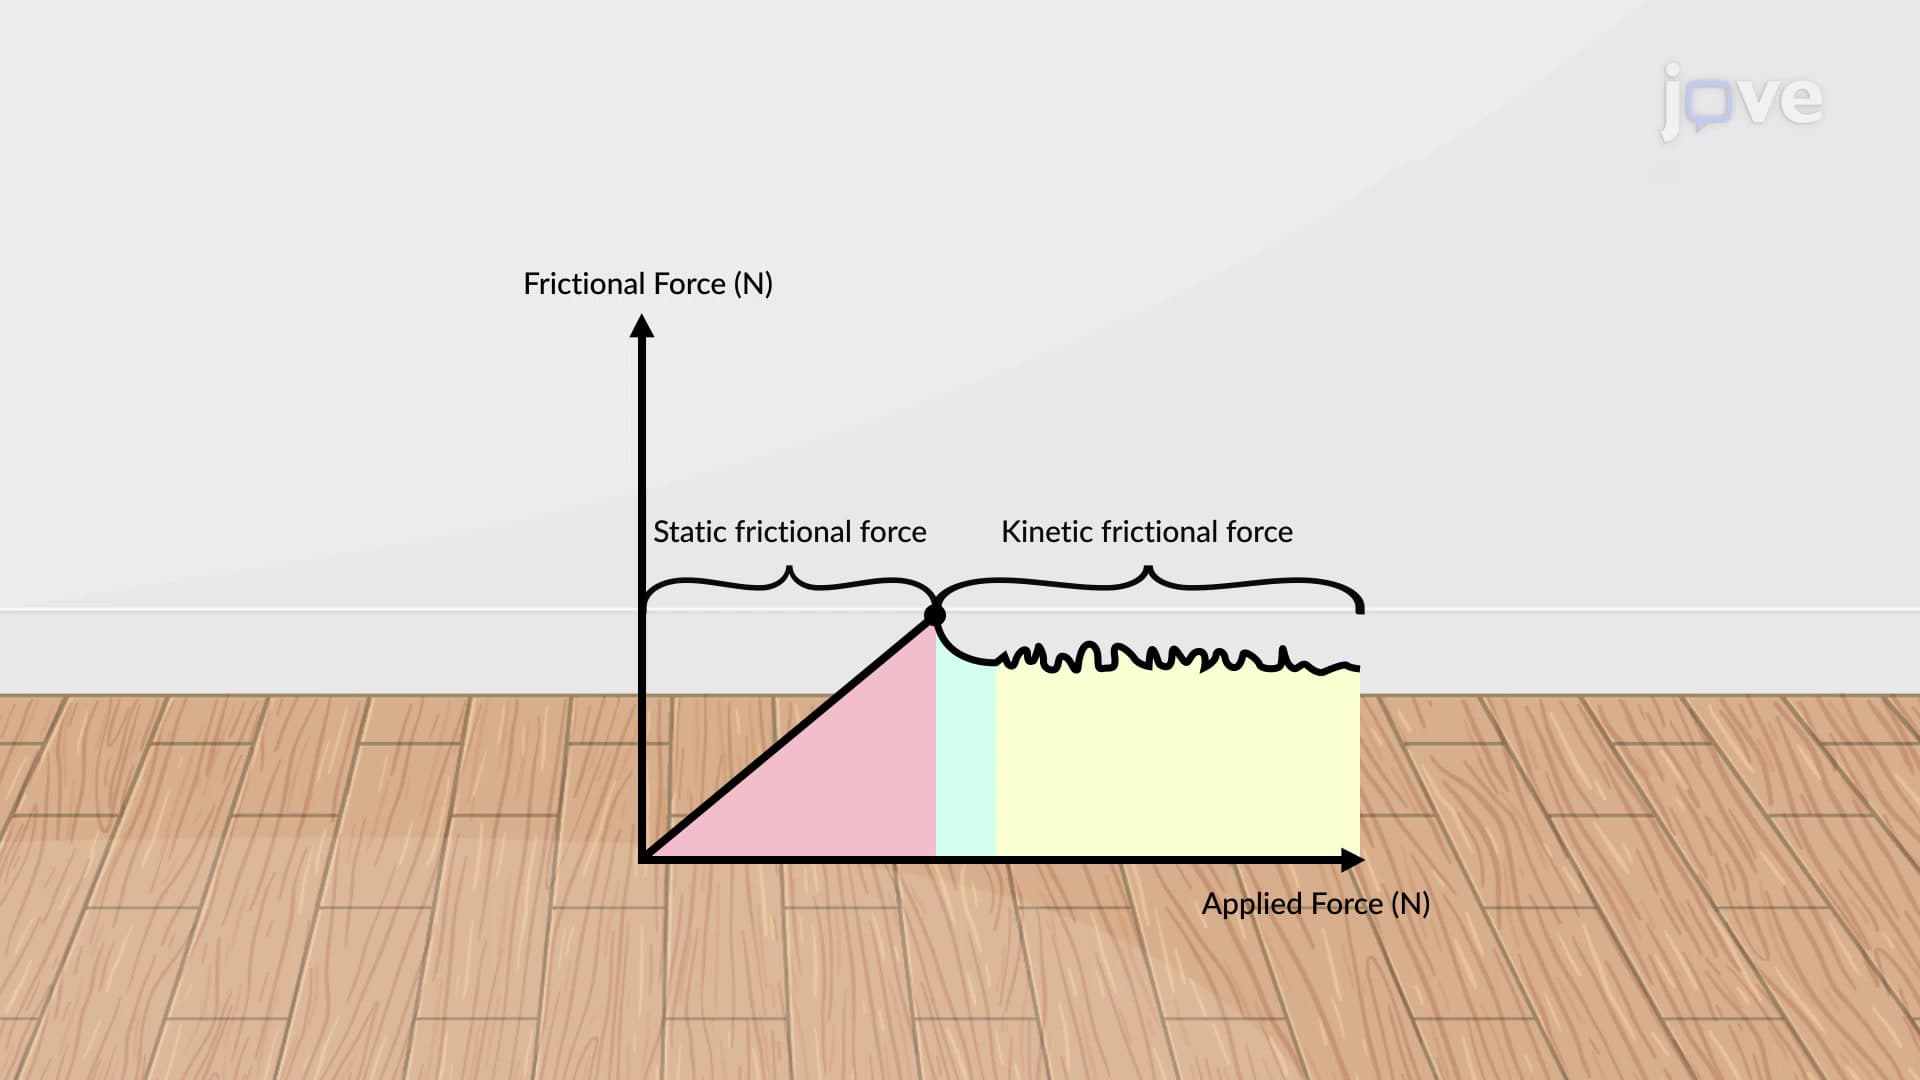
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:26
Kinetic Friction
 01:16
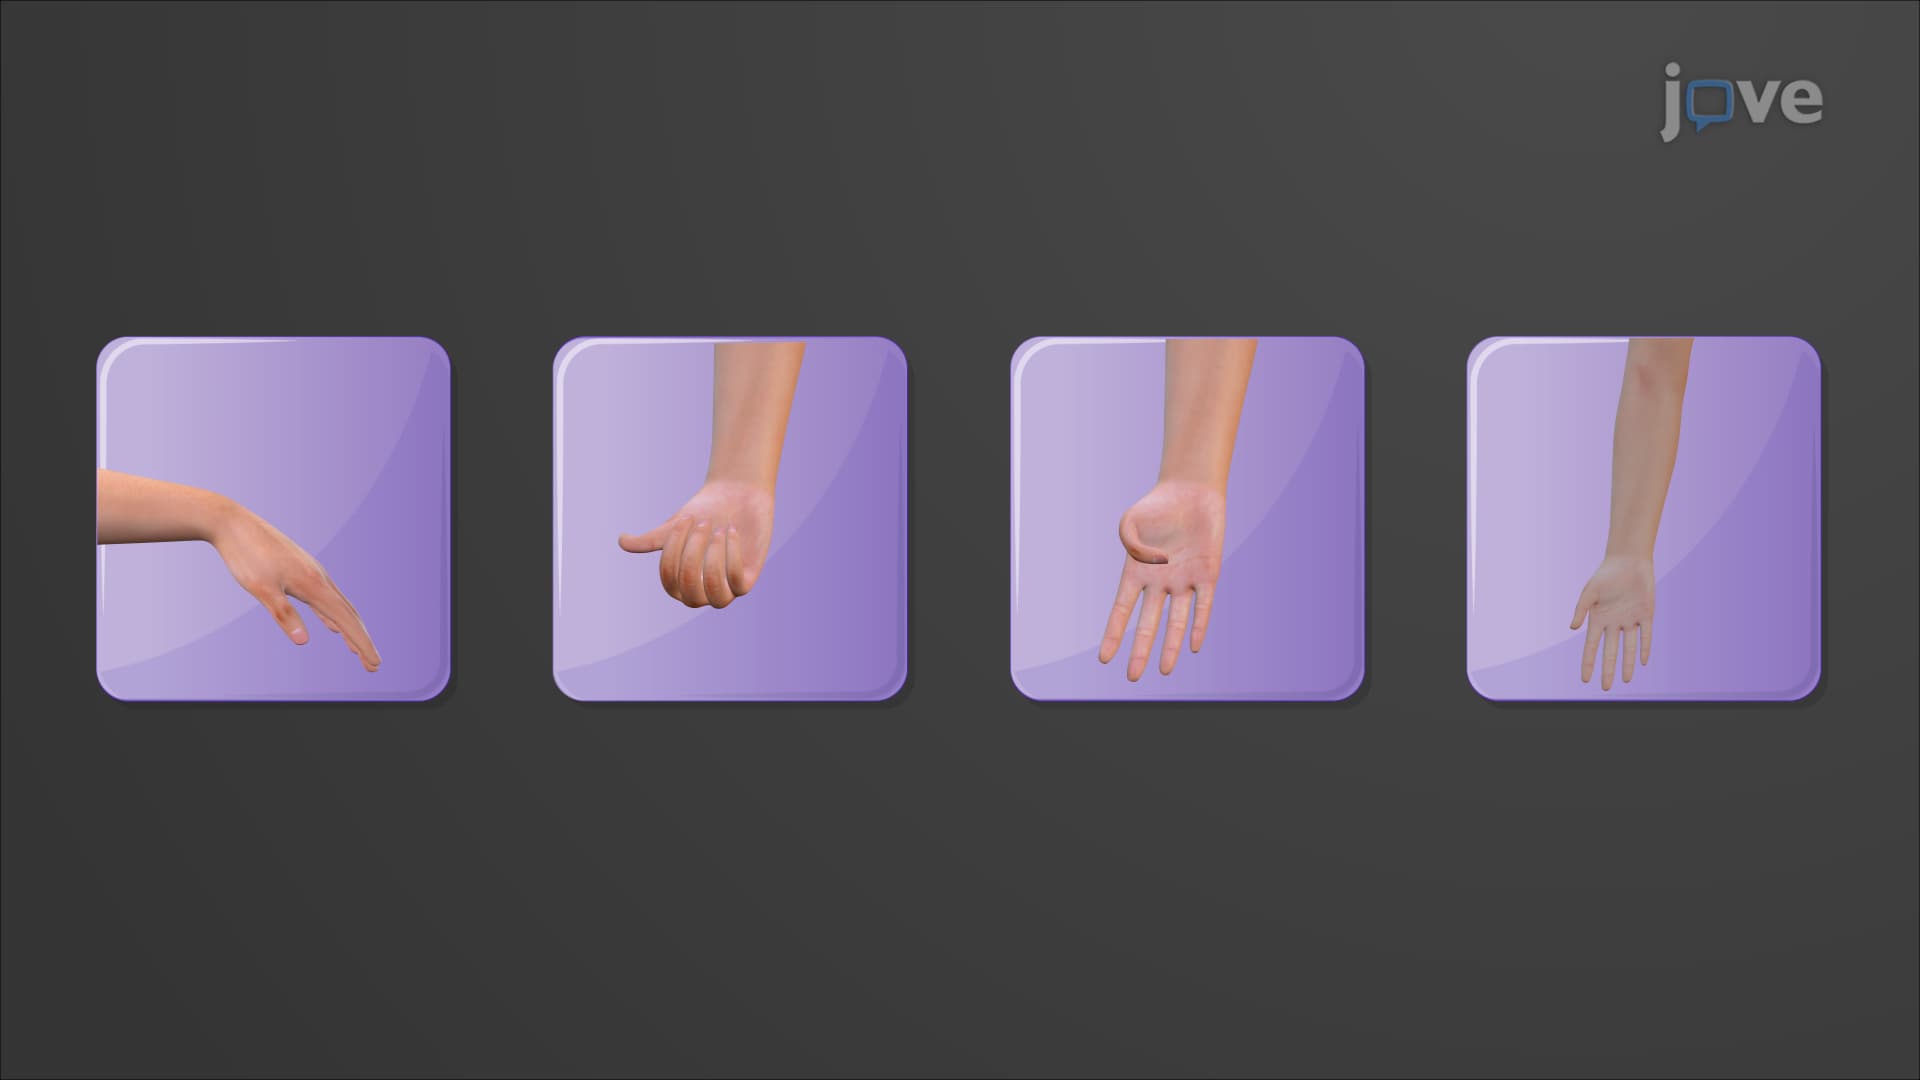
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi radialis,...