Related Experiment Video
Updated: May 3, 2026
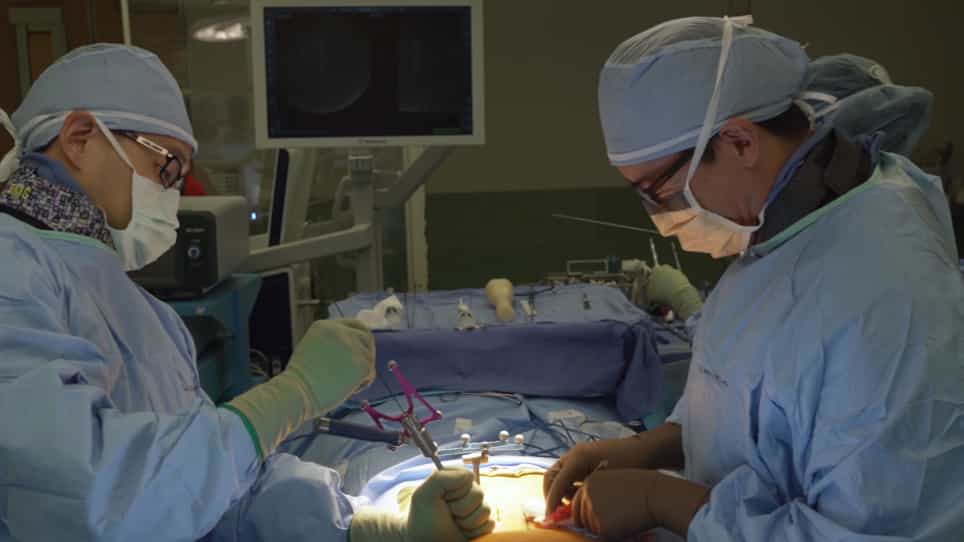

Cone Beam Intraoperative Computed Tomography-based Image Guidance for Minimally Invasive Transforaminal Interbody Fusion
Published on: August 6, 2019
A new method of accurate pedicle screw navigation
Daniel Suter1,2, Aidana Massalimova3, Christoph Johannes Laux4
1Research in Orthopedic Computer Science, University Hospital Balgrist, University of Zurich, Forchstrasse 340, Zurich, 8008, Switzerland. dapesu@bluewin.ch.

Abstract:
One of the most established approaches to navigate pedicle screws is the planning and alignment (PA) method. Thereby a trajectory and associated entry point (EP) is planned and navigated after referencing to patient anatomy. However, deviations from the planned EP potentially lead to an altered screw position. The aim of this study was to investigate the influence of these EP deviations and to examine possible alternative methods. The merits of two new points of reference (screw tip point STP and midpoint MP) were therefore analyzed. STP represents the point on the optimal screw tip, MP the point at the center/midportion of the pedicle at its narrowest portion. The adapted screw trajectory was defined as the directional vector from any chosen EP to the STP or MP. First, computer simulations were used to evaluate the performance of these new approaches. Subsequently, the navigation technique yielding more acceptable screws in case of an EP deviation was analyzed on phantom-sawbone models. Both new methods showed a significantly larger number of possible screw trajectories in the simulations (p < 0.01). Even with a deliberate deviation of 4.5 mm (IQR 3.3) from the optimal EP, a perforation-free screw diameter of 4.9 mm (IQR 5.7 mm) could be achieved using the new navigation techniques. The simulated perforations were mainly located laterally with a median of 8.45 mm (IQR 3.95) distance to the medial pedicle wall. The PA method seems to be susceptible to EP deviations. The STP and MP methods are possible improvement mechanisms to overcome this disadvantage.

Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:26
Errors in Global Positioning System
 01:30
Types of Global Positioning System Surveys