Related Experiment Video
Updated: May 21, 2025
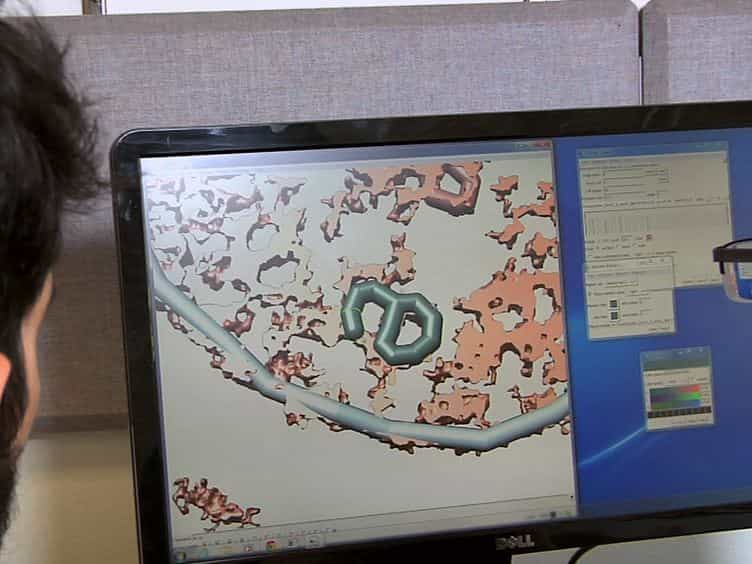
From Voxels to Knowledge: A Practical Guide to the Segmentation of Complex Electron Microscopy 3D-Data
Published on: August 13, 2014
Generating Inverse Feature Space for Class Imbalance in Point Cloud Semantic Segmentation

Abstract:
Point cloud semantic segmentation can enhance the understanding of the production environment and is a crucial component of vision tasks. The efficacy and generalization prowess of deep learning-based segmentation models are inherently contingent upon the quality and nature of the data employed in their training. However, it is often challenging to obtain data with inter-class balance, and training an intelligent segmentation network with the imbalanced data may cause cognitive bias. In this paper, a network framework InvSpaceNet is proposed, which generates an inverse feature space to alleviate the cognitive bias caused by imbalanced data. Specifically, we design a dual-branch training architecture that combines the superior feature representations derived from instance-balanced sampling data with the cognitive corrections introduced by the proposed inverse sampling data. In the inverse feature space of the point cloud generated by the auxiliary branch, the central points aggregated by class are constrained by the contrastive loss. To refine the class cognition in the inverse feature space, features are used to generate point cloud class prototypes through momentum update. These class prototypes from the inverse space are utilized to generate feature maps and structure maps that are aligned with the positive feature space of the main branch segmentation network. The training of the main branch is dynamically guided through gradients back propagated from different losses. Extensive experiments conducted on four large benchmarks (i.e., S3DIS, ScanNet v2, Toronto-3D, and SemanticKITTI) demonstrate that the proposed method can effectively mitigate point cloud imbalance issues and improve segmentation performance.
Related Concept Videos
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:11
Residuals and Least-Squares Property
If the observed data point lies above the line, the residual is positive, and the line underestimates the actual data value for y. If the observed data point lies below the line, the residual is negative, and the line overestimates the actual data value for y.
The process of fitting the best-fit...
 01:08
Outliers and Influential Points
 01:29
Aggregates Classification
Petrographic classification groups aggregates based on common mineralogical characteristics. Some of the common mineral groups found in aggregates are...
 01:22
Upsampling
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....