

Decoupling compensation accuracy from sensor misalignment: A generalized black-box model for gravity gradiometers
Mingbiao Yu1, Yu Liang2, Xiaobing Yu2
1Key Laboratory of Advanced Manufacturing Technology of the Ministry of Education, School of Mechanical Engineering, GuiZhou University, Guiyang 550025, China.

Abstract:
Moving-base gravity gradiometers are widely used in applications such as mineral exploration and passive navigation; however, their high sensitivity to platform motion presents significant challenges in compensating for motion-induced errors. Existing methods rely on precise alignment between motion sensors and the gradiometer's coordinate system, making compensation accuracy heavily dependent on sensor installation precision. To address this issue, we propose a novel generalized black-box modeling method for motion error compensation in gravity gradiometers. By incorporating sensor misalignment directly into the model, our approach effectively decouples compensation accuracy from installation precision. Constructed based on the gradiometer's dynamic characteristics and the excitation and input-output behavior of its sensitive components, the black-box model inherently avoids redundant operational terms, reduces multicollinearity, and lowers computational resource requirements. Validation through numerical simulations in a dynamic 0.1g environment demonstrates that the output consistency between the black-box and analytical models reaches 10-10, achieving an compensation accuracy of 0.1E. Furthermore, experimental results using a gravity gradiometer prototype confirm the model's effectiveness in real-world conditions. The proposed method significantly reduces motion errors induced by 1mg linear motion and 0.001rad/s angular motion, lowering the noise level to 4ng/Hz, approaching the static inherent noise level of 1ng/Hz. These results verify the black-box model's effectiveness and robustness in dynamic environments, highlighting its potential to enhance the practical performance of gravity gradiometers by mitigating motion-induced errors without stringent requirements on sensor installation precision.

Related Concept Videos
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:20
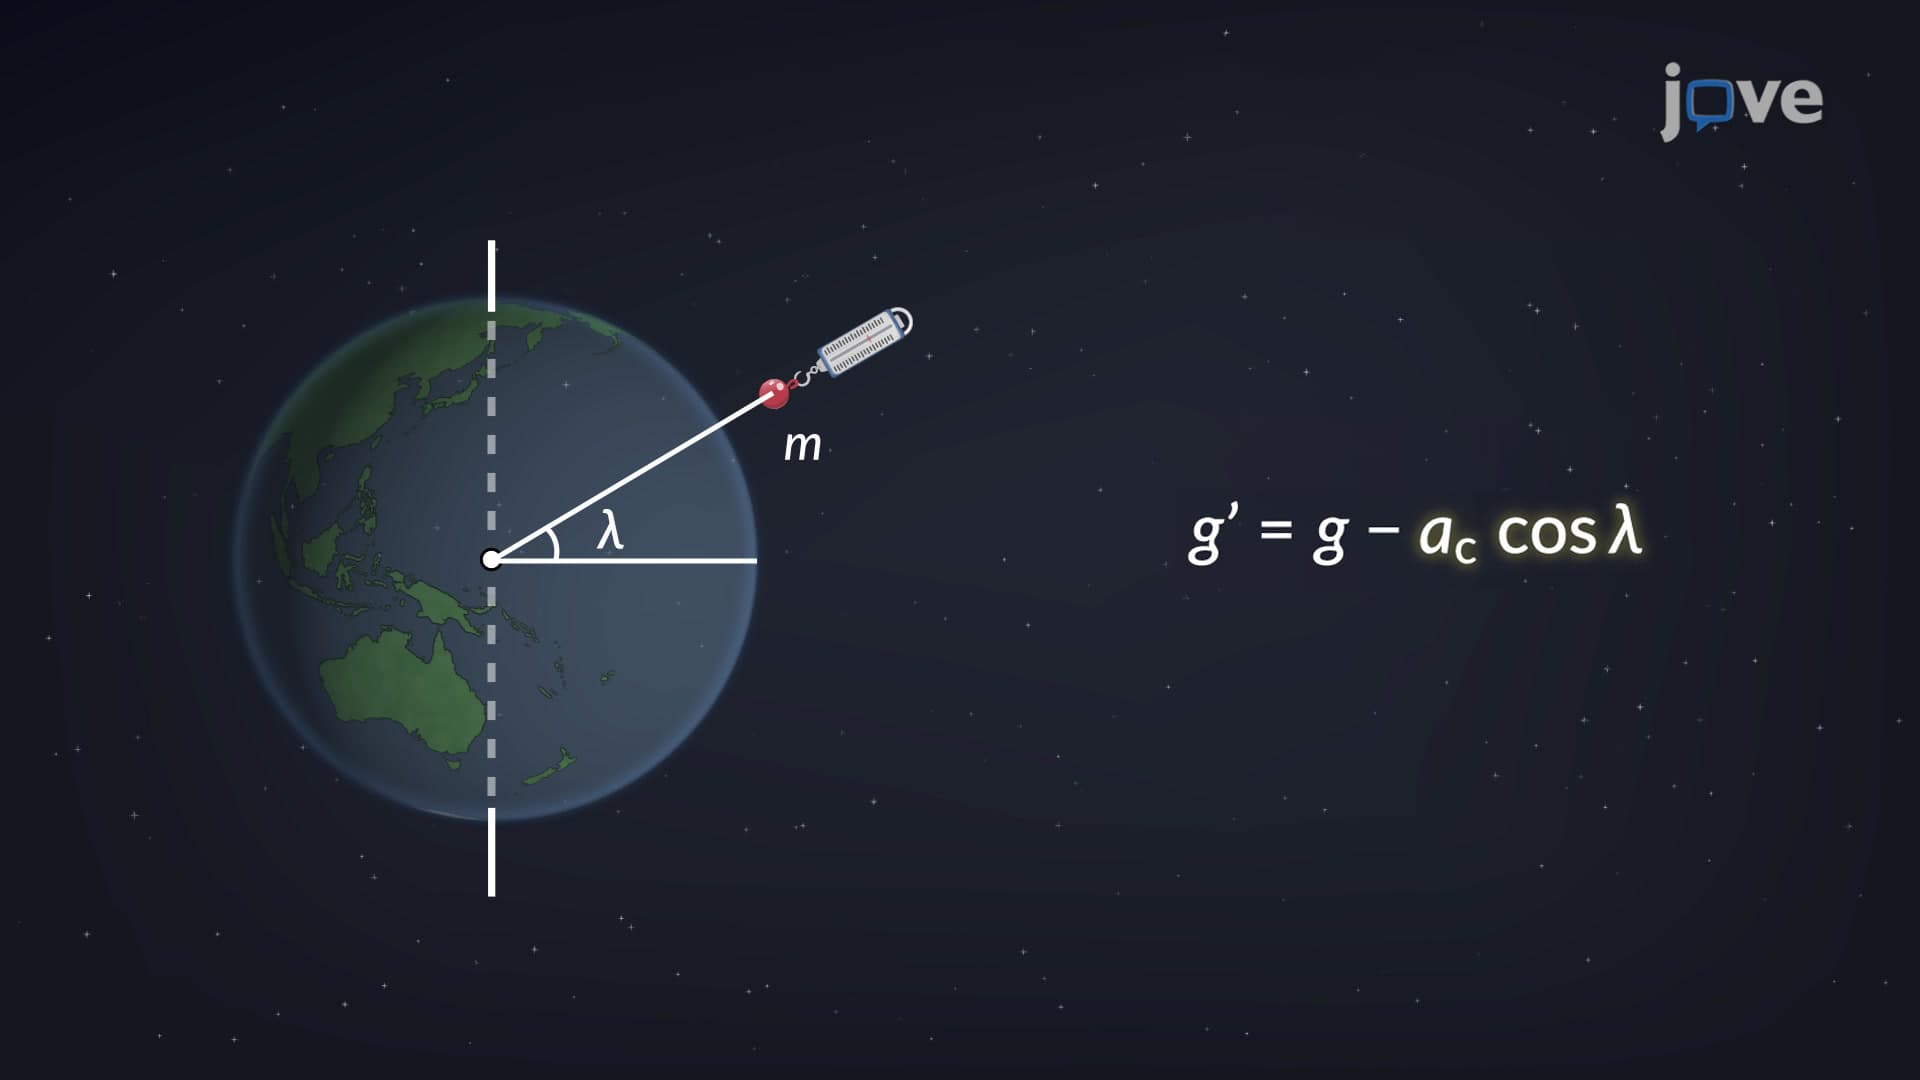
Variation in Acceleration due to Gravity near the Earth's Surface
The difference between the true and apparent weights is proportional to the square of the Earth's...
 01:26
Errors in Global Positioning System
 01:17
Common Leveling Mistakes and Errors
 01:28
Geoid and Ellipsoid
 01:15
Distance Corrections