Related Experiment Video
Updated: May 8, 2025

Designing and Implementing Nervous System Simulations on LEGO Robots
Published on: May 25, 2013
Training stiff neural ordinary differential equations with explicit exponential integration methods
Colby Fronk1, Linda Petzold2,3
1Department of Chemical Engineering, University of California, Santa Barbara, Santa Barbara, California 93106, USA.

Abstract:
Stiff ordinary differential equations (ODEs) are common in many science and engineering fields, but standard neural ODE approaches struggle to accurately learn these stiff systems, posing a significant barrier to the widespread adoption of neural ODEs. In our earlier work, we addressed this challenge by utilizing single-step implicit methods for solving stiff neural ODEs. While effective, these implicit methods are computationally costly and can be complex to implement. This paper expands on our earlier work by exploring explicit exponential integration methods as a more efficient alternative. We evaluate the potential of these explicit methods to handle stiff dynamics in neural ODEs, aiming to enhance their applicability to a broader range of scientific and engineering problems. We found the integrating factor Euler (IF Euler) method to excel in stability and efficiency. While implicit schemes failed to train the stiff van der Pol oscillator, the IF Euler method succeeded, even with large step sizes. However, IF Euler's first-order accuracy limits its use, leaving the development of higher-order methods for stiff neural ODEs an open research problem.
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:18
Second Order systems II
 01:26
Transmission-Line Differential Equations
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...
 01:22
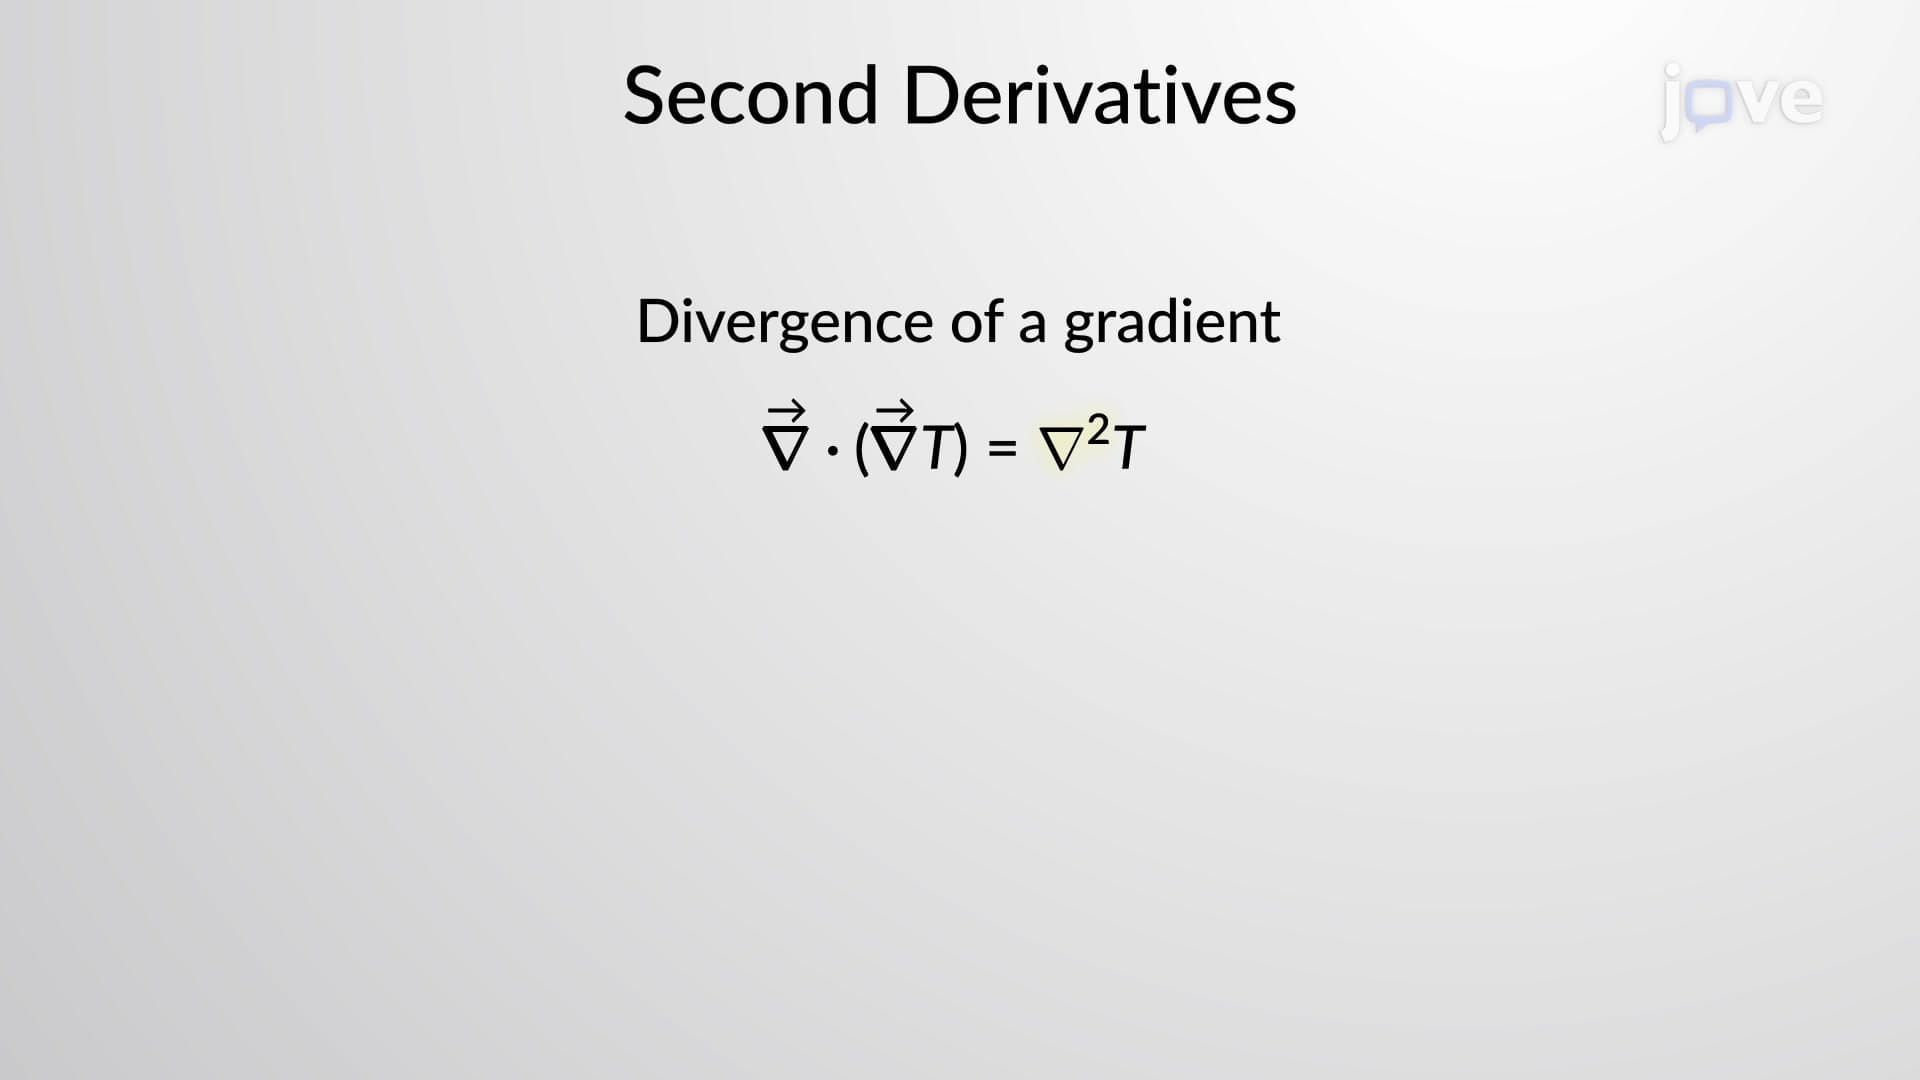
Second Derivatives and Laplace Operator
Consider a scalar function. The curl of its...
 01:17
Differential Form of Maxwell's Equations