Related Experiment Video
Updated: May 20, 2025

Author Spotlight: Advancing Tendon Research by Developing Mouse Assembloids to Understand Cellular Mechanisms
Published on: March 22, 2024
Cosserat Rod-Based Tendon Friction Modeling, Simulation, and Experiments for Tendon-Driven Continuum Robots
Honghong Wang1, Jingli Du1, Yi Mao2
1School of Mechano-Electronic Engineering, Xidian University, Xi'an 710071, China.

Abstract:
Traditional tendon-driven continuum robot (TDCR) models based on Cosserat rod theory often assume that tendon tension is a continuous wrench along the backbone. However, this assumption overlooks critical factors, including the discrete arrangement of disks, the segmented configuration of tensioned tendons, and the friction between tendons and guide holes. Additionally, tendon forces are not continuous but discrete, concentrated wrenches, with the frictional force magnitude and direction varying based on the TDCR's bending configuration. We propose a TDCR modeling method that integrates Cosserat rod theory with a finite element approach to address these limitations. We construct a Cosserat rod model for the robot's backbone, discretize the tendon geometry using the finite element method (FEM), and incorporate friction modeling between tendons and guide holes. Furthermore, we introduce an algorithm to determine the direction of friction forces, enhancing modeling accuracy. This approach results in a more realistic and comprehensive mathematical representation of TDCR behavior. Numerical simulations under various tendon-routing scenarios are conducted and compared with classical TDCR models. The results indicate that our friction-inclusive model improves accuracy, yielding an average configuration deviation of only 0.3% across different tendon routings. Experimental validation further confirms the model's accuracy and robustness.
Related Concept Videos
 01:05
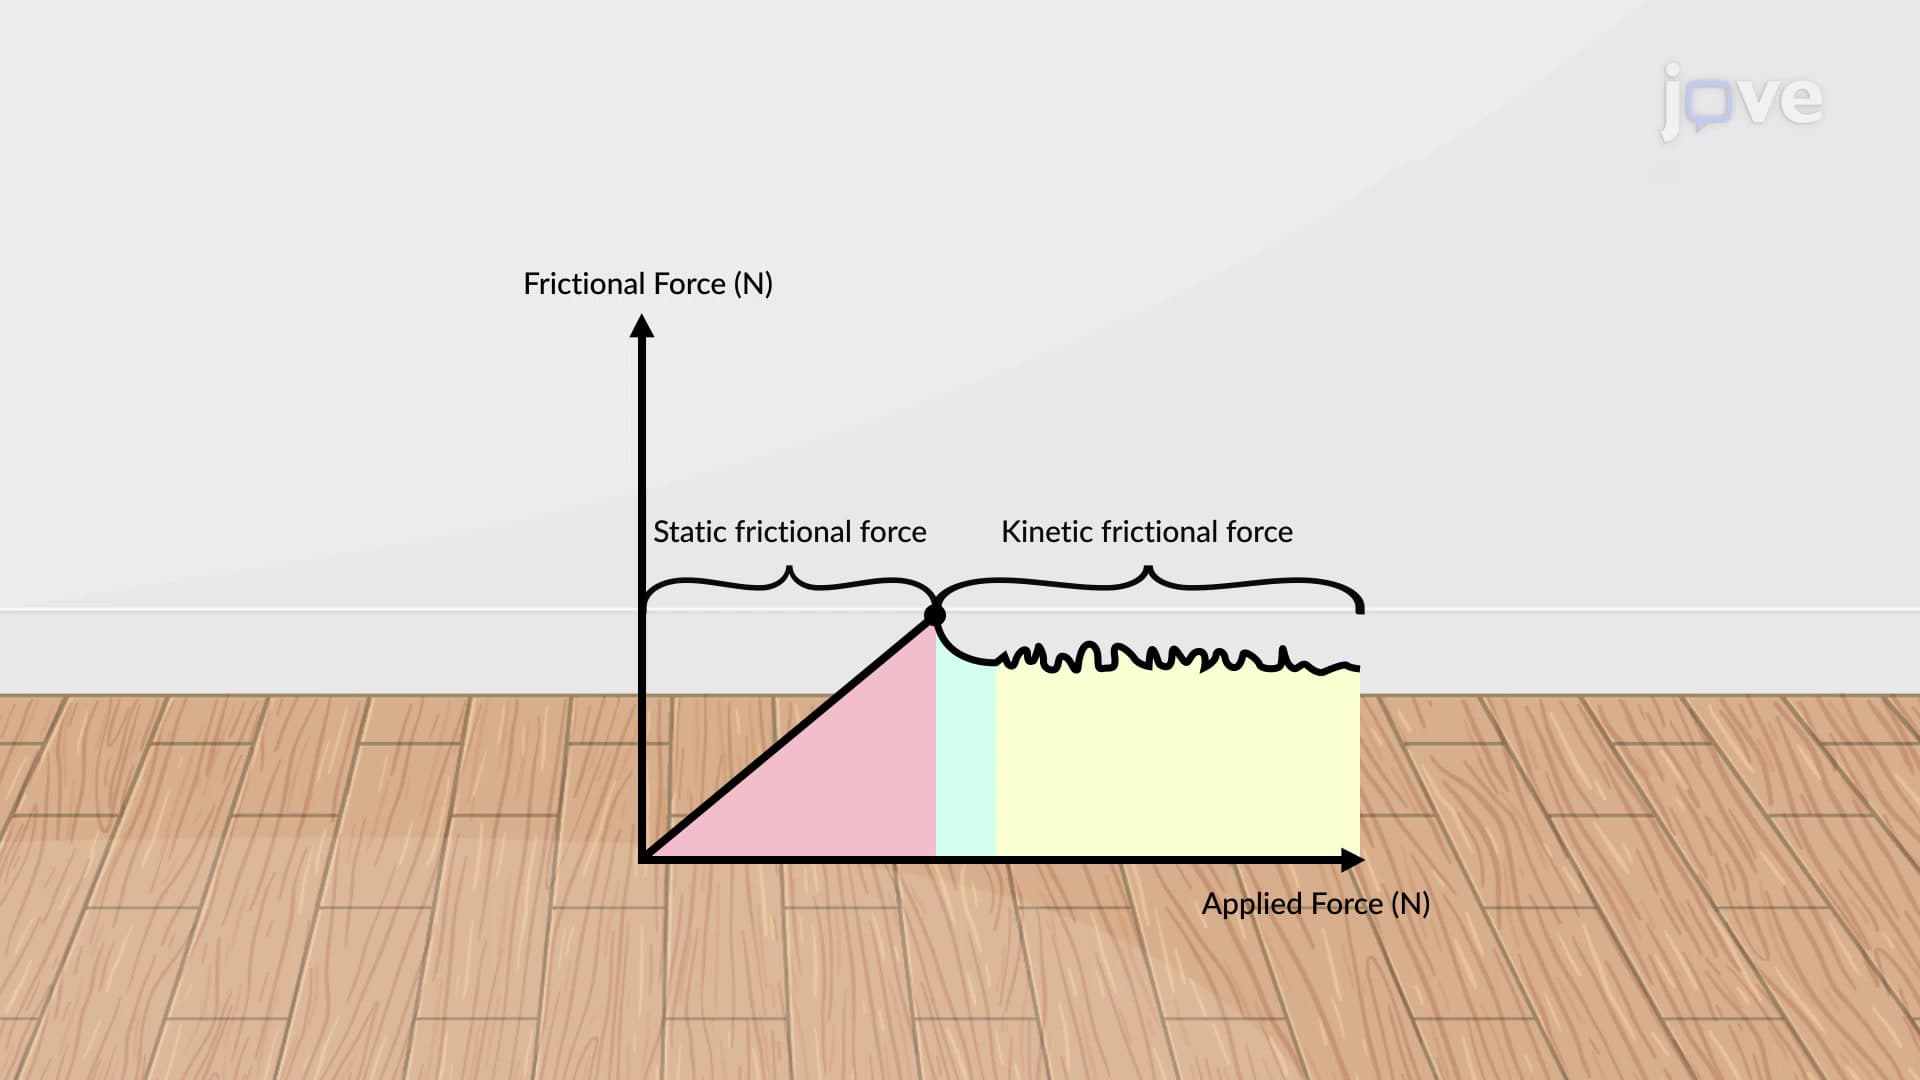
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:28
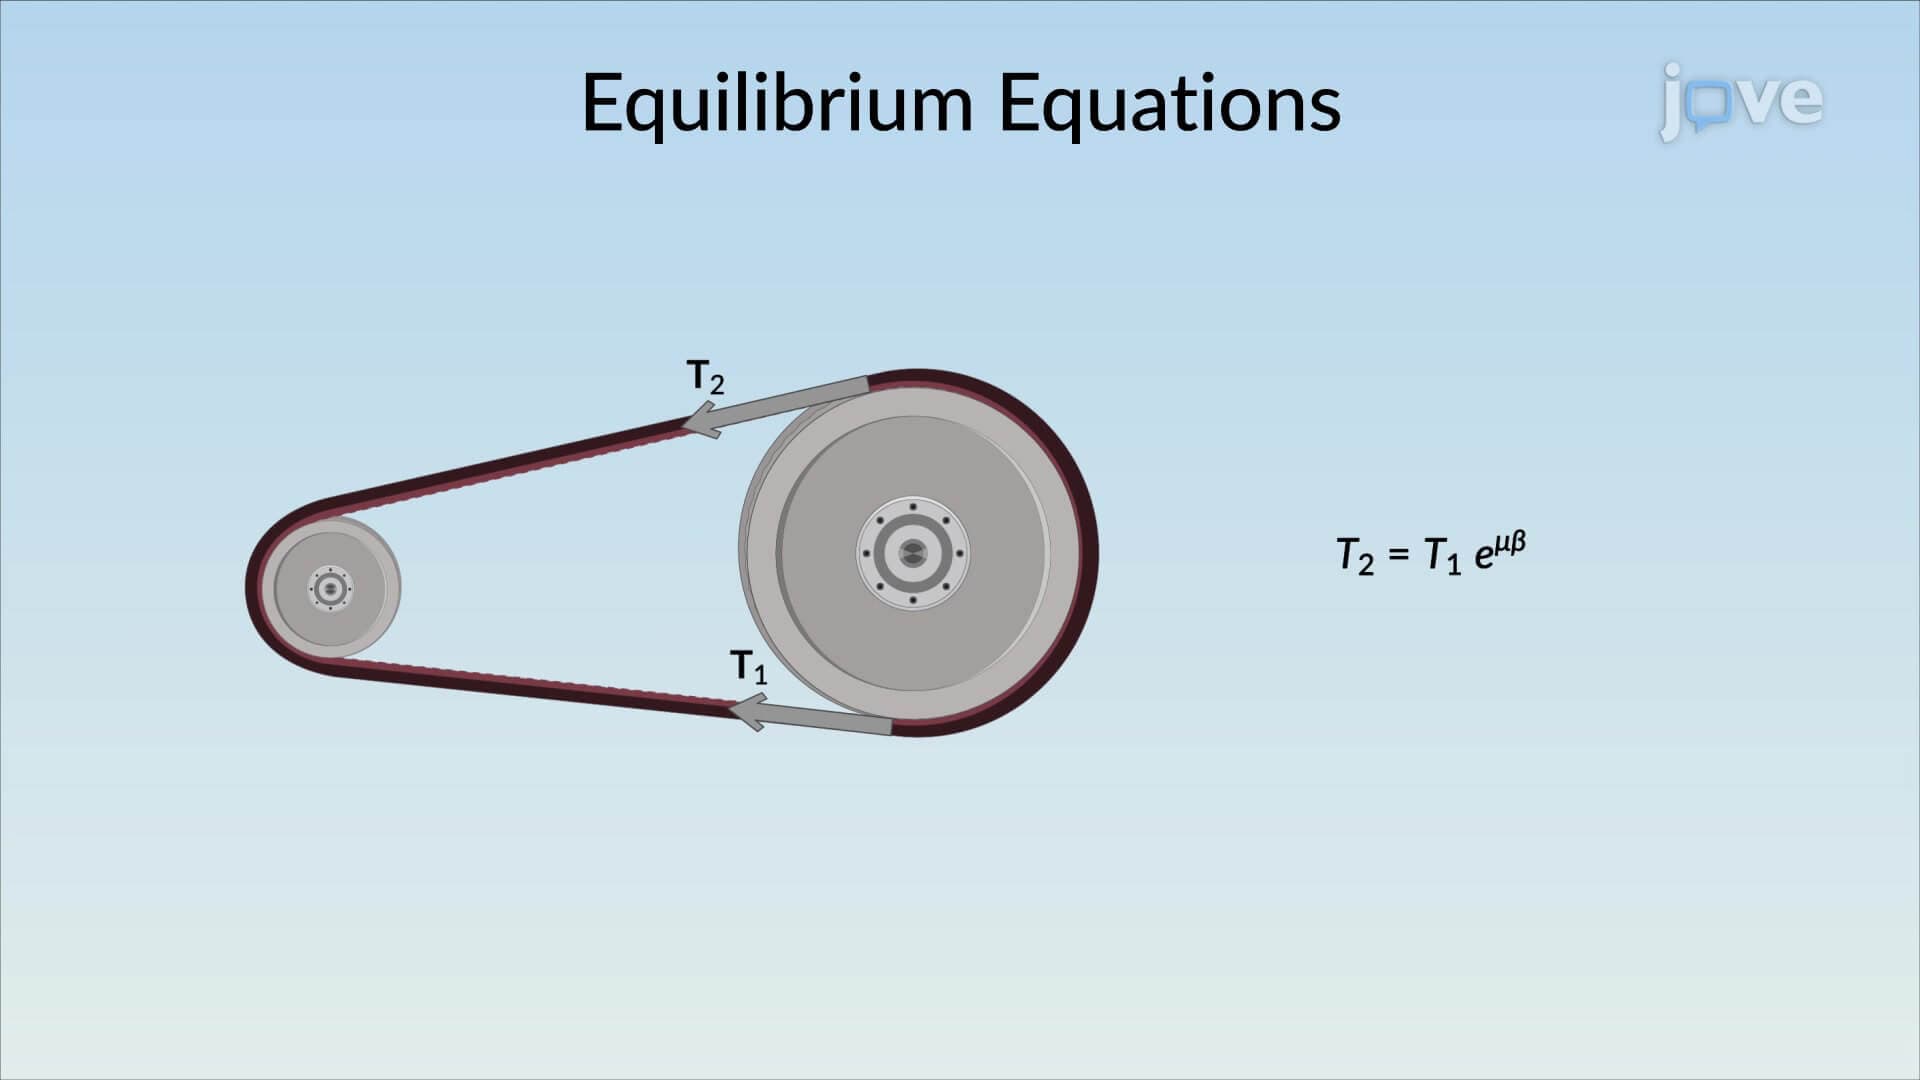
Frictional Forces on Flat Belts
 01:30
Three-Dimensional Force System
 01:17
Frictional Forces on Screws
A jack with a square-threaded screw is a mechanical device used to lift heavy loads by applying a force at its handle. When the force is applied, the screw turns, raising the load. The screw can...
 01:26
Kinetic Friction
 01:23
Simplification of a Force and Couple System: II