Related Experiment Video
Updated: May 16, 2025

Evaluating the Effect of Roadside Parking on a Dual-Direction Urban Street
Published on: January 20, 2023
Joint analysis of crash injury severities for autonomous and conventional vehicles in mixed traffic environments:
Jian Xiang1, Zhengwu Wang2, Yibo Chen2
1Key Laboratory of Highway Engineering of Ministry of Education, Changsha University of Science & Technology, Changsha 410114 Hunan, China; School of Transportation, Changsha University of Science & Technology, Changsha 410114 Hunan, China.

Abstract:
Autonomous vehicles (AVs) are expected to significantly enhance road safety in the future. However, until fully autonomous driving systems are widely adopted, mixed traffic with AVs and conventional vehicles (CVs) will remain a typical feature of roadways. Consequently, it is crucial to understand how roadway and built environment factors impact traffic safety in mixed traffic settings. This study proposes a joint model to analyze crash injury severity for both autonomous and conventional vehicles within a unified framework. A random parameter bivariate probit model (RBP) is used as the methodological approach, as it accounts for the correlation between injury outcomes for AVs and CVs, while also capturing unobserved heterogeneity among the factors influencing safety. The model is developed using a dataset of 699 paired crashes, involving both AVs and CVs, occurring in proximity to each other in mixed traffic conditions in California. For comparison, both a random parameters univariate probit model (RUP) and a bivariate probit model (BP) are also developed. Model comparison results demonstrate that the proposed RBP model outperforms both the RUP and BP model in terms of explanatory power and goodness-of-fit. The parameter estimates reveal divergent effects of crash type and cause, natural environmental conditions, roadway features, and built environment factors on injury severity for autonomous and conventional vehicle crashes. The key results include: (1) A primary cause of AV crashes is the failure of CV drivers to respond appropriately or in a timely manner to unexpected changes in AV behaviors. (2) Adverse natural conditions, such as dark, pose a greater safety risk for AVs compared to CVs. (3) Road features with complex traffic conditions-such as Y-shaped intersections, traffic signals, and areas where lanes merge or diverge-are associated with a higher likelihood of injury in AV crashes, whereas these factors do not significantly affect injury severity in CV crashes. (4) Built environment factors related to vulnerable road users and public transportation infrastructure, such as crosswalks, schools, bus stops, and metro stops, exhibit notably heterogeneous effects on injury severity in AV crashes. The findings of this study have important implications for developing targeted strategies to enhance safety in mixed traffic environments. These strategies include establishing effective communication systems between autonomous and conventional vehicles, improving obstacle detection and performance in low-visibility conditions, and ensuring well-equipped road infrastructure for vulnerable road users.
Related Concept Videos
 01:16
Hypothesis Test for Test of Independence
H0: The two variables (factors)...
 01:21
Introduction to Test of Independence
The test statistic for a test of independence is similar to that of a goodness-of-fit test:
 01:08
Determination of Expected Frequency
 01:17
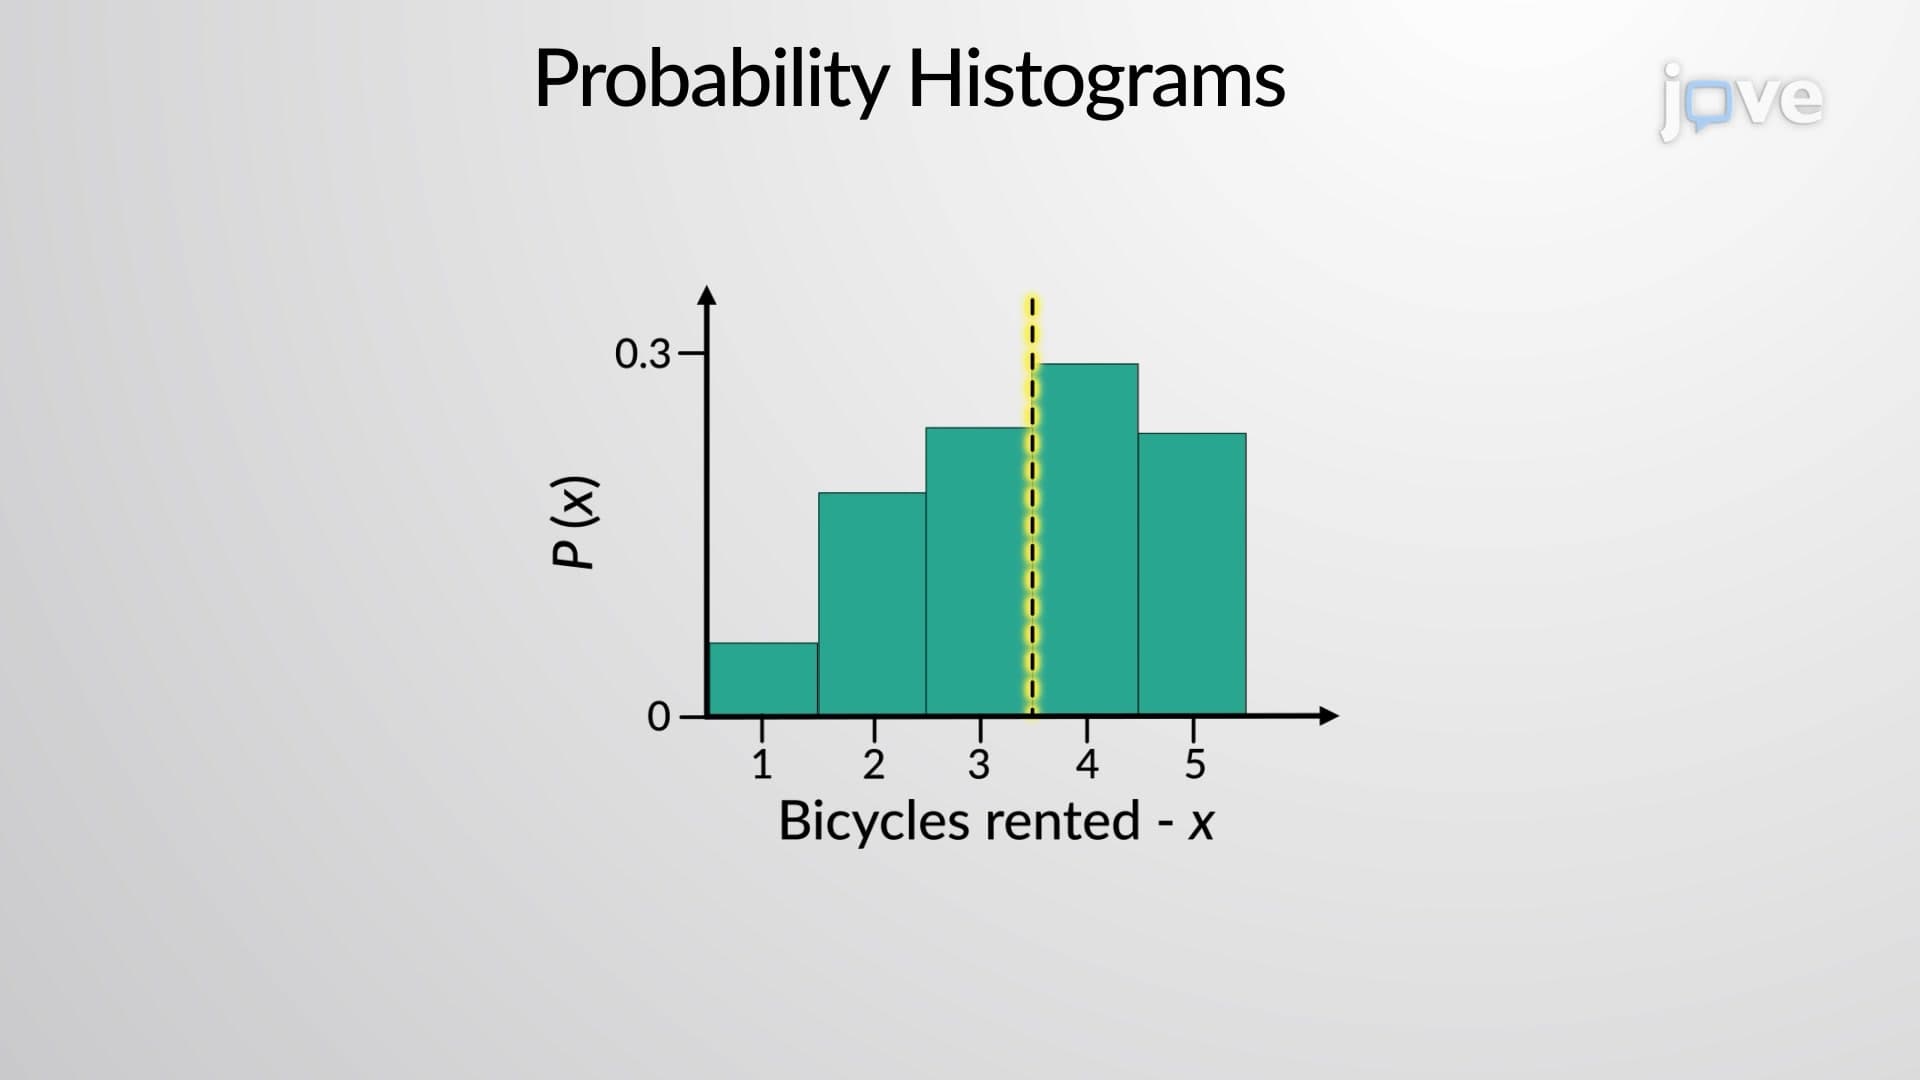
Probability Histograms
 01:14
Parametric Survival Analysis: Weibull and Exponential Methods
Weibull Distribution
The Weibull distribution is a flexible model used in parametric survival analysis. It can handle both increasing and decreasing hazard rates, depending on its shape parameter...
 01:23
Mechanistic Models: Compartment Models in Individual and Population Analysis