Related Experiment Video
Updated: May 14, 2025
Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
Influence of the rotation angles on the mechanical behavior of the one reci instrument
Renaud Giess1,2, Éric Mortier1,3, Marie Delanoë4
1Départment de dentisterie restauratrice et endodontie, Faculté d'odontologie de Lorraine, Université de Lorraine, F-54000, Nancy, France.

Aims:
The reciprocity is a complex endodontic kinematic involving many parameters. The most important of these is undoubtedly the selection of clockwise and counterclockwise rotation angles. In this context, the aim of this study was to determine the influence of clockwise and counterclockwise rotation angles on the mechanical properties of 25/0.06 One Reci reciprocity instruments.
Method:
For this purpose, 5 groups of 10 25/0.06 One Reci instruments were used and each group was associated with a pair of counterclockwise/clockwise rotation angles (CCW/CW). In order to study only one variable at a time, one of the two angles was fixed and the second was increased or decreased. The distribution of angles was as follows: Group 1: 170°/60°; Group 2: 150°/60°; Group 3: 170°/30°; Group 4: 170°/90°; Group 5: 210°/60°. Thanks to a load/unload endodontic protocol carried out on a tensile bench, we quantified for each tested pair of angles (i) the cutting efficiency, (ii) the screwing effect and (iii) the generated torque.
Results:
Increasing or decreasing one of the two rotation angles influences the mechanical behavior of the instruments, as does the resulting range. Therefore, our results showed a direct influence of rotation angles on the mechanical behavior of endodontic instruments.
Conclusion:
This study analyzes the influence of clockwise and counterclockwise rotation angles on the mechanical properties of 25/0.06 One Reci reciprocity instruments. The results of this work tend to demonstrate a direct influence of rotation angles on the mechanical behavior of 25/0.06 One Reci instruments.
More Related Videos
Related Concept Videos
 01:13
Angle of Twist: Problem Solving
 01:13
Angle of Twist - Elastic Range
 01:10
Deformation in a Circular Shaft
 01:11
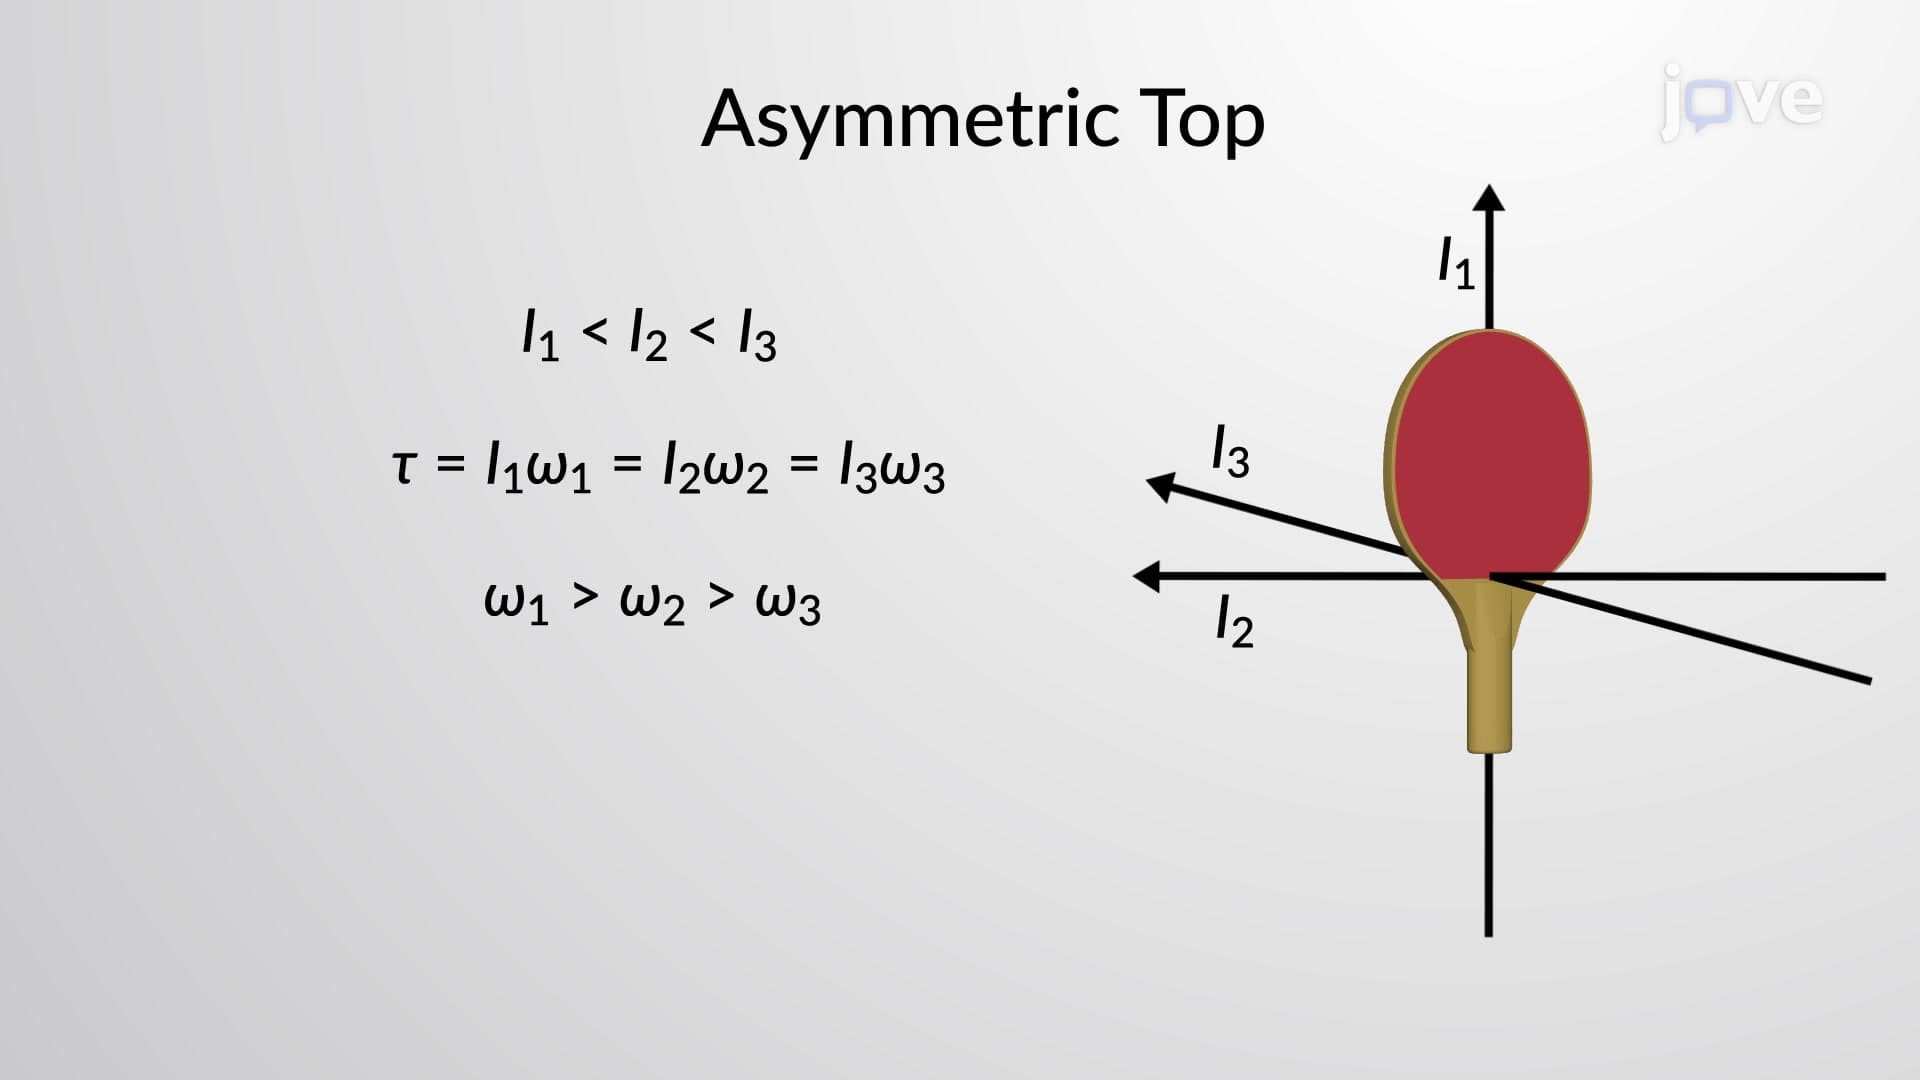
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:26
Rotational Motion about a Fixed Axis
 01:18
Transformation of Plane Stress