Related Experiment Video
Updated: May 13, 2025


Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
A friction compensation approach of a 6 axis hybrid robot by considering joint inertia change
Qi Liu1,2, Sitong Shen1,2, Yue Ma1,2
1Tianjin Key Laboratory for Advanced Mechatronic System Design and Intelligent Control, School of Mechanical Engineering, Tianjin University of Technology, Tianjin 300384, China.

Abstract:
The feedforward compensation based on friction model is an effective way to reduce the influence of friction on mechanical system. This paper presents an approach for friction compensation by considering the inertia change of the actuated joints of a 6-axis hybrid robot named TriMule. First, the tracking errors of each actuated joint of the parallel mechanism at high and low inertia configurations are displayed. Then, a compensation approach considering inertia change is developed by introducing the inertia term of the joint driving force into the traditional Stribeck model as thrust. Furthermore, the improved approach based on radial basis function interpolation without using the dynamic model is proposed, which has a simple calculation expression and acceptable compensation effect. Experiment results on a prototype machine show that compared to otherwise similar compensation method not considering joint inertia change, the tracking accuracy can be improved up to 25.73% at high inertia configurations.


Related Concept Videos
 01:05
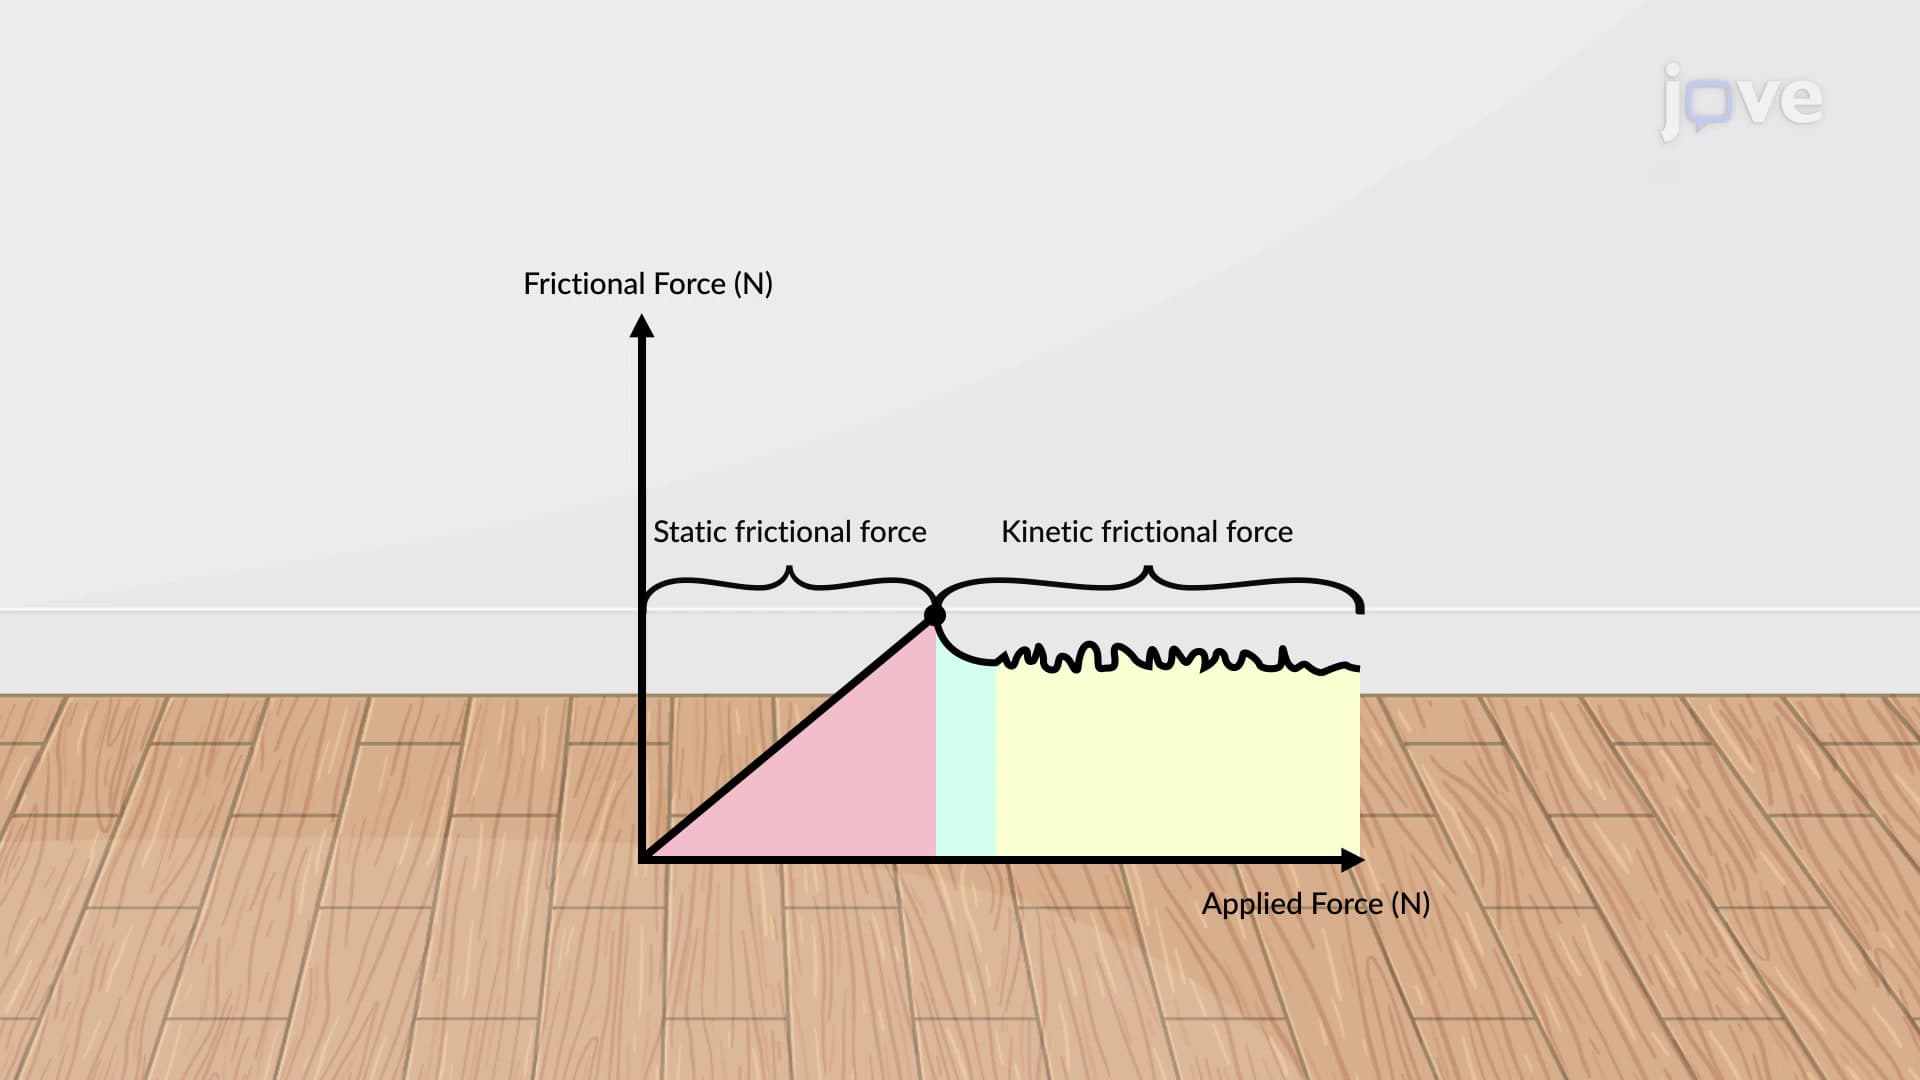
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:26
Kinetic Friction
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:10
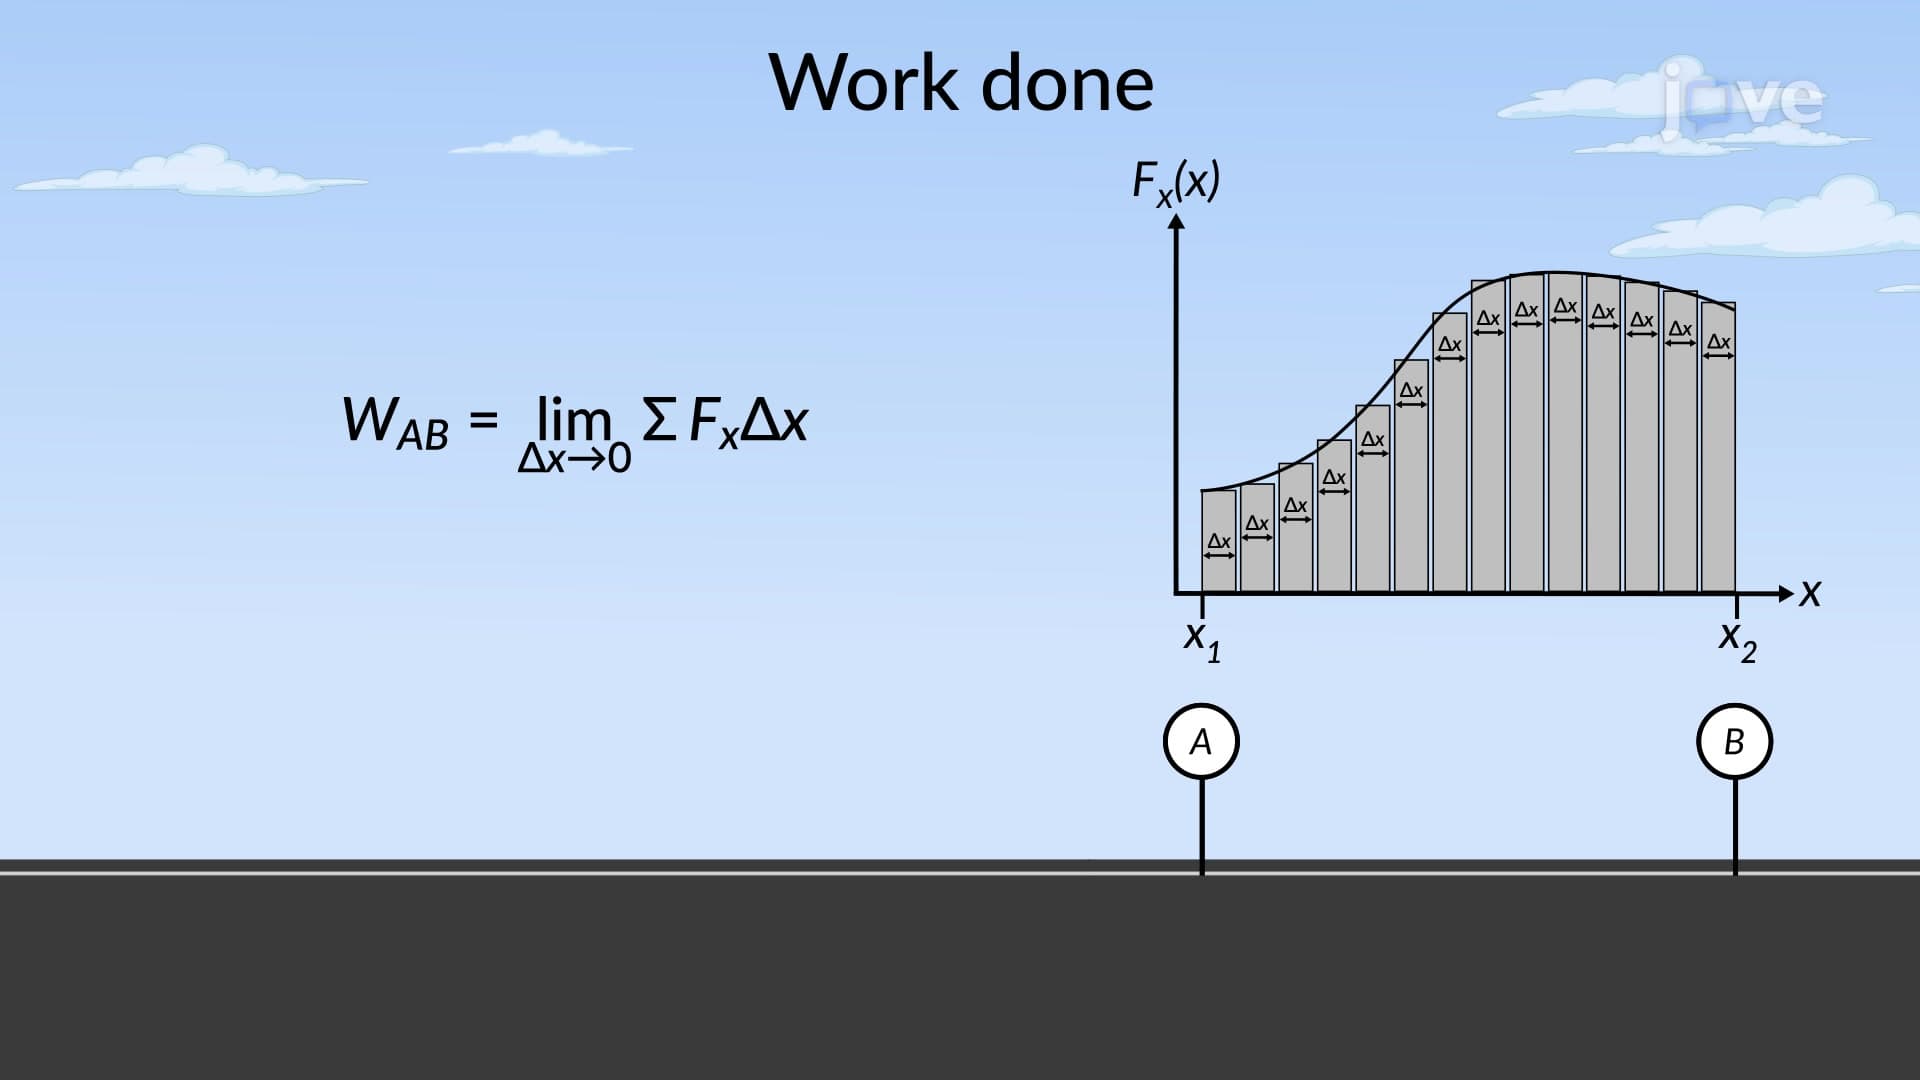
Work and Energy for Variable Forces
 01:15
Kinematic Equations: Problem Solving