Elastic Fiber Programming for Simplified Pneumatic Control in Soft Robots
Related Experiment Video
Updated: May 7, 2026
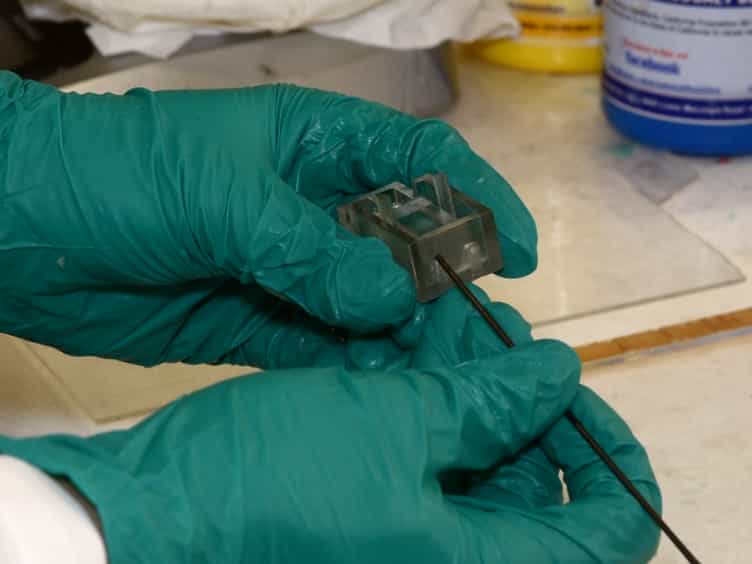
Rod-based Fabrication of Customizable Soft Robotic Pneumatic Gripper Devices for Delicate Tissue Manipulation
Published on: August 2, 2016
Xiaoli Yang1, Tao Jin1, Shiwei Tian2
1Shanghai Key Laboratory of Intelligent Manufacturing and Robotics, School of Mechatronic Engineering and Automation, Shanghai University, Shanghai, 200444, China.

Abstract:
Conventional pneumatic soft robots require complex control systems with multiple valves and circuits due to coupled structural and pneumatic dynamics. A strategy is presented to program the pneumatic response characteristics of soft actuators by embedding elastic fibers with tailored materials and pre-stretch ratios, enabling structurally identical modules to exhibit distinct pressure-driven responses. A 6 mm-diameter actuator prototype demonstrates this paradigm, achieving a 2632% load ratio and 225°/s bending speed at a material cost of 9 cents. Crucially, a single pneumatic input suffices for multi-step actuation-shown in pipeline-climbing robots, omnidirectional crawlers, and grippers adapting to objects from 10 to 450 g. This fusion of material programming and mechanical intelligence simplifies control architectures while enhancing functionality, offering a scalable path toward deployable soft robotics.
Related Concept Videos
 01:22
Mechanical Systems
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...