Related Experiment Video
Updated: May 10, 2025
An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Analytical Formulation of Relationship Between Sensors and Euler Angle Errors for Arbitrary Stationary Alignment
Chang June Lee1, Jung Keun Lee2
1Department of Integrated Systems Engineering, Hankyong National University, Anseong 17579, Republic of Korea.

Abstract:
An attitude and heading reference system (AHRS) based on the inertial measurement unit is crucial for various applications. In an AHRS, stationary alignments are performed to determine the initial orientation of the sensor frame with respect to the navigation frame. However, the stationary alignment accuracy is affected by sensor error factors. Therefore, several studies have attempted to analyze and minimize the effects of these errors. However, there have been no studies describing and analyzing the Euler angle errors for various sensor orientations. This paper presents the analytical formulation of the relationship between the sensor and the Euler angle errors based on accelerometer and magnetometer signals, regardless of alignment between the sensor and the navigation frames. We selected three-axis attitude determination (TRIAD) as the stationary alignment method and considered the scale, installation, and the offset errors, including noise and constant bias, as sensor error factors. The presented formulation describes the relationship between the sensor error factors and the Euler angle errors as a linear equation. To analyze the Euler angle errors, we performed both sensor-aligned and sensor-misaligned simulations in which the Euler angles were 0° and arbitrary, respectively. The results showed that the presented error formulation could describe the total Euler angle errors and the partial errors induced by each sensor error factor for both the sensor-aligned conditions and the arbitrary Euler angle configurations. Thus, the effects of each sensor error factor on the Euler angle errors can be analytically investigated using the presented formulations for random alignment.
More Related Videos

Related Concept Videos
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:10
Relative Motion Analysis - Acceleration
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:37
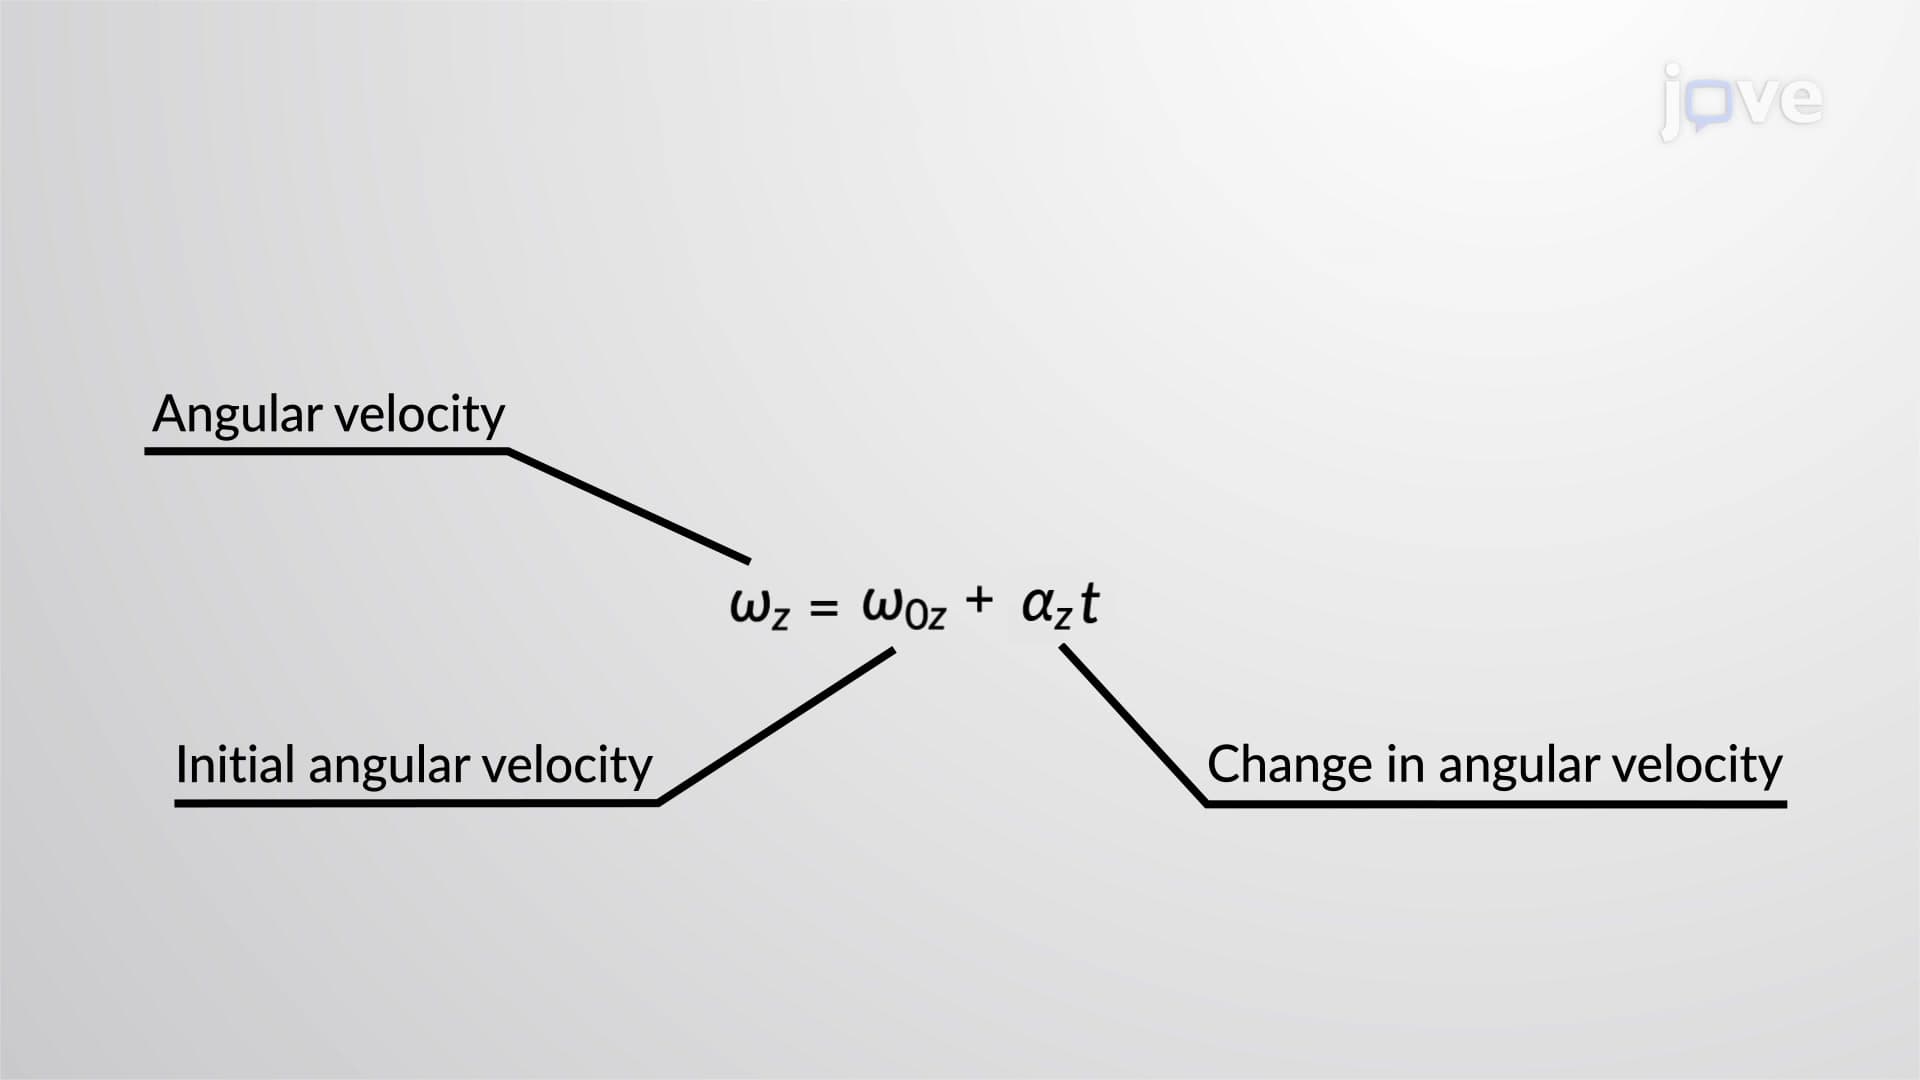
Rotation with Constant Angular Acceleration - I
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...