Related Experiment Video
Updated: May 9, 2025

Studying Large Amplitude Oscillatory Shear Response of Soft Materials
Published on: April 25, 2019
Duality of Shehu transform with other well known transforms and application to fractional order differential
Nabil Mlaiki1, Noor Jamal2, Muhammad Sarwar1,2
1Department of Mathematics and General Sciences, Prince Sultan University, Riyadh, Saudi Arabia.

Abstract:
Integral transforms are used in many research articles in the literature, due to their interesting applications in the solutions of problems of applied science and engineering. In many situations, researchers feel difficulties in applying a given transform to solve differential or integral equations, therefore it is more convenient to derive dualities relations between these transforms. Shehu transform has the properties to converge to the well-known integral transforms used in the literature only by changing the space parameters. In this article, we will derive the inter-conversion relations between the Shehu transform, Natural, Sumudu, Laplace, Laplace-Carson, Fourier, Aboodh, Elzaki, Kamal and Mellin transforms. These duality relations will make simple the integral transforms because if a transform such as Fourier or Mellin transform is difficult to solve a differential equation due to its complexity then duality relations will do this job easily. These multiplicity relations have many interesting properties that make visualizations easier. The duality relations have important applications in solving the fractional order differential equations by various integral transforms. Moreover, duality relations save the time of researchers, because in the literature the researchers solved a problem with different transforms. Keeping in mind these advantages of the duality relations, we decide to discuss the duality relations of Shehu transform with other integral transforms.
Related Concept Videos
 01:24
Difference Equation Solution using z-Transform
The z-transform facilitates handling delayed signals by shifting the signal in the z-domain, which corresponds to delaying the signal in the time domain, and advancing signals by similarly shifting in the...
 01:18
Second Order systems II
 01:23
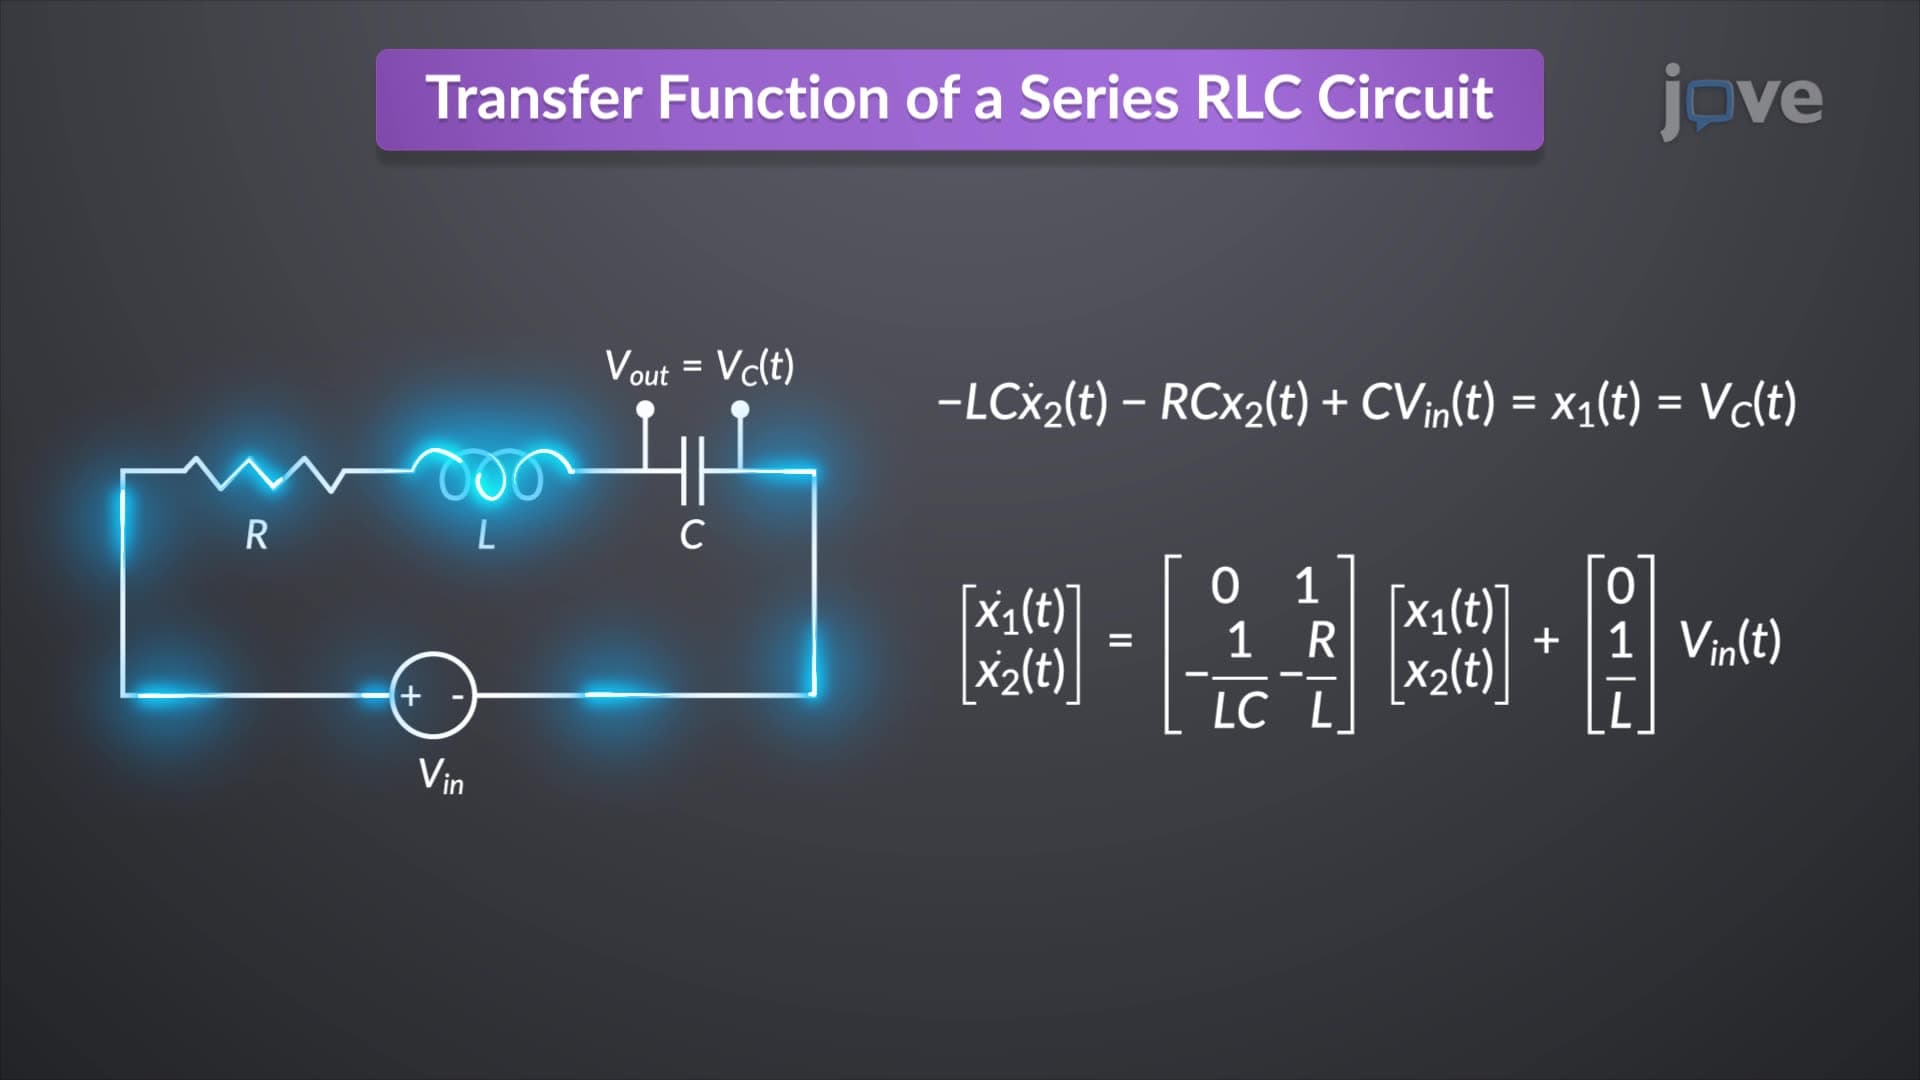
Transfer Function to State Space
In an...
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:26
Transmission-Line Differential Equations
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...
 01:22
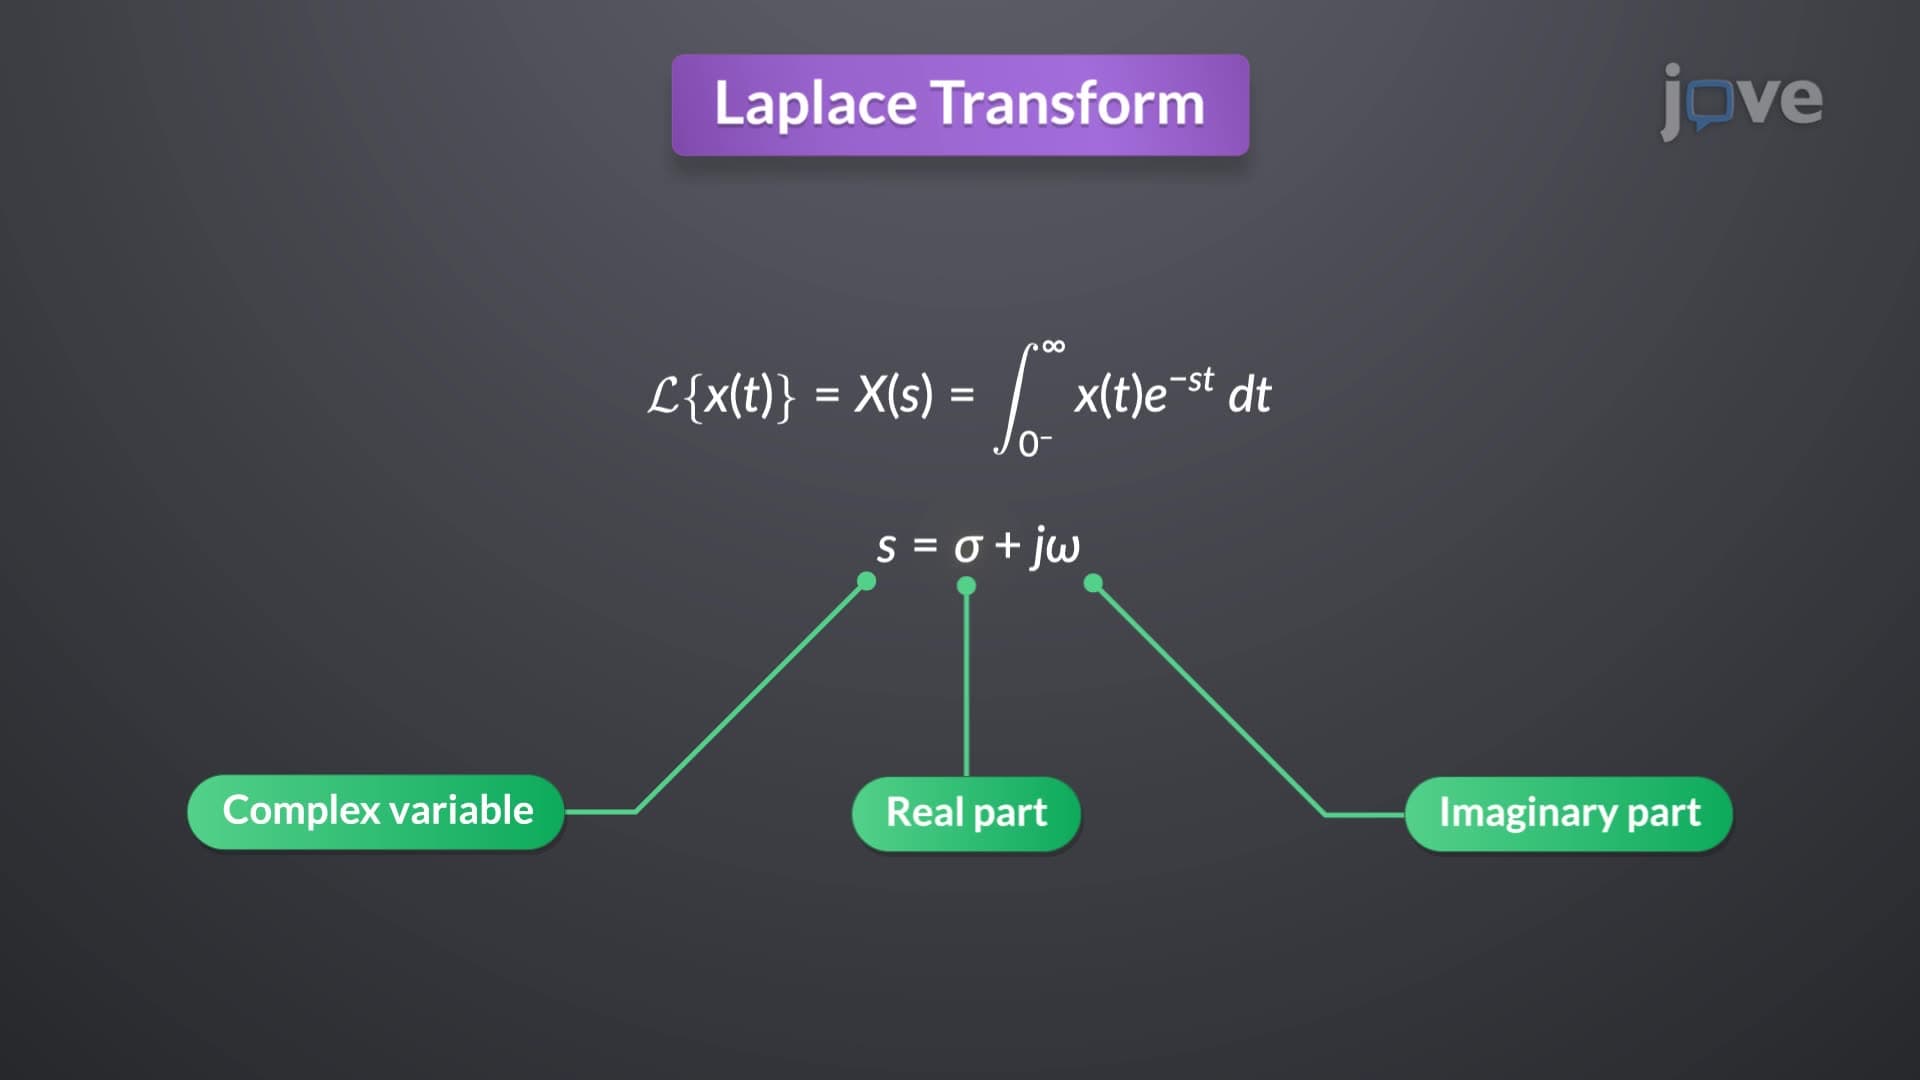
Definition of Laplace Transform