Related Experiment Video
Updated: May 12, 2025


Design and Analysis for Fall Detection System Simplification
Published on: April 6, 2020
Opposing-through crash risk forecasting using artificial intelligence-based video analytics for real-time
Md Mohasin Howlader1, Md Mazharul Haque1
1Queensland University of Technology (QUT), School of Civil and Environmental Engineering, Faculty of Engineering, Brisbane, QLD 4000, Australia.

Abstract:
Recent advancements in artificial intelligence (AI) and traffic sensing technologies provide significant opportunities for real-time crash risk forecasting. While forecasting based on historical crash data yields macroscopic insights into future crash risks, such information is often insufficient for real-time applications. In contrast, traffic conflict techniques (TCTs) leveraged by extreme value theory (EVT) and AI-based video analytics have enabled crash risk estimation to a granular level, presenting a promising potential for real-time applications. This study develops a unified framework of integrating generalized extreme value (GEV) theory with parametric and non-parametric forecasting models to predict opposing-through crash risks at signalized intersections. A deep neural network-based computer vision technique was employed to extract post encroachment time (PET) traffic conflicts from 97 h of video footage. Crash risks were estimated using a non-stationary GEV model, incorporating traffic conflict counts, speed variations, and signal timing characteristics. These risk estimates were then forecasted using autoregressive integrated moving average (ARIMA), gated recurrent unit (GRU), and long short-term memory (LSTM) models to analyze short-term crash trends. Results show that the mean crash frequency estimates fell within the 95 % confidence limits of observed crashes and confirm the adequacy of the developed EVT model in estimating opposing-through crashes. The autoregressive and recurrent neural network models exhibit similar forecasting accuracy for crash risk forecasting, with reliable predictions extending up to 11 future signal cycles. The proposed real-time crash risk forecasting framework can be a crucial component of an intelligent transport system, leading to proactive safety management for signalized intersections.


Related Concept Videos
 01:18
Steps in Outbreak Investigation
 01:03
Prediction Intervals
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.
 01:11
Hazard Rate
 01:07
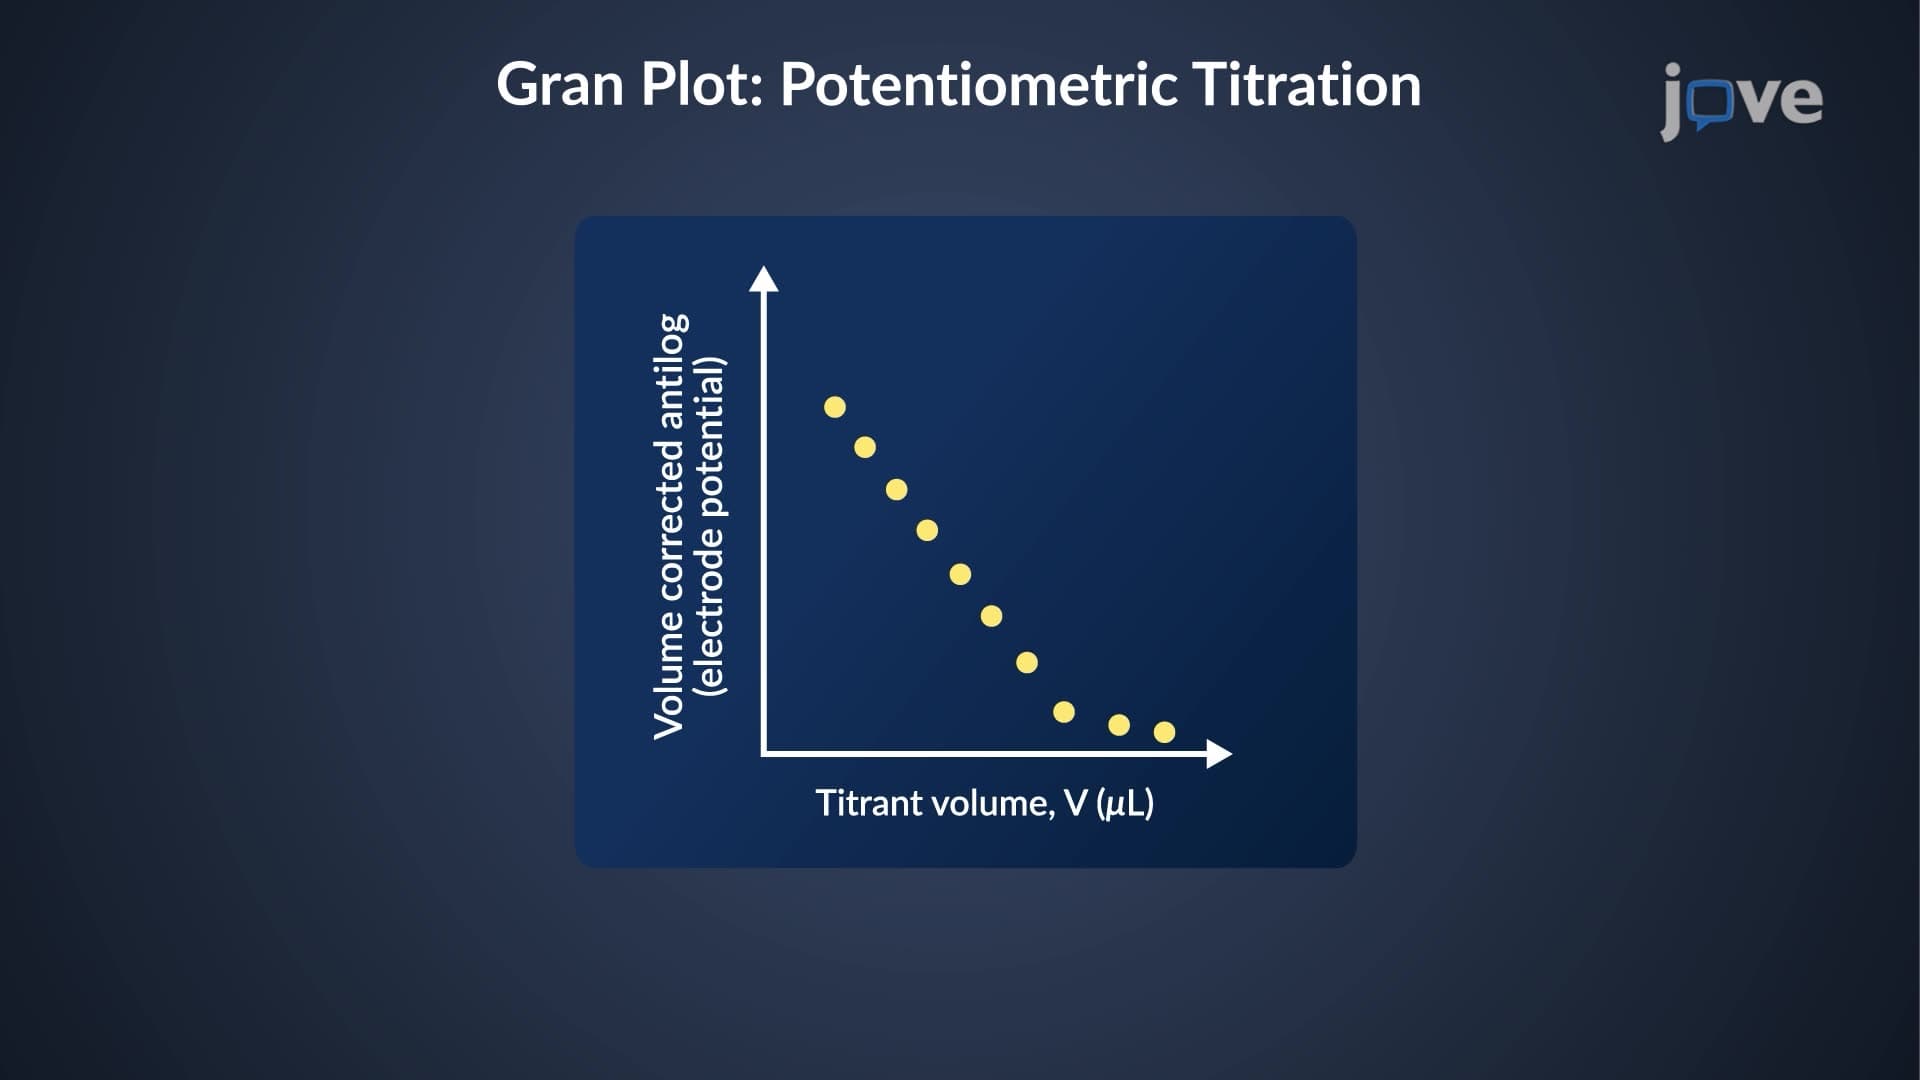
End Point Prediction: Gran Plot
For potentiometric titration, the Gran plot is created by plotting...
 01:15
Expected Value
 01:29
Econometric Views (EViews)