Related Experiment Video
Updated: May 17, 2025
Automated Two-dimensional Spatiotemporal Analysis of Mobile Single-molecule FRET Probes
Published on: November 23, 2021
Novel Gain-Optimized Two-Step Fusion Filtering Method for Ranging-Based Localization Using Predicted Residuals
Bo Chang1, Xinrong Zhang2, Na Sun2,3
1Faculty of Electronic Information Engineering, HuaiYin Institute of Technology, Huaian 223003, China.

Abstract:
A two-stage fusion filtering positioning algorithm based on prediction residuals and gain adaptation is proposed to address the problems of disturbance and modeling errors in the application of distance-based positioning algorithms in wireless sensor networks, as well as inaccurate initial filtering values leading to large estimation errors or even divergence. Firstly, based on parameterization methods, a pseudo linear equation is constructed from the time of arrival (TOA) and multipath delay. The weighted least squares (WLS) method is applied to obtain the initial value of target position resolution, and its performance approaches the Cramér-Rao lower bound (CRLB). Secondly, the exact position of the target is obtained using the reconstructed Gaussian white noise statistics and the Kalman filtering algorithm. The simulation results show that compared with other initial positioning algorithms, the average positioning accuracy of the proposed algorithm is improved by 28.57%, and it has a better filtering performance.
Related Concept Videos
 01:11
Residuals and Least-Squares Property
If the observed data point lies above the line, the residual is positive, and the line underestimates the actual data value for y. If the observed data point lies below the line, the residual is negative, and the line overestimates the actual data value for y.
The process of fitting the best-fit...
 01:26
Errors in Global Positioning System
 01:15
Distance Corrections
 01:10
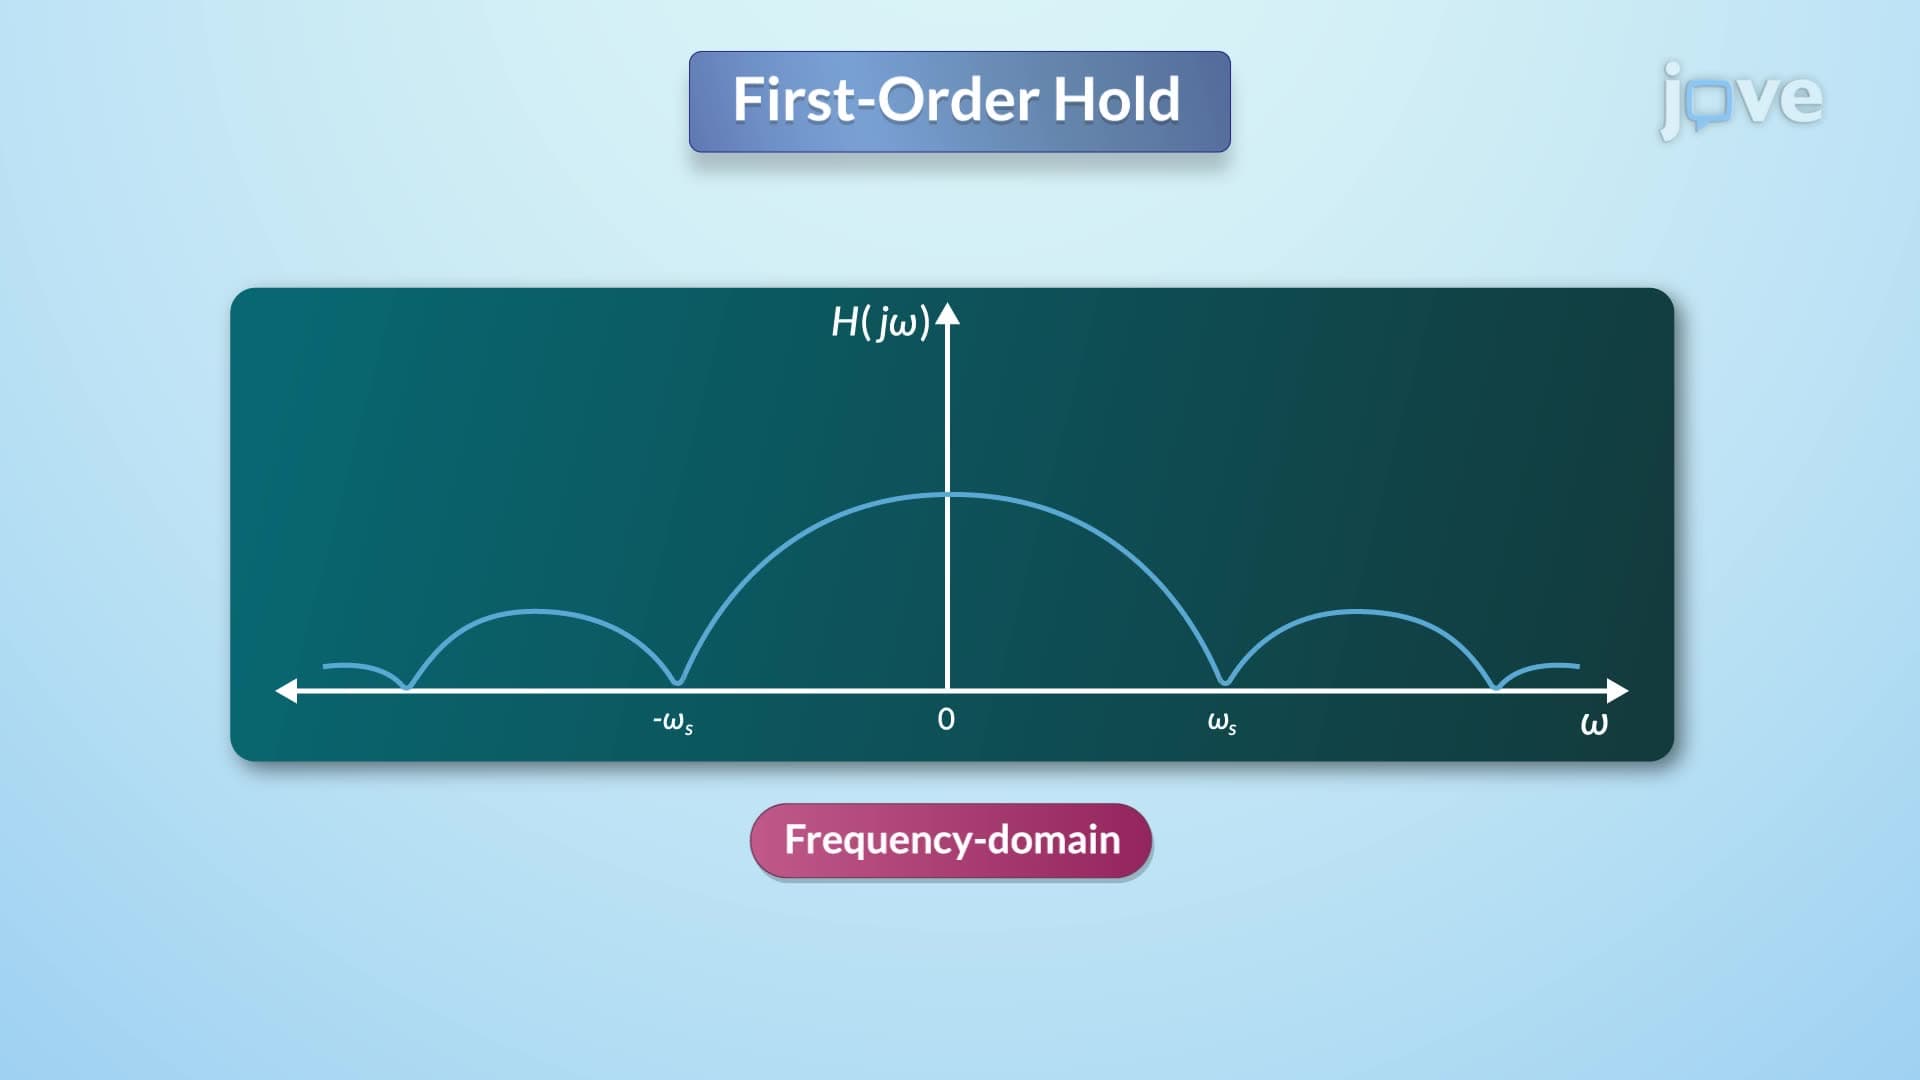
Reconstruction of Signal using Interpolation
 01:12
Differential Leveling
 01:18
Distance Measurements by Taping