Related Experiment Video
Updated: May 17, 2025
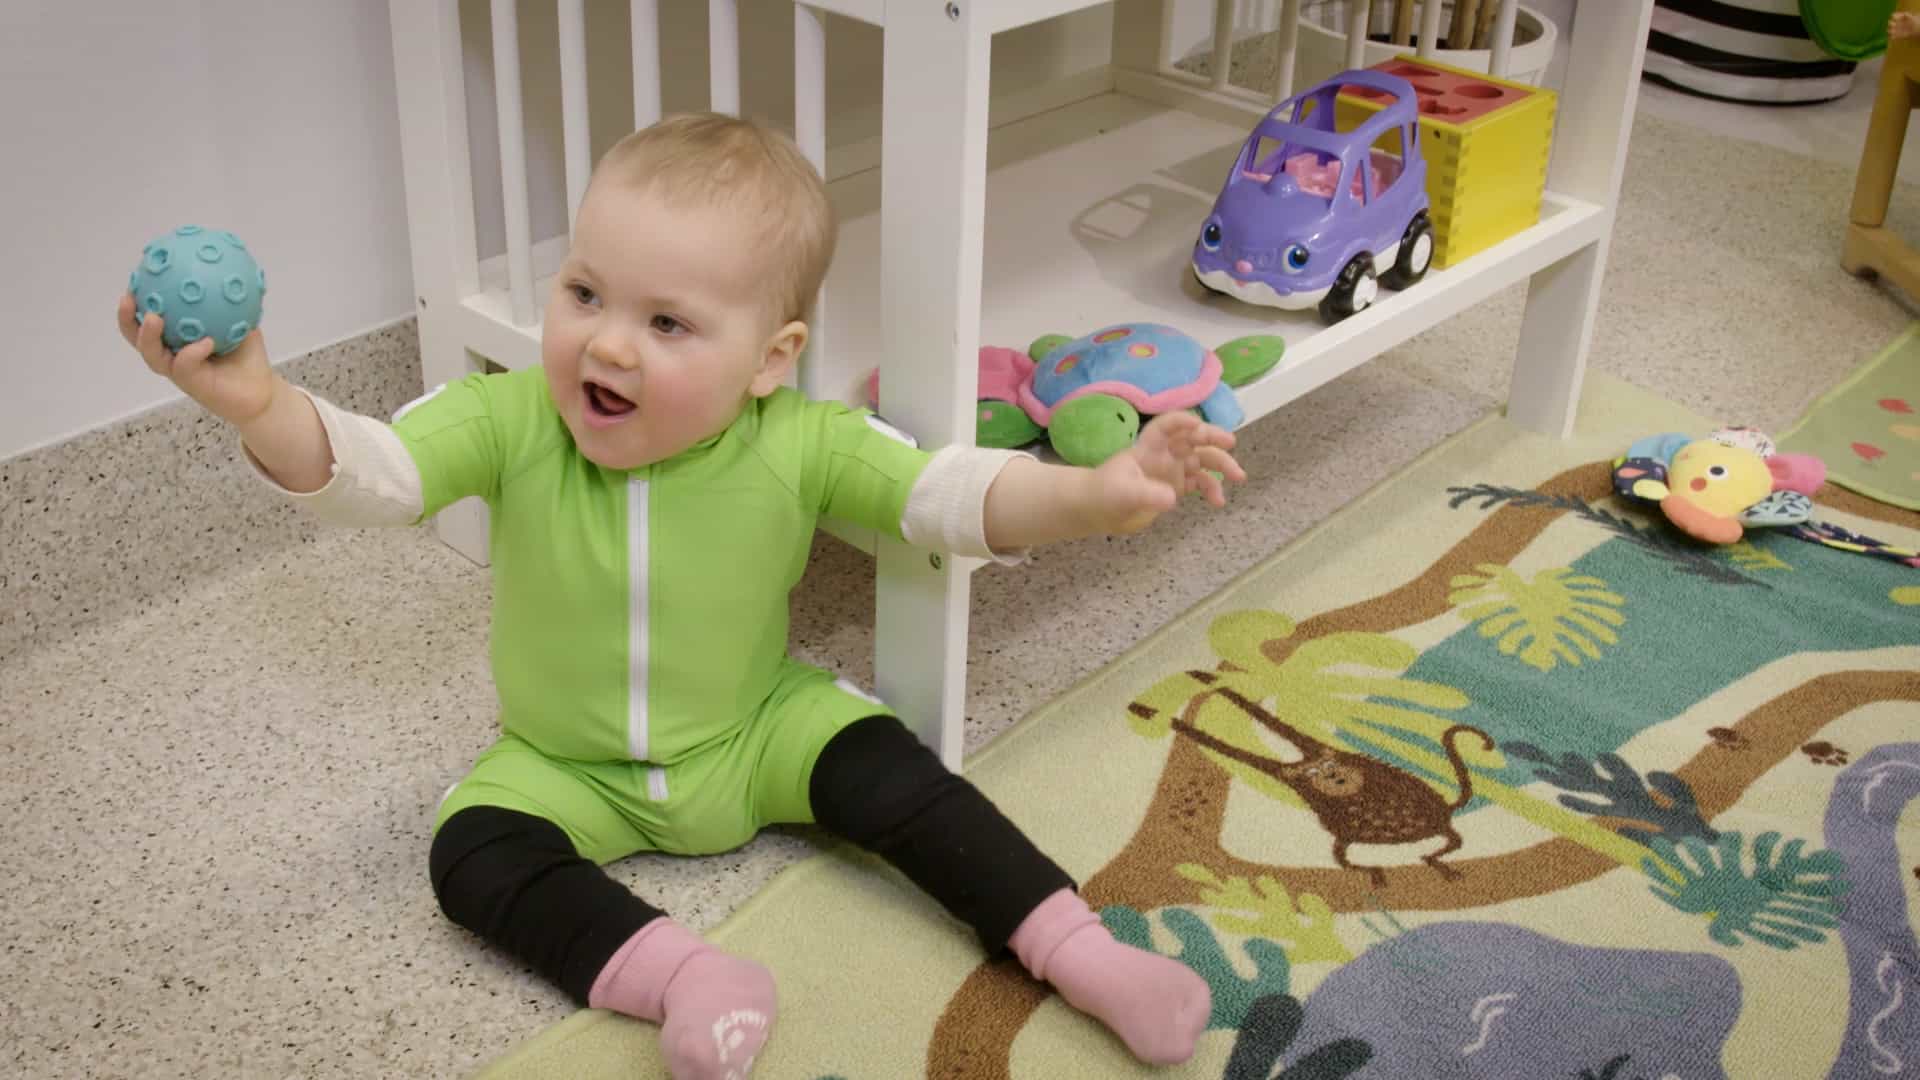

Quantified Assessment of Infant's Gross Motor Abilities Using a Multisensor Wearable
Published on: May 17, 2024
Comparative Analysis of Machine Learning Approaches for Fetal Movement Detection with Linear Acceleration and Angular
Lucy Spicher1, Carrie Bell2, Kathleen H Sienko1
1Department of Mechanical Engineering, University of Michigan, Ann Arbor, MI 48109, USA.

Reduced fetal movement (RFM) can indicate that a fetus is at risk, but current monitoring methods provide only a "snapshot in time" of fetal health and require trained clinicians in clinical settings. To improve antenatal care, there is a need for continuous, objective fetal movement monitoring systems. Wearable sensors, like inertial measurement units (IMUs), offer a promising data-driven solution, but distinguishing fetal movements from maternal movements remains challenging. The potential benefits of using linear acceleration and angular rate data for fetal movement detection have not been fully explored. In this study, machine learning models were developed using linear acceleration and angular rate data from twenty-three participants who wore four abdominal IMUs and one chest reference while indicating perceived fetal movements with a handheld button. Random forest (RF), bi-directional long short-term memory (BiLSTM), and convolutional neural network (CNN) models were trained using hand-engineered features, time series data, and time-frequency spectrograms, respectively. The results showed that combining accelerometer and gyroscope data improved detection performance across all models compared to either one alone. CNN consistently outperformed other models but required larger datasets. RF and BiLSTM, while more sensitive to signal noise, offered reasonable performance with smaller datasets and greater interpretability.
Reduced fetal movement (RFM) can indicate that a fetus is at risk, but current monitoring methods provide only a "snapshot in time" of fetal health and require trained clinicians in clinical settings. To improve antenatal care, there is a need for continuous, objective fetal movement monitoring systems. Wearable sensors, like inertial measurement units (IMUs), offer a promising data-driven solution, but distinguishing fetal movements from maternal movements remains challenging. The potential benefits of using linear acceleration and angular rate data for fetal movement detection have not been fully explored. In this study, machine learning models were developed using linear acceleration and angular rate data from twenty-three participants who wore four abdominal IMUs and one chest reference while indicating perceived fetal movements with a handheld button. Random forest (RF), bi-directional long short-term memory (BiLSTM), and convolutional neural network (CNN) models were trained using hand-engineered features, time series data, and time-frequency spectrograms, respectively. The results showed that combining accelerometer and gyroscope data improved detection performance across all models compared to either one alone. CNN consistently outperformed other models but required larger datasets. RF and BiLSTM, while more sensitive to signal noise, offered reasonable performance with smaller datasets and greater interpretability.
Related Concept Videos
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:10
Relative Motion Analysis - Acceleration
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...