Related Experiment Video
Updated: May 23, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Distributed extended state observer design for strict-feedback nonlinear leader system
Jixing Lv1, Changhong Wang1, Yonggui Kao2
1School of Astronautics, Harbin Institute of Technology, Harbin 150001, China.

Abstract:
Knowing the leader's state and dynamics is crucial for leader-following control. This article addresses the distributed state/uncertainty estimation problem for a strict-feedback nonlinear leader system under directed communication topologies. The leader is characterized by Hölder-growing nonlinearities and matched uncertainty. A prescribed-time distributed estimation scheme composed of two distributed extended state observers (DESOs) is proposed. Each follower (observer node) receives only one-dimensional output estimates from its neighbors and at most one-dimensional output from the leader system, effectively reducing the communication load. First, a prescribed-time DESO (PTDESO) is proposed so that each follower can reconstruct the leader's state and uncertainty at a time tightly prescribed by a single parameter, uniform to the initial conditions. Then, a high-gain DESO (HGDESO) is constructed, which achieves asymptotic convergence and maintains the observation errors in a small neighborhood of the origin after the prescribed time. Sufficient conditions for guaranteeing the convergence of the two DESOs are established. Ultimately, practical examples involving multiple manipulators and marine surface vehicles are provided to demonstrate the effectiveness of the proposed observers.
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:18
Second Order systems II
 01:23
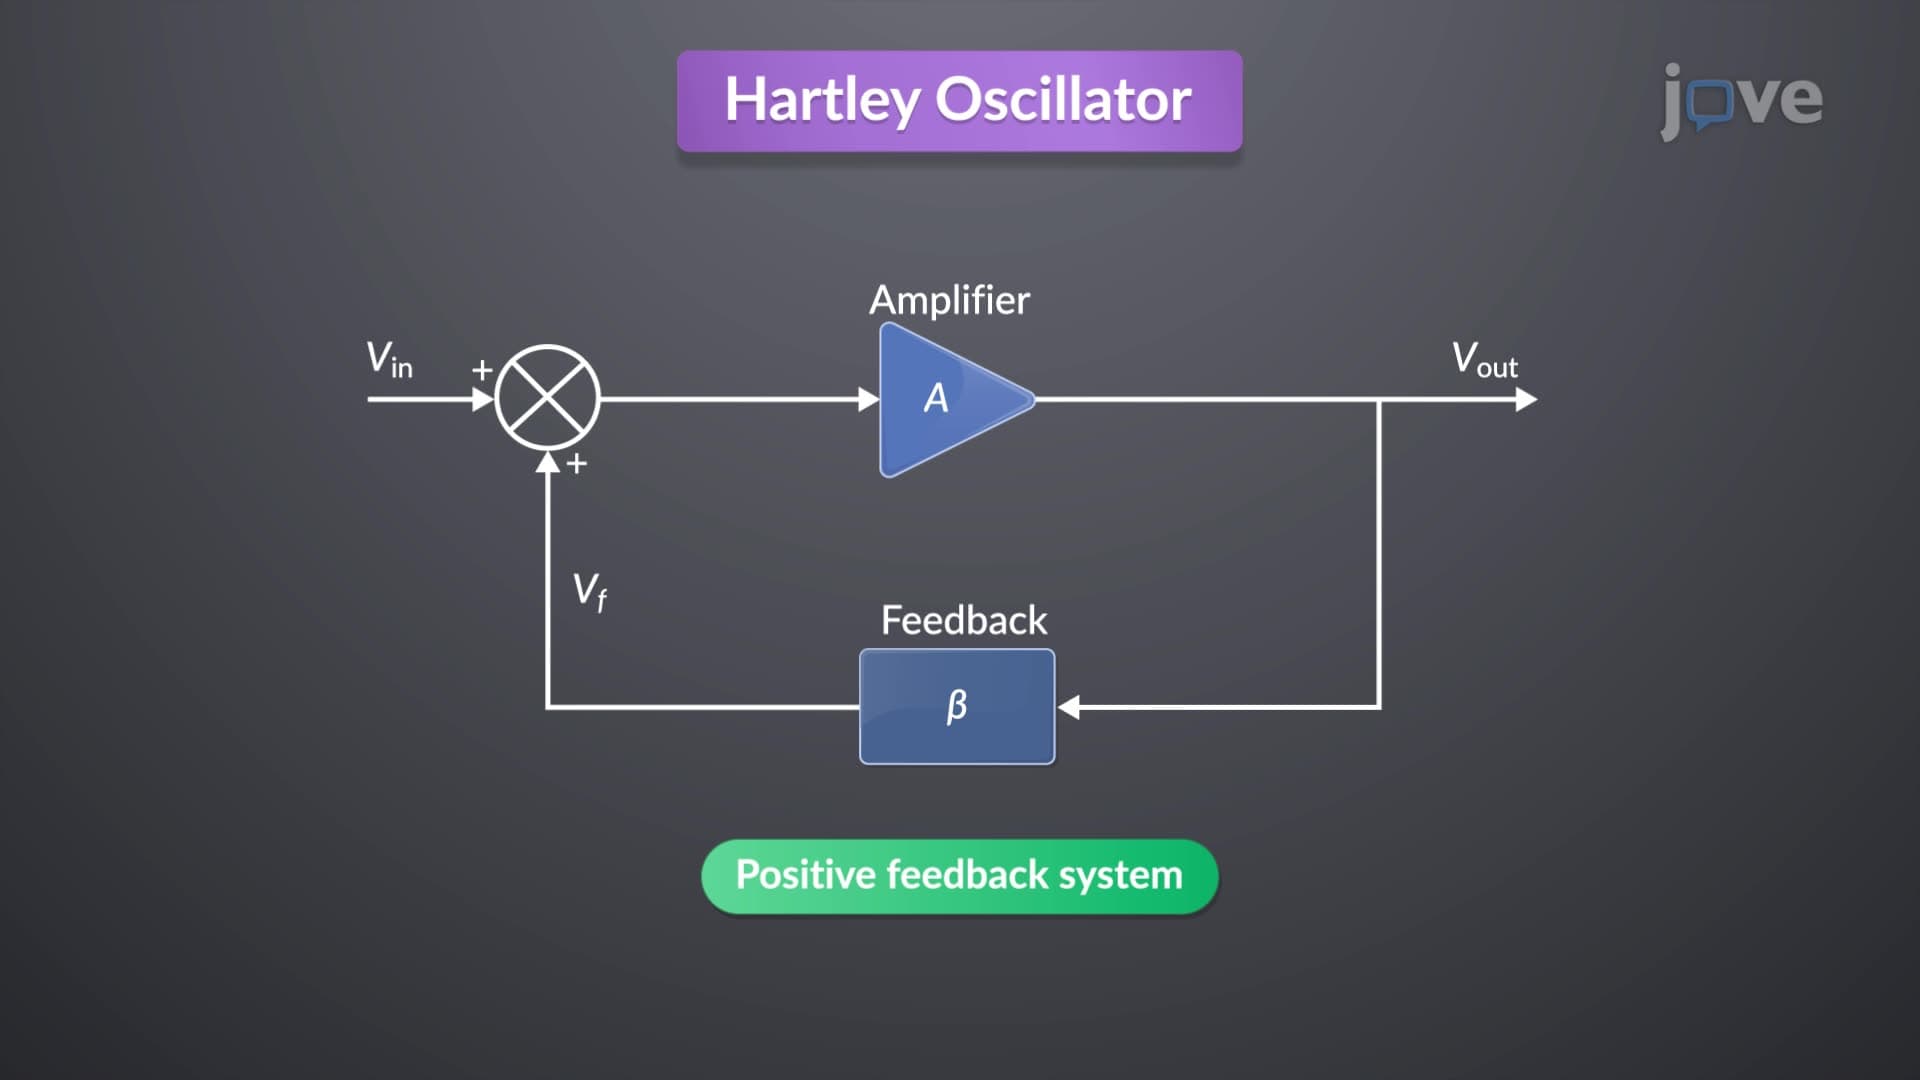
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...