Adaptive safety critical compensation control for nonlinear jump systems with its application
Related Experiment Video
Updated: May 23, 2025

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Bin Guo1, Xingxing You1, Songyi Dian1
1College of Electrical Engineering, Sichuan University, Chengdu, 610065, China.

Abstract:
In this article, the problem of adaptive safety critical tracking control for nonlinear Markovian jump systems (NMJSs) is addressed, and an event-observer-based compensation strategy is proposed. The main innovation of the presented approach is to effectively cope with the unexpected actuator faults, lumped disturbances, nonlinear uncertainties, and limited computation resources for the NMJSs. In the most existing compensation schemes, only the bias fault without jump dynamics is addressed. Here, the combined faults, disturbances and limited measurable conditions are considered. To solve the limited variable measurable problem, an integrated dynamic event-based state observer scheme is constructed. With the help of state estimation error, a high-order lumped disturbance observation scheme is established without the prior knowledge of disturbance. By virtue of observation values, an event-observer-based system performance recovery controller is proposed. In this control framework, to achieve the disturbance rejection and tracking convergence purposes, an observer-aided sliding mode surface is established. What's more, to reduce the communication burden, a novel dynamic trigger scheme in control channel and a multi-choice-based trigger condition in sensor channel are proposed, and the controller is reconstructed with the event choice. Finally, two numerical examples and the application to a robot system show the safety compensation abilities of the developed approach.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:10
Control Systems
At the heart...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
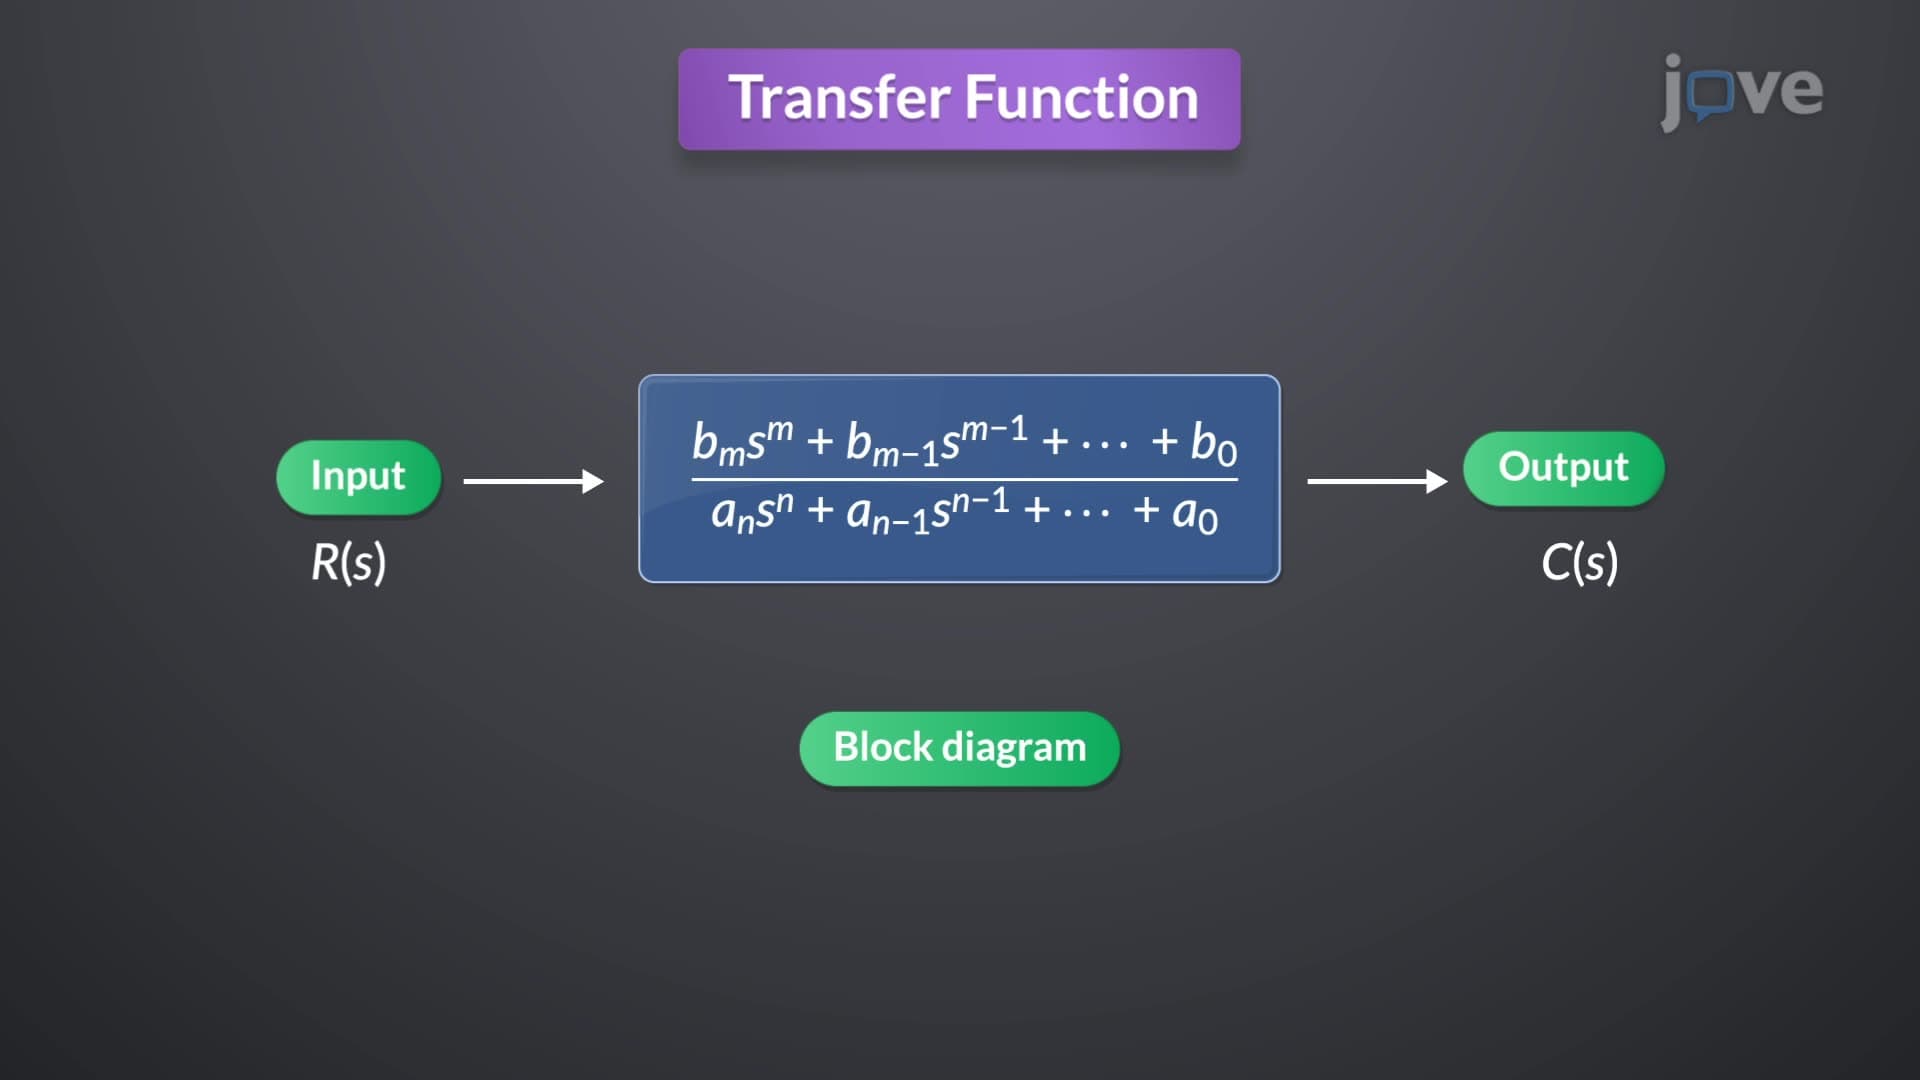 01:21
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...