Related Experiment Video
Updated: May 23, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Sampled-data stabilization of delayed Boolean control networks with state inequality constraints
Xiangshan Kong1, Enguo Gu2, Xinyun Liu1
1School of Mathematics and Statistics, Weifang University, Weifang, China.

Abstract:
This paper studies the set stabilization of delayed Boolean control networks (DBCNs) with state inequality constraints via time-variant nonuniform sampled-data control. State inequality constraints are introduced into DBCNs. Firstly, the equivalent algebraic forms of DBCNs and the solution set of state inequality constraints are constructed via the algebraic state space representation approach, based on which an inequality constrained controllability matrix is constructed. Then, by the inequality constrained controllability matrix, new criteria are proposed for the nonuniform sampled-data inequality constrained reachability of DBCNs. Finally, a time-variant nonuniform sampled-data stabilizers are designed for DBCNs by utilizing the nonuniform sampled-data inequality constrained reachability. The effectiveness of the obtained results is verified through the cell apoptosis network.


Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
State Space to Transfer Function
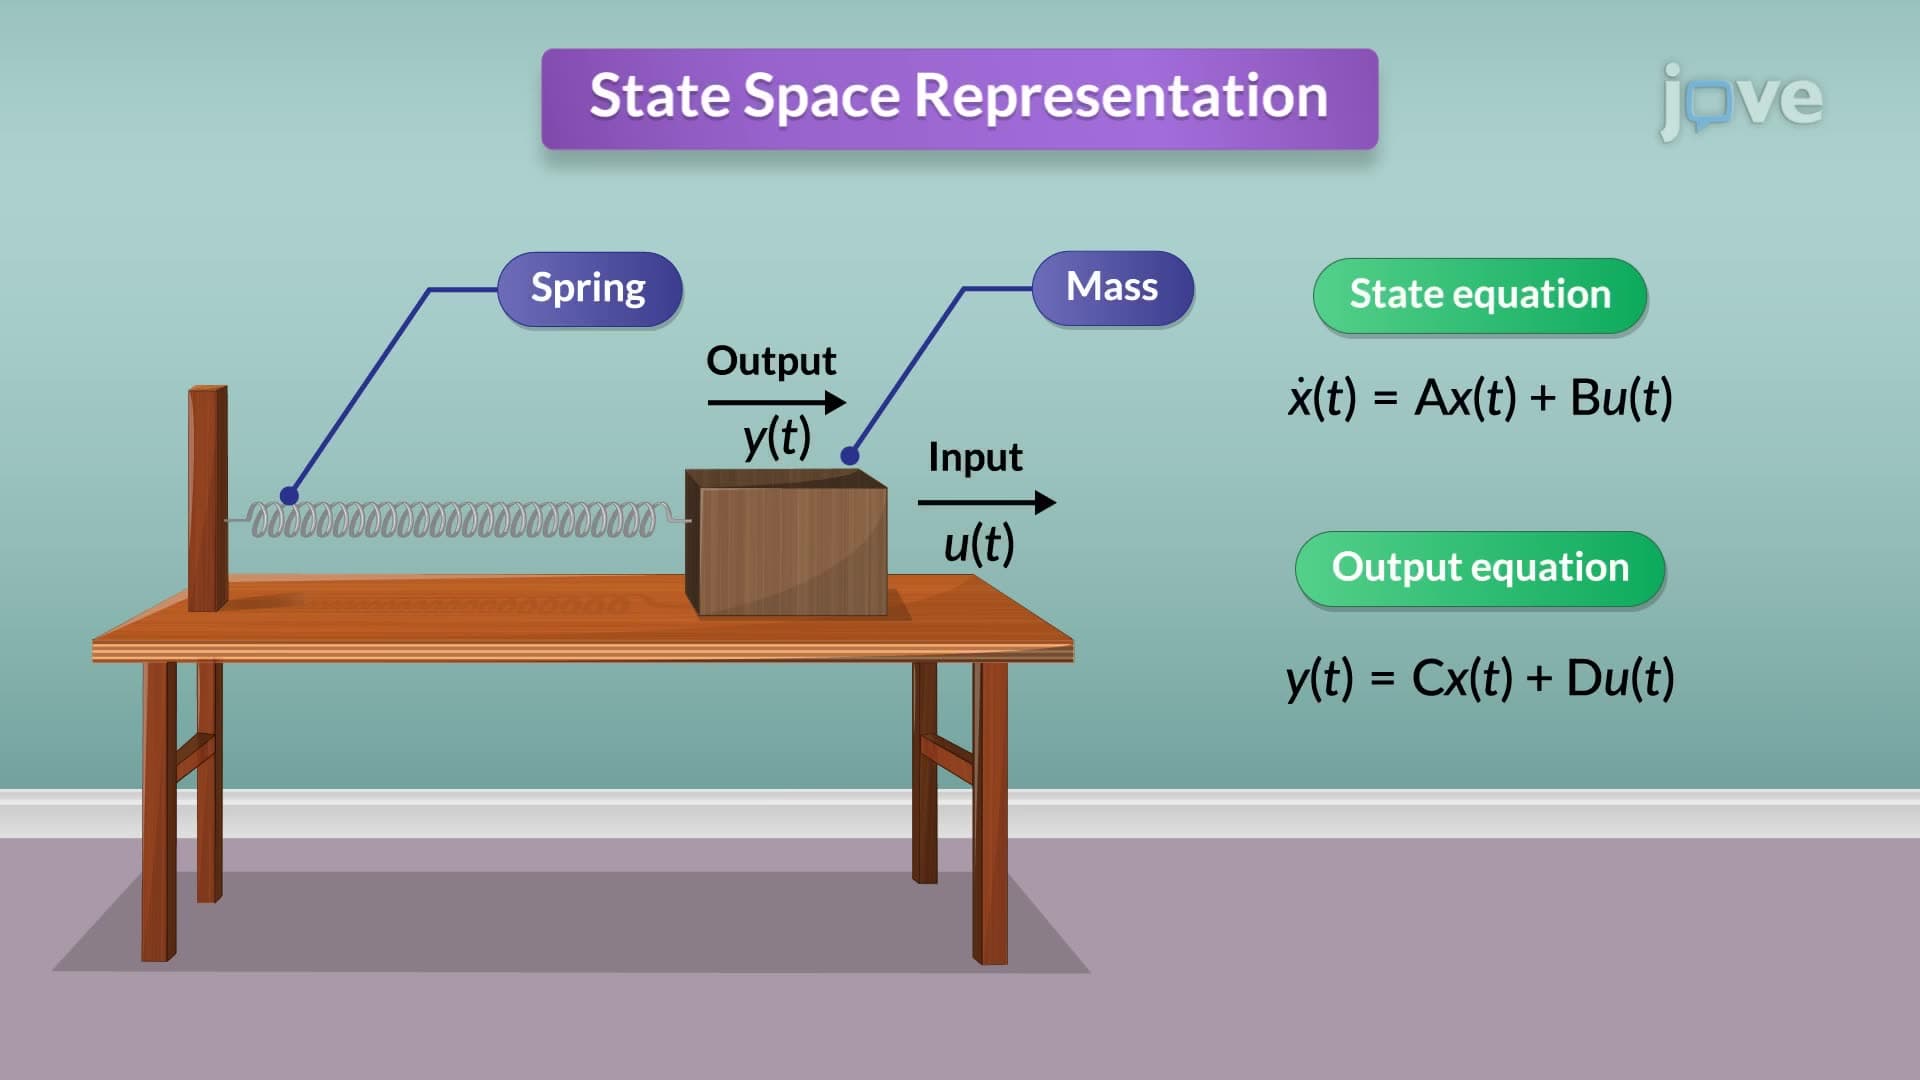
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:11
Sampling Continuous Time Signal
In the...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...