Related Experiment Video
Updated: Sep 25, 2026
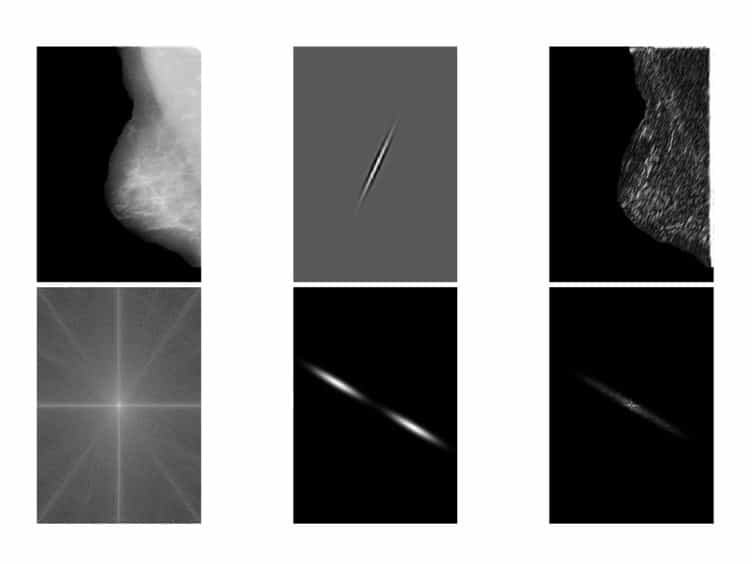

Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013
Equivariant geometric convolutions for dynamical systems on vector and tensor images
Wilson G Gregory1, David W Hogg2,3,4, Ben Blum-Smith1
1Applied Mathematics and Statistics, Johns Hopkins University, Baltimore, MD, USA.

Abstract:
Machine learning methods are increasingly being employed as surrogate models in place of computationally expensive and slow numerical integrators for a bevy of applications in the natural sciences. However, while the laws of physics are relationships between scalars, vectors and tensors that hold regardless of the frame of reference or chosen coordinate system, surrogate machine learning models are not coordinate-free by default. We enforce coordinate freedom by using geometric convolutions in three model architectures: a ResNet, a Dilated ResNet and a UNet. In numerical experiments emulating two-dimensional compressible Navier-Stokes, we see better accuracy and improved stability compared with baseline surrogate models in almost all cases. The ease of enforcing coordinate freedom without making major changes to the model architecture provides an exciting recipe for any convolutional neural network-based method applied to an appropriate class of problems.This article is part of the theme issue 'Partial differential equations in data science'.
Related Concept Videos
 01:24
Convolution: Math, Graphics, and Discrete Signals
To simplify the convolution integral, it is assumed that both the input signal and impulse response are zero for negative time values. The graphical convolution process...
 01:20
Torsion in Vector Calculus
 01:20
Convolution Properties I
The commutative property reveals that the input and the impulse response of an LTI (Linear Time-Invariant) system can be interchanged without affecting the output:
 01:17
Derivatives of Vector Functions
 01:17
Convolution Properties II
The width property indicates that if the durations of input signals are T1 and T2, then the width of the output response equals the sum of both durations, irrespective of the shapes of the two functions. For instance, convolving two rectangular pulses with durations of 2 seconds and 1 second results in a function with a width of 3 seconds.
The area property asserts that the area under the...
 01:08
Vector Algebra: Method of Components
In many applications, the magnitudes and directions of...