Related Experiment Video
Updated: Sep 19, 2025

Setting Limits on Supersymmetry Using Simplified Models
Published on: November 15, 2013
Inequivalence between the Euclidean and Lorentzian Versions of the Type IIB Matrix Model from Lefschetz Thimble
Chien-Yu Chou1, Jun Nishimura1, Ashutosh Tripathi1
1Graduate Institute for Advanced Studies, SOKENDAI, Institute of Particle and Nuclear Studies, KEK Theory Center, High Energy Accelerator Research Organization, 1-1 Oho, Tsukuba, Ibaraki 305-0801, Japan and , 1-1 Oho, Tsukuba, Ibaraki 305-0801, Japan.

Abstract:
The type IIB matrix model is conjectured to describe superstring theory nonperturbatively in terms of ten N×N bosonic traceless Hermitian matrices A_{μ} (μ=0,…,9), whose eigenvalues correspond to (9+1)-dimensional space-time. Quite often, this model has been investigated in its Euclidean version, which is well defined although the SO(9,1) Lorentz symmetry of the original model is replaced by the SO(10) rotational symmetry. Recently, a well-defined model respecting the Lorentz symmetry has been proposed by "gauge-fixing" the Lorentz symmetry nonperturbatively using the Faddeev-Popov procedure. Here we investigate the two models by Monte Carlo simulations overcoming the severe sign problem by the Lefschetz thimble method, in the case of matrix size N=2 omitting fermionic contributions. We add a quadratic term γtr(A_{μ}A^{μ}) in the action and calculate the expectation values of rotationally symmetric (or Lorentz symmetric) observables as a function of the coefficient γ. Our results exhibit striking differences between the two models around γ=0 and in the γ>0 region associated with the appearance of different saddle points, clearly demonstrating their inequivalence against naive expectations from quantum field theory.
More Related Videos
Related Concept Videos
 01:28
Symmetry in Maxwell's Equations
 01:17
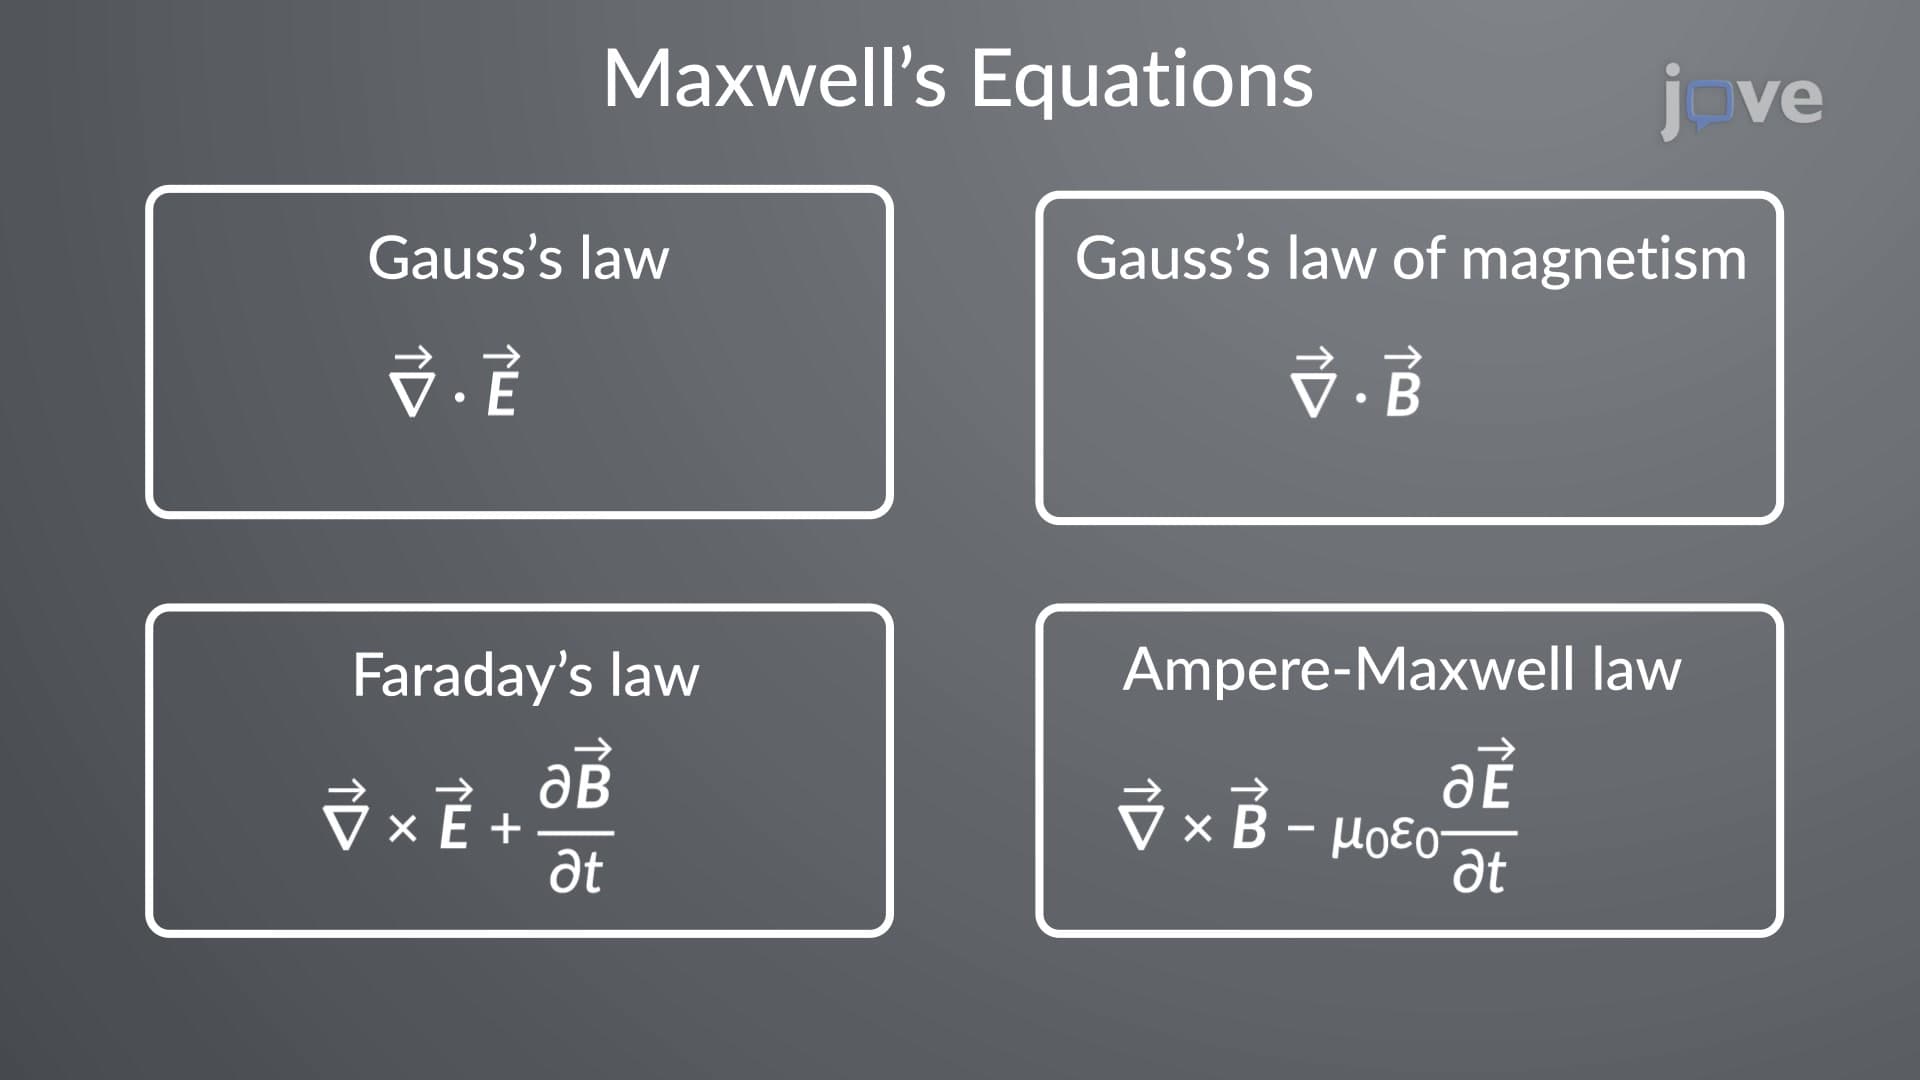
Differential Form of Maxwell's Equations
 01:24
Inertia Tensor
The diagonal components of the inertia tensor matrix represent the moments of inertia concerning the principal axes of the object. These primary axes are defined as the axes where the object experiences the least...
 01:26
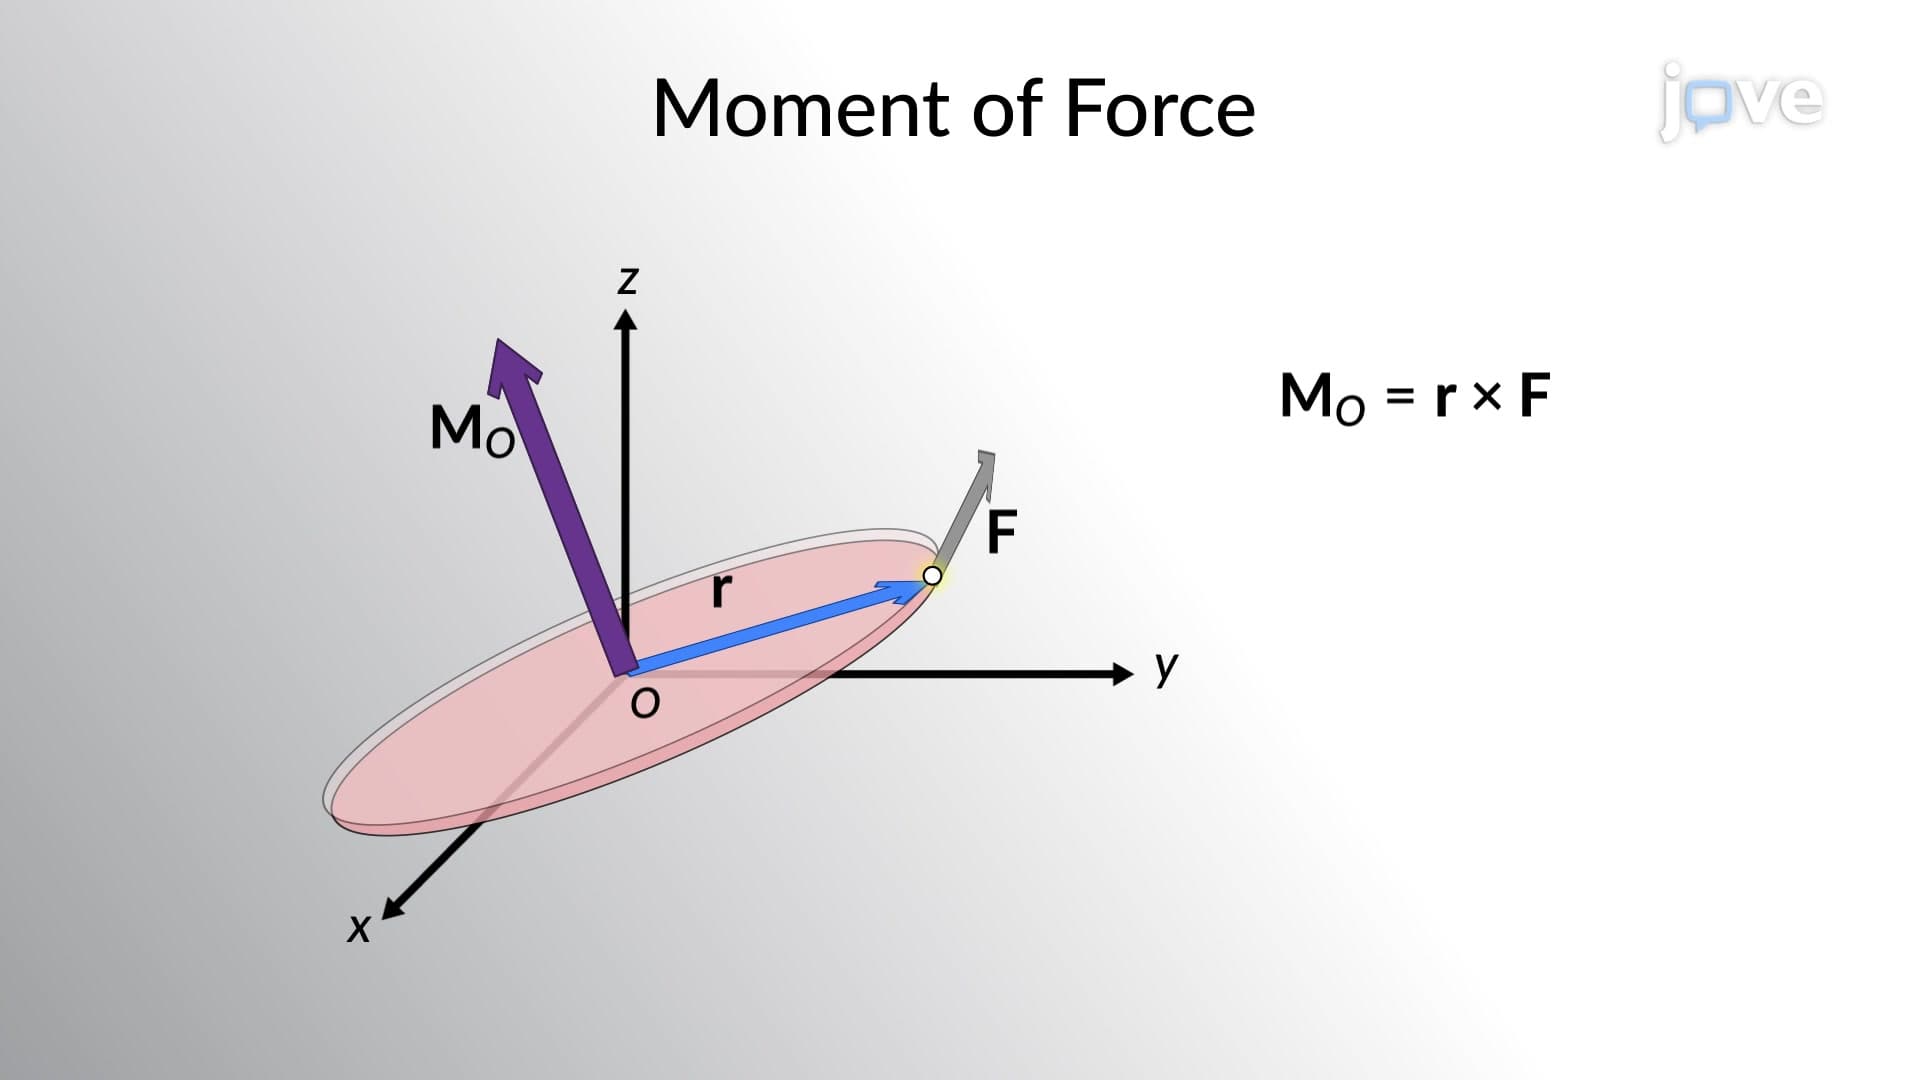
Cartesian Form for Vector Formulation
 01:17
Space-Time Curvature and the General Theory of Relativity
This has been verified in many experiments. However, space and time are no longer absolute. Two observers moving relative to one another do not agree on the length of objects or the passage of time. The mechanics of objects based on Newton's laws of...
 01:20
Gauss's Law: Cylindrical Symmetry