Related Experiment Video
Updated: Sep 18, 2025

Transtubular Endoscopic Posterolateral Decompression for L5-S1 Lumbar Lateral Disc Herniation
Published on: October 14, 2022
Percutaneous endoscopic lumbar partial laminectomy assisted by a new miniature parallel surgical robot system: a
Nan Su1, Jiashen Shao1, Gang Zhu2
1Department of Orthopedic, Beijing Friendship Hospital, Capital Medical University, Beijing, China, China.

Introduction:
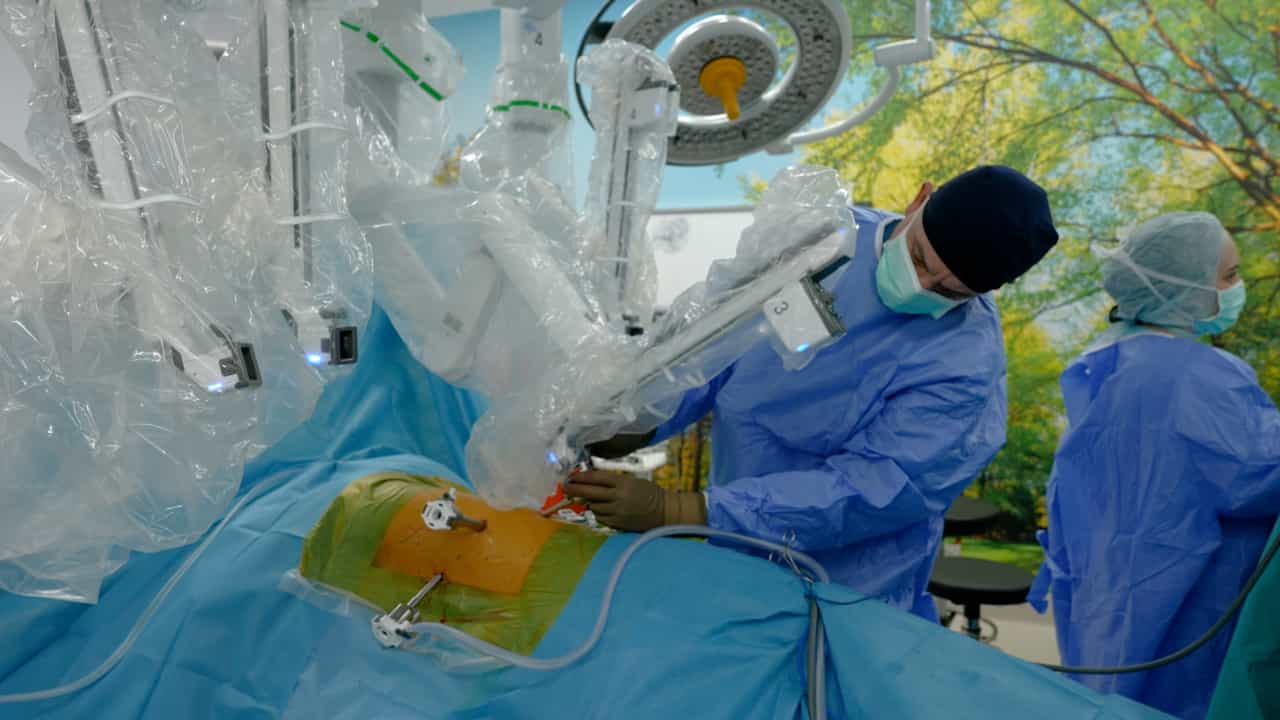
Robot‑assisted surgery is becoming increasingly popular and its application is expanding to various spinal surgical procedures, including endoscopic spinal surgery.
Aim:
The aim of this study was to describe a novel small parallel orthopedic surgical robot and evaluate its feasibility in assisting surgeons during percutaneous lumbar laminectomy on cadaveric specimens.
Materials And Methods:
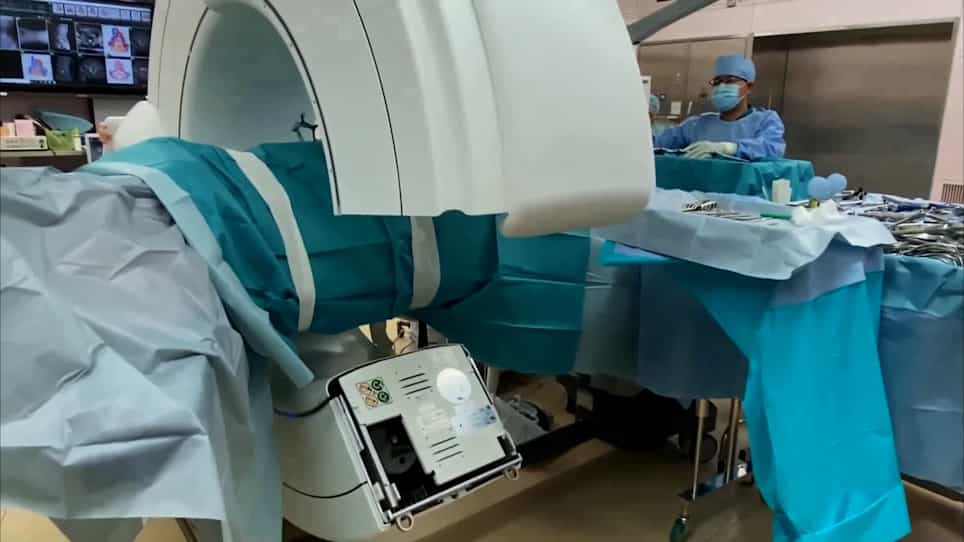
The authors of the study developed a new orthopedic surgical navigation system (R‑Pharos, Rossum Robot Co., Ltd, Beijing, China), consisting of a navigation cart and a hybrid serial‑parallel bedside robotic arm. The system is equipped with interactive software for selecting and planning the percutaneous lumbar laminectomy target and path. A cadaveric specimen was selected for a right‑side partial laminectomy at L4. During the procedure, the surgeon used the robotic arm to guide the saw to the target lamina and perform the percutaneous resection. Postoperative cone beam computed tomography (CBCT) and endoscopic assessments were used to confirm the resection outcome.
Results:
After optimizing the precision of the small parallel orthopedic surgical robot to 1 mm, it was shown to meet the navigational requirements for percutaneous lumbar laminectomy. The surgeon utilized the interactive software to design the resection range and path for the right L4 lamina which was successfully resected, as confirmed by endoscopic observation. A postoperative CBCT scan revealed that the resection area precisely matched the preoperative design.
Conclusions:
This study demonstrated that the small parallel orthopedic surgical robot was capable of preoperatively planning the lamina resection area and could assist the surgeon in performing percutaneous lumbar laminectomy with high navigational precision.