Related Experiment Video
Updated: Sep 18, 2025

Photorealistic Learned Landscapes for Augmented Reality
Published on: June 27, 2025
A Robust Rotation-Equivariant Feature Extraction Framework for Ground Texture-Based Visual Localization
Yuezhen Cai1, Linyuan Xia1, Ting On Chan1
1School of Geography and Planning, Sun Yat-sen University, Guangzhou 510275, China.

Abstract:
Ground texture-based localization leverages environment-invariant, planar-constrained features to enhance pose estimation robustness, thus offering inherent advantages for seamless localization. However, traditional feature extraction methods struggle with reliable performance under large-scale rotations and texture sparsity in the case of ground texture-based localization. This study addresses these challenges through a learning-based feature extraction framework-Ground Texture Rotation-Equivariant Keypoints and Descriptors (GT-REKD). The GT-REKD framework employs group-equivariant convolutions over the cyclic rotation group, augmented with directional attention and orientation-encoding heads, to produce dense keypoints and descriptors that are exactly invariant to 0-360° in-plane rotations. The experimental results for ground texture localization show that GT-REKD achieves 96.14% matching in pure rotation tests, 94.08% in incremental localization, and relocalization errors of 5.55° and 4.41 px (≈0.1 cm), consistently outperforming baseline methods under extreme rotations and sparse textures, highlighting its applicability to visual localization and simultaneous localization and mapping (SLAM) tasks.
More Related Videos
 08:25
Combining Eye-tracking Data with an Analysis of Video Content from Free-viewing a Video of a Walk in an Urban Park Environment
Published on: May 7, 2019
 11:57
Three-dimensional Super Resolution Microscopy of F-actin Filaments by Interferometric PhotoActivated Localization Microscopy iPALM
Published on: December 1, 2016
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Methods of Obtaining Topography
 01:16
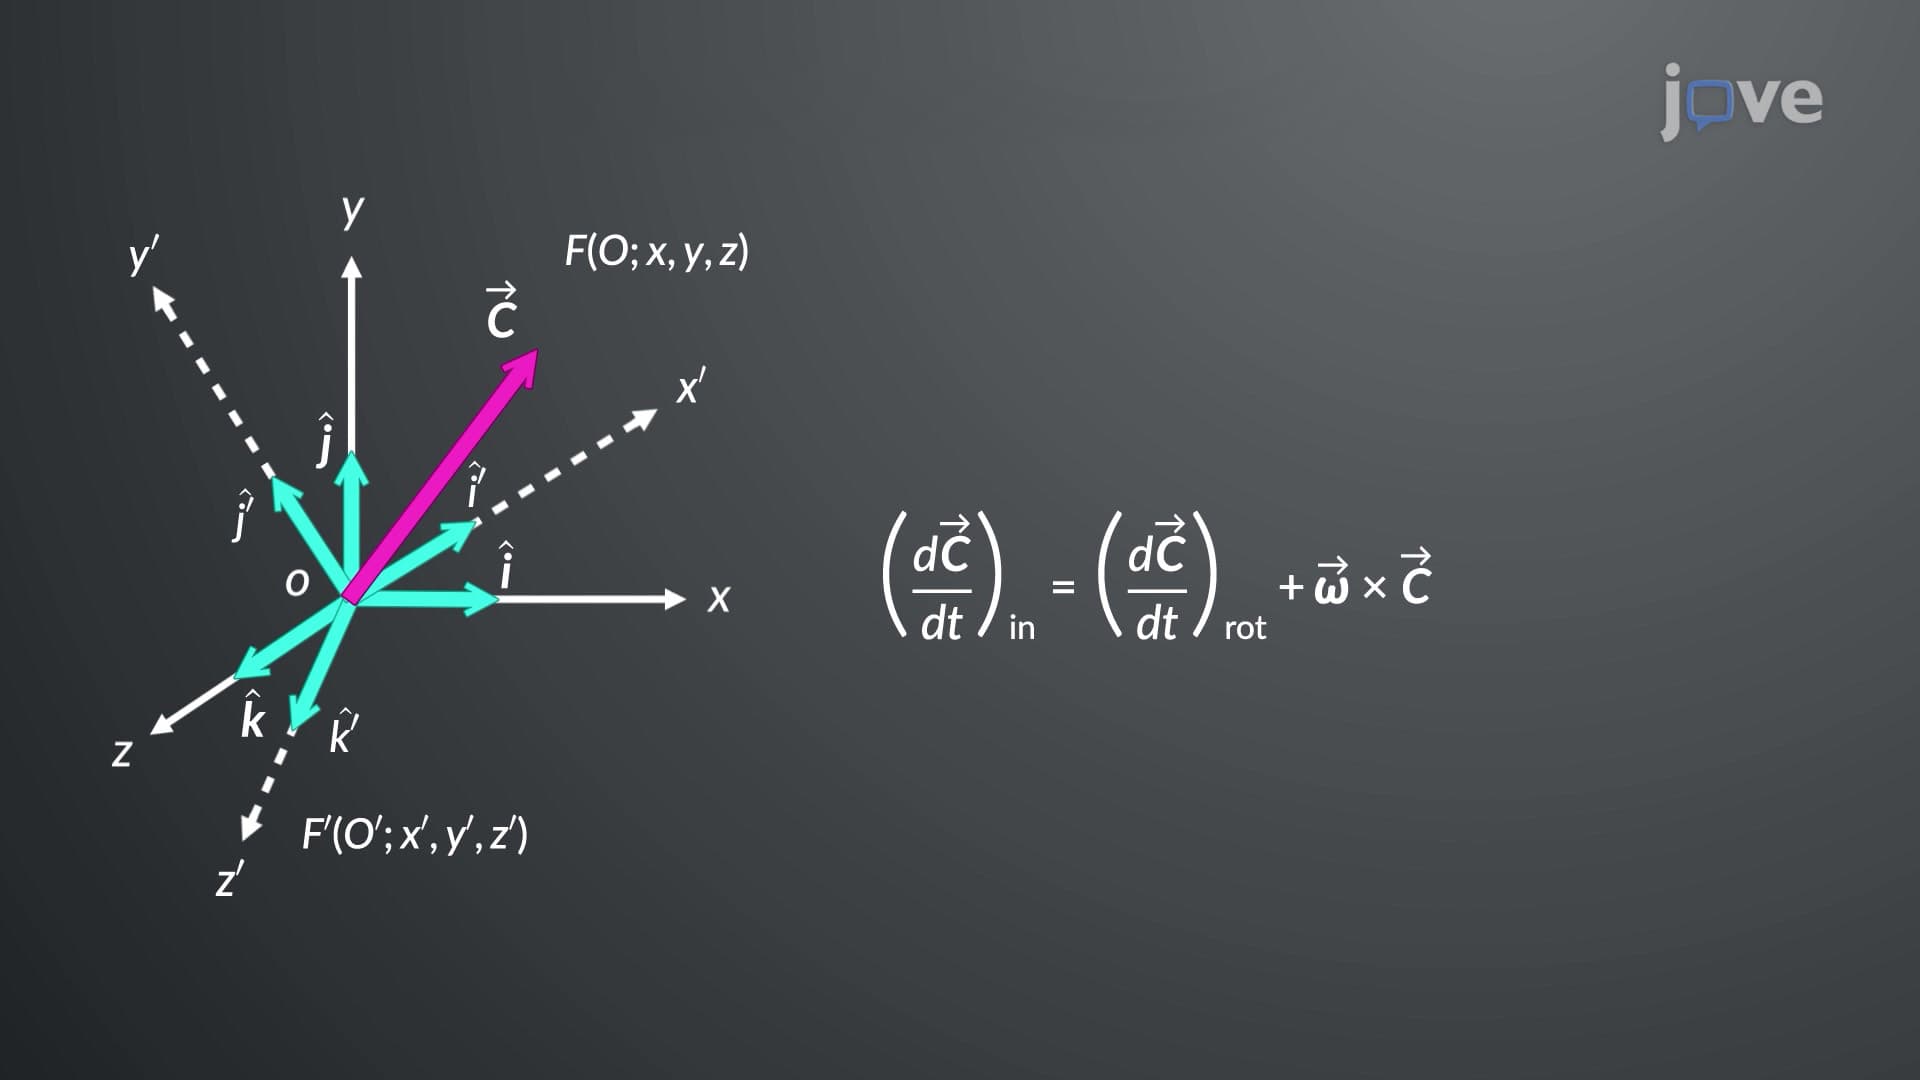
Vector Transformation in Rotating Coordinate Systems
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:25
Shape and Texture of Coarse Aggregate