Related Experiment Video
Updated: Sep 17, 2025


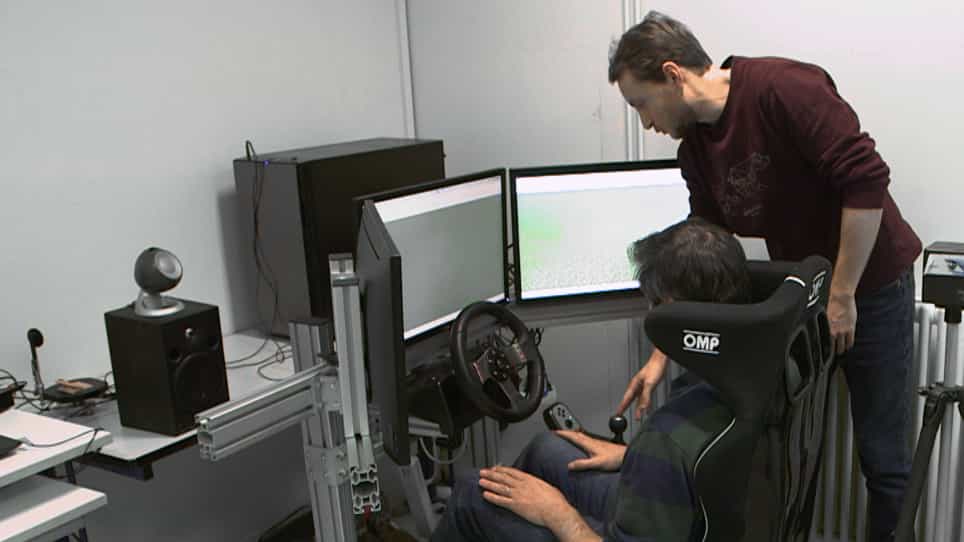
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
A perspective from competitive-cooperative driving modes: Identification of vehicle merging behavior models and crash
Nengchao Lyu1, Siqi Feng1, Hongliang Wan2
1Intelligent Transportation Systems Research Center, Wuhan University of Technology, Wuhan 430063 Hubei, China.

Abstract:
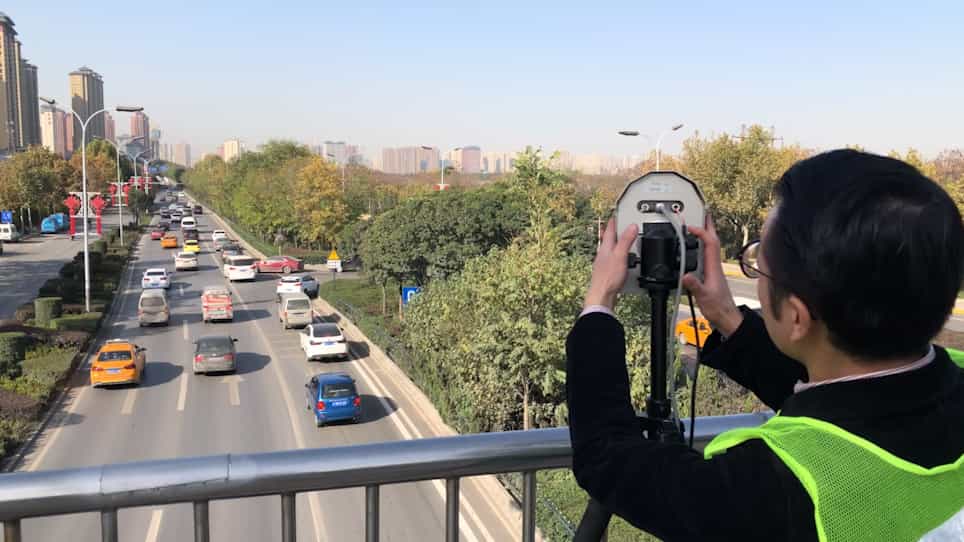
In highway and expressway merge zones, merge behavior is the most fundamental maneuvering behavior and is a major cause of traffic conflicts and collisions. While some studies have employed vehicle trajectory data to simulate and investigate microscopic merge behavior, most have failed to consider the interaction between vehicles and have not fully investigated the factors that influence merge risk using vehicle trajectory data. This study considers the interactions between vehicles during the merging process and, based on a "competitive-cooperative" driving mode perspective, proposes a new method for classifying vehicle merging behavior modes in merging zones. It also explores the differences in risk levels and influencing factors between different merging modes. Using aerial-captured merging vehicle trajectory data, and based on previous research and actual observations, merging behaviors are classified into free, homeostatic, competitive, and cooperative modes (FM, HM, CmM, and CoM) according to the gap distance and microscopic interaction between vehicles before and after merging. The lane change risk index (LCRI) is introduced as an alternative safety measure to assess the risk of merging vehicle groups. The k-means algorithm is used to classify the LCRI, and a separate ordered logit model is constructed for each merging behavior mode. The modeling results indicate that classification modeling performs better than all data modeling, and the risk level of merging vehicle groups is closely related to the motion state of the merge vehicle, the average and standard deviation of the longitudinal speed difference between vehicles, and the gap distance between vehicles. The risk levels of the four merging modes and their influencing factors differ, with FM having the lowest risk, followed by CoM, HM having a higher risk, and CmM having the highest risk. The study results provide an in-depth analysis of merge zone risk factors, offering a theoretical basis for improving traffic safety management measures.
Related Concept Videos
 01:19
Types of Collisions - II
 01:18
Hierarchy of Motor Control
 01:04
Types Of Collisions - I
 01:05
Collisions in Multiple Dimensions: Introduction
 01:14
Multicompartment Models: Overview
These models offer a more comprehensive representation of drug behavior in the body than one-compartment models. They accommodate the complexity of drug distribution,...
 01:14
Frustration and Conflict: Avoidance-Avoidance, Double-Approach Avoidance