Related Experiment Video
Updated: Sep 17, 2025
Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
A pedestrian group crossing intention prediction model integrating spatiotemporal features
Hai Zou1, Yongqing Guo2, Fulu Wei1
1School of Transportation and Vehicle Engineering, Shandong University of Technology, Zibo, 255000, China.

Abstract:
Pedestrians, as vulnerable road users (VRUs), lack effective protective measures in traffic accidents, making them highly susceptible to injuries. Accurate prediction of pedestrian behavior is crucial for road safety, traffic management systems, advanced driver-assistance systems (ADAS), and autonomous vehicle development. Against this backdrop, this paper proposes a pedestrian group crossing intention prediction model that integrates spatiotemporal features to enhance the accuracy of pedestrian behavior prediction in autonomous driving scenarios. The model combines spatiotemporal features, including pedestrian pose key points, 2D positional trajectories, and group information. Experimental results on the JAADbeh and JAADall datasets demonstrate that the proposed model achieves superior performance in terms of accuracy, precision, and F1-Score. Notably, on the complex and large-scale JAADall dataset, the model achieves an accuracy of 0.82, highlighting its robustness. Furthermore, the findings reveal that incorporating pedestrian group information improves prediction accuracy, especially in group pedestrian scenarios, where this feature significantly enhances detection performance. This study provides a reliable pedestrian intention prediction framework for autonomous driving and intelligent transportation systems, while also laying a foundation for future exploration of diverse non-visual features and complex scenarios.
Related Concept Videos
 01:03
Prediction Intervals
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.
 01:07
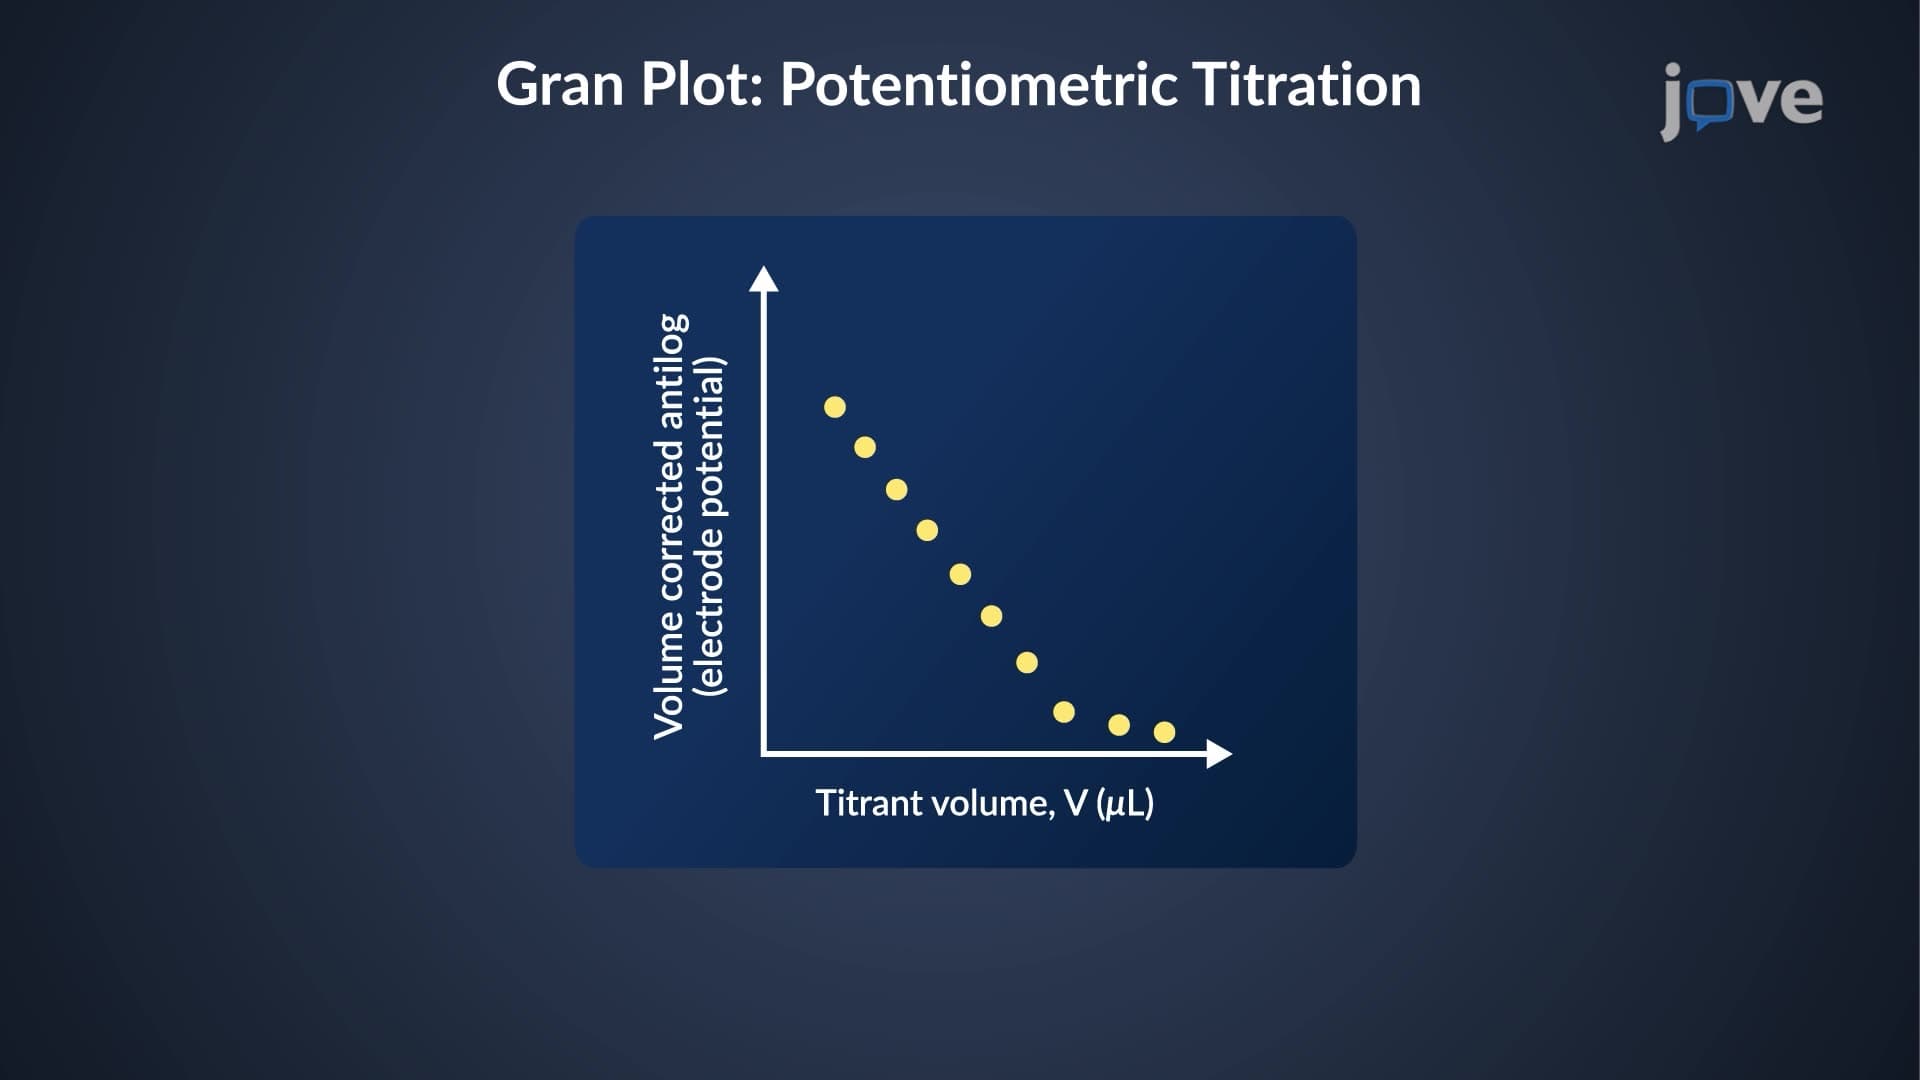
End Point Prediction: Gran Plot
For potentiometric titration, the Gran plot is created by plotting...