Related Experiment Video
Updated: Sep 17, 2025
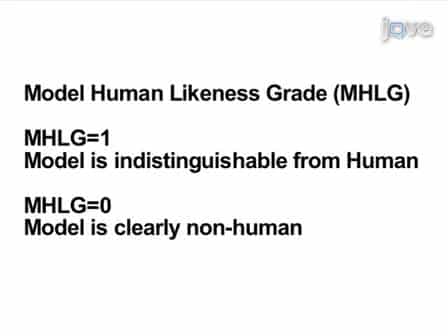
One Dimensional Turing-Like Handshake Test for Motor Intelligence
Published on: December 15, 2010
Simulation theory of mind for heterogeneous human-robot teams
Monica Nicolescu1, Janelle Blankenburg1, Bashira Akter Anima1
1Robotics Research Laboratory, Department of Computer Science and Engineering, University of Nevada, Reno, NV, United States.

Abstract:
This paper focuses on the problem of collaborative task execution by teams comprising of people and multiple heterogeneous robots. In particular, the problem is motivated by the need for the team members to dynamically coordinate their execution, in order to avoid overlapping actions (i.e. multiple team members working on the same part of the task) and to ensure a correct execution of the task. This paper expands on our own prior work on collaborative task execution by single human-robot and single robot-robot teams, by taking an approach inspired by simulation Theory of Mind (ToM) to develop a real-time distributed architecture that enables collaborative execution of tasks with hierarchical representations and multiple types of execution constraints by teams of people and multiple robots with variable heterogeneity. First, the architecture presents a novel approach for concurrent coordination of task execution with both human and robot teammates. Second, a novel pipeline is developed in order to handle automatic grasping of objects with unknown initial locations. Furthermore, the architecture relies on a novel continuous-valued metric which accounts for a robot's capability to perform tasks during the dynamic, on-line task allocation process. To assess the proposed approach, the architecture is validated with: 1) a heterogeneous team of two humanoid robots and 2) a heterogeneous team of one human and two humanoid robots, performing a household task in different environmental conditions. The results support the proposed approach, as different environmental conditions result in different and continuously changing values for the robots' task execution abilities. Thus, the proposed architecture enables adaptive, real-time collaborative task execution through dynamic task allocation by a heterogeneous human-robot team, for tasks with hierarchical representations and multiple types of constraints.
Related Concept Videos
 02:16
Stereotype Content Model
 01:13
Nonconscious Mimicry
 01:20
Introduction to Cognitive Psychology
This field emerged in the mid-20th century, following a period dominated by behaviorism, which...
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...