Related Experiment Video
Updated: Sep 17, 2025
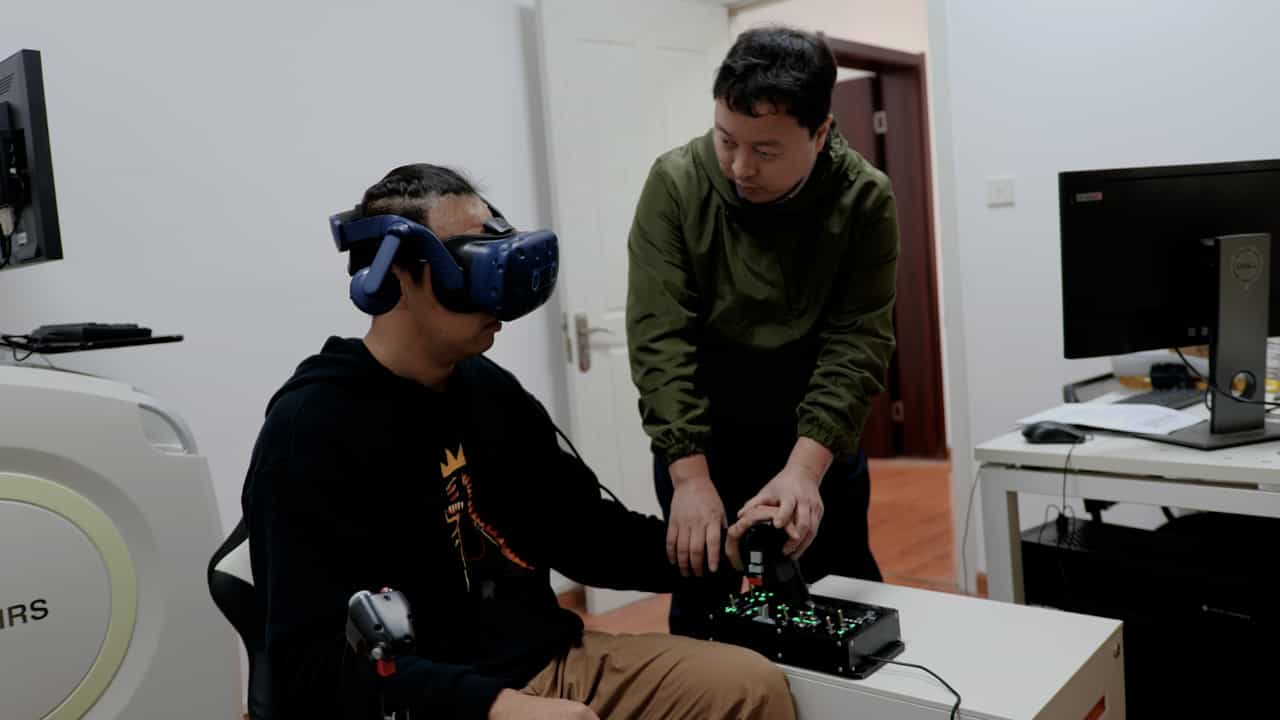

Evaluating Flight Performance and Eye Movement Patterns Using Virtual Reality Flight Simulator
Published on: May 19, 2023
InvSim algorithm for pre-computing airplane flight controls in limited-range autonomous missions, and demonstration
1College of Engineering, University of Buraimi, Al Buraimi, 512, Sultanate of Oman. osama.m@uob.edu.om.

Abstract:
In this work, we start with a generic mathematical framework for the equations of motion (EOM) in flight mechanics with six degrees of freedom (6-DOF) for a general (not necessarily symmetric) fixed-wing aircraft. This mathematical framework incorporates (1) body axes (fixed in the airplane at its center of gravity), (2) inertial axes (fixed in the earth/ground at the take-off point), wind axes (aligned with the flight path/course), (3) spherical flight path angles (azimuth angle measured clockwise from the geographic north, and elevation angle measured above the horizon plane), and (4) spherical flight angles (angle of attack and sideslip angle). We then manipulate these equations of motion to derive a customized version suitable for inverse simulation flight mechanics, where a target flight trajectory is specified while a set of corresponding necessary flight controls to achieve that maneuver are predicted. We then present a numerical procedure for integrating the developed inverse simulation (InvSim) system in time; utilizing (1) symbolic mathematics, (2) explicit fourth-order Runge-Kutta (RK4) numerical integration technique, and (3) expressions based on the finite difference method (FDM); such that the four necessary control variables (engine thrust force, ailerons' deflection angle, elevators' deflection angle, and rudder's deflection angle) are computed as discrete values over the entire maneuver time, and these calculated control values enable the airplane to achieve the desired flight trajectory, which is specified by three inertial Cartesian coordinates of the airplane, in addition to the Euler's roll angle. We finally demonstrate the proposed numerical procedure of flight mechanics inverse simulation (InvSim) through an example case that is representative of the Mirage III family of French fighter airplanes, in which a straight subsonic flight with a double-roll maneuver over a duration of 30 s at an altitude of 5 km (3.107 mi or 16,404 ft) is inversely simulated.

Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:19
Principle of Angular Impulse and Momentum: Problem Solving
Initially, a free-body diagram of the system is drawn to illustrate all the forces acting upon the system, providing a crucial understanding of the dynamics at play. Then, the principle of angular impulse and momentum is...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...