Related Experiment Video
Updated: Jul 12, 2026
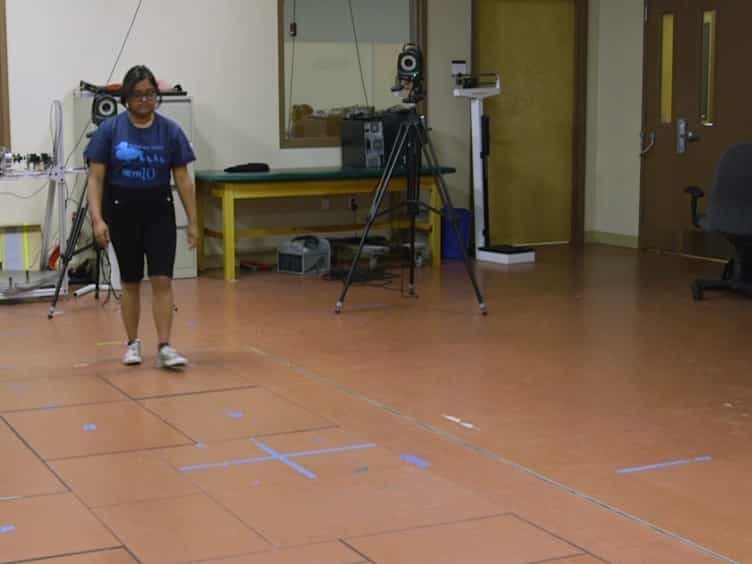
Using a Split-belt Treadmill to Evaluate Generalization of Human Locomotor Adaptation
Published on: August 23, 2017
Gait speed and incline modulate peak deceleration and timing of horizontal center of mass deceleration during double
Shizuku Terui1, Nanami Kanda2, Keisuke Hirata1,2
1Department of Rehabilitation, Faculty of Health Sciences, Tokyo Kasei University, 2-15-1 Inariyama, Sayama-shi, Saitama 350-1398, Japan.

Abstract:
Adapting gait to varying speeds and inclines is essential for navigating complex environments. The movement of the center of mass (CoM) in the horizontal plane during the double-support phase is considered critical for maintaining gait performance, but how specific CoM deceleration patterns adapt to these challenges is not fully understood. This study examined how gait speed and incline affect the most deceleration (MD) and its timing (MDt) of CoM movement in the horizontal plane during the double-support phase of gait in healthy individuals. Fourteen healthy young adults walked on a treadmill under four conditions combining two speeds (moderate: 0.83 m/s, fast: 1.0 m/s) and two inclines (level: 0°, uphill: +6°). CoM movements were recorded using a motion capture system. Key parameters analyzed included double support time ratio (DST), step length (SL), MD and MDt. SL increased with speed but was not significantly affected by incline at matched speeds; DST remained unchanged across conditions. Crucially, MD significantly increased with both faster speed and incline, being largest under the uphill-fast condition. Furthermore, MDt occurred significantly earlier in the gait cycle during faster and uphill conditions compared to moderate-speed level walking. This peak deceleration consistently occurred just prior to contralateral toe-off. Our study concludes that healthy young adults adapt to increased gait speed and incline by modulating both the deceleration and timing of CoM movement in the horizontal plane during double support. The increased deceleration and its earlier timing, particularly under challenging conditions, may reflect kinematic adaptations related to momentum regulation and step-to-step coordination, rather than indicating of neuromuscular control. These findings provide insight into potential mechanisms underlying gait adaptation in healthy individuals.
More Related Videos
Related Concept Videos
 01:34
Velocity and Position by Graphical Method
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:19
Root-Locus Method
This system can be represented by a block diagram,...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:28
Load-frequency control
 01:17
Common Leveling Mistakes and Errors