Related Experiment Video
Updated: Sep 16, 2025
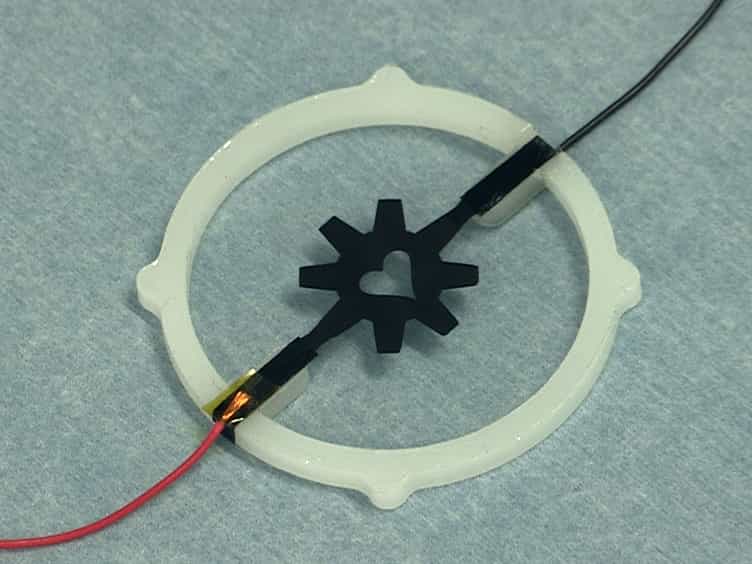

Fabrication Process of Silicone-based Dielectric Elastomer Actuators
Published on: February 1, 2016
Advancing Soft Rehabilitation Robotics: Evaluating the Stress and Strain Generation Capabilities of Stacked

Abstract:
To improve exoskeleton acceptability, there is increasing interest in soft actuators that operate safely near the human body. Dielectric elastomer actuators (DEAs) are particularly promising due to their silent operation and high energy density. In this study, we evaluate the stress and strain generation capabilities of the latest version of commercially available stacked dielectric elastomer actuators (SDEA-1550s) for rehabilitation robotics. This demand for soft, lightweight, and noiseless actuators is especially critical in pediatric applications, where current systems often lack a natural feel and suffer from low user acceptance. We investigated the pushing and pulling forces of SDEAs under two conditions: isometric contraction and free-standing. In isometric tests, peak forces reached 32.82 N and 28.75 N at 1200 V for compressive (pulling) force and tensile (pushing) force, respectively. In the freestanding setup at 800 V, the actuators achieved 1.61 mm of displacement in 0.038 seconds, with a peak strain rate of 4232.4 %/s, demonstrating rapid contraction. Notably, this study reports, for the first time, the capability of SDEAs to generate bidirectional force-both actively (pulling) and passively (pushing)-further differentiating their performance from other alternative actuators. These results highlight the enhanced stress and strain generation of SDEAs, reinforcing their potential as artificial skeletal muscles. Their integration into rehabilitation robotics-including biomimetic exoskeletons-aims to improve functionality and user experience, particularly in pediatric rehabilitation.