Related Experiment Video
Updated: Jun 7, 2026


Investigating Motor Skill Learning Processes with a Robotic Manipulandum
Published on: February 12, 2017
Personalized Robotic Training on a Planar Reaching Task

Abstract:
Based on recent advancements in neuro-adaptive control, we evaluated a novel iterative algorithm for generating customized training forces. The objective was to study the motor adaptation required to compensate for robot-generated perturbations during an upper-limb reaching task. We hypothesized that the adaptation process would induce changes in the brain's feed-forward command, dynamically reshaping the neuromuscular system to refine movement patterns and result in trajectory alterations. The results indicate that after a training period with these robot-generated forces, trajectories undergo modifications due to internal model adaptation, leading to improved performance measured in terms of position error. This experiment explores motor learning in different directions and compares two conditions: 1) curl force field, a velocitydependent perturbation applied to deviate trajectories, and 2) Error Field force, a customized force specifically designed to address and correct trajectory errors. The findings highlight the effectiveness of the Error Field force in enhancing motor learning and show the potential of customized robotic perturbation forces for improving motor performance in personal activities and advancing neurorehabilitation techniques.
More Related Videos
 07:52
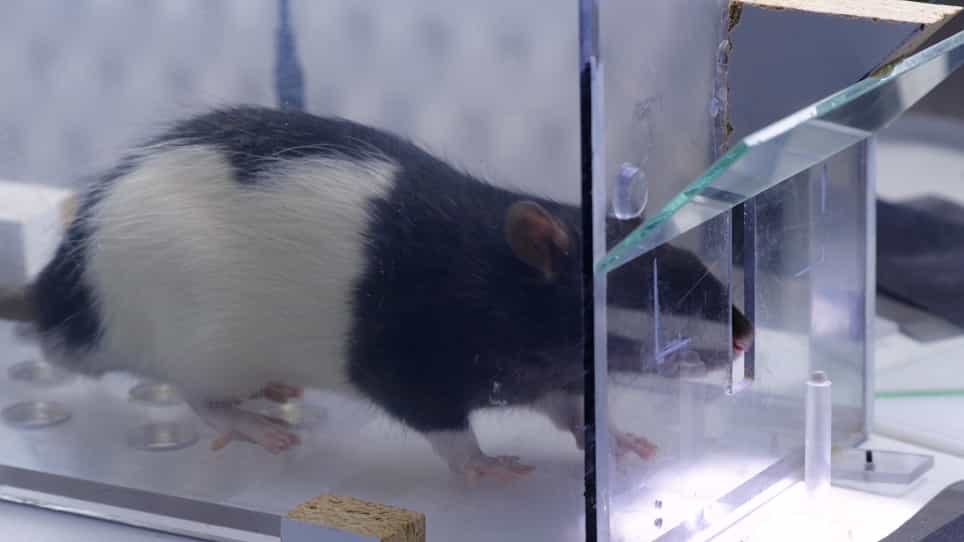
Automated Rat Single-Pellet Reaching with 3-Dimensional Reconstruction of Paw and Digit Trajectories
Published on: July 10, 2019
 04:49
Author Spotlight: Enhancing Post-Stroke Upper Limb Rehabilitation with Robotic Technologies for Improved Motor Recovery and Functional Outcomes
Published on: September 6, 2024
Related Concept Videos
 02:16
Stereotype Content Model
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:30
Machines: Problem Solving II