Enhanced obstacle avoidance for autonomous underwater vehicles via path integral control based on guiding vector field
Related Experiment Video
Updated: Jul 11, 2026
Quantitatively Measuring In situ Flows using a Self-Contained Underwater Velocimetry Apparatus (SCUVA)
Published on: October 31, 2011
Jintao Zhao1, Tao Liu2, Junhao Huang1
1School of Ocean Engineering and Technology, Sun Yat-sen University & Southern Marine Science and Engineering Guangdong Laboratory, Zhuhai 519000, China.

Abstract:
Autonomous Underwater Vehicles (AUVs) face significant challenges in tracking, navigation, and obstacle avoidance-critical aspects for advancing intelligent underwater robotics. This research presents a new navigation technique that combines Guiding Vector Field (GVF) concepts with Model Predictive Path Integral (MPPI) control to improve the precision and efficiency of vectored thruster AUV operating in complex environments. The proposed approach utilizes the AUV's relative positioning and environmental data to generate obstacle avoidance trajectories as desired GVF. Subsequently, MPPI optimization is applied to control inputs, considering dynamic constraints, to achieve effective tracking and obstacle avoidance. Extensive simulation experiments demonstrate the method's efficacy in navigating complex scenarios with non-convex obstacles. In the aspect of path tracking, the tracking error is reduced by 64 %, while maintaining safe distances in various obstacle configurations. Results show that the integrated method successfully combines local optimization prediction capabilities of MPPI with the global velocity planning of GVF, enabling efficient AUV navigation in intricate environments while ensuring the effectiveness and safety of the execution process. The method demonstrates robust performance even under disturbance conditions, maintaining a tracking error of only 0.017 m. This research contributes a solution for AUV operation in challenging maritime settings, with applications in marine surveying, underwater search and rescue, and offshore operations. By addressing key challenges in underwater navigation, this study advances the practical capabilities of AUV technology, paving the way for more efficient and reliable underwater robotic systems.
Related Concept Videos
 01:11
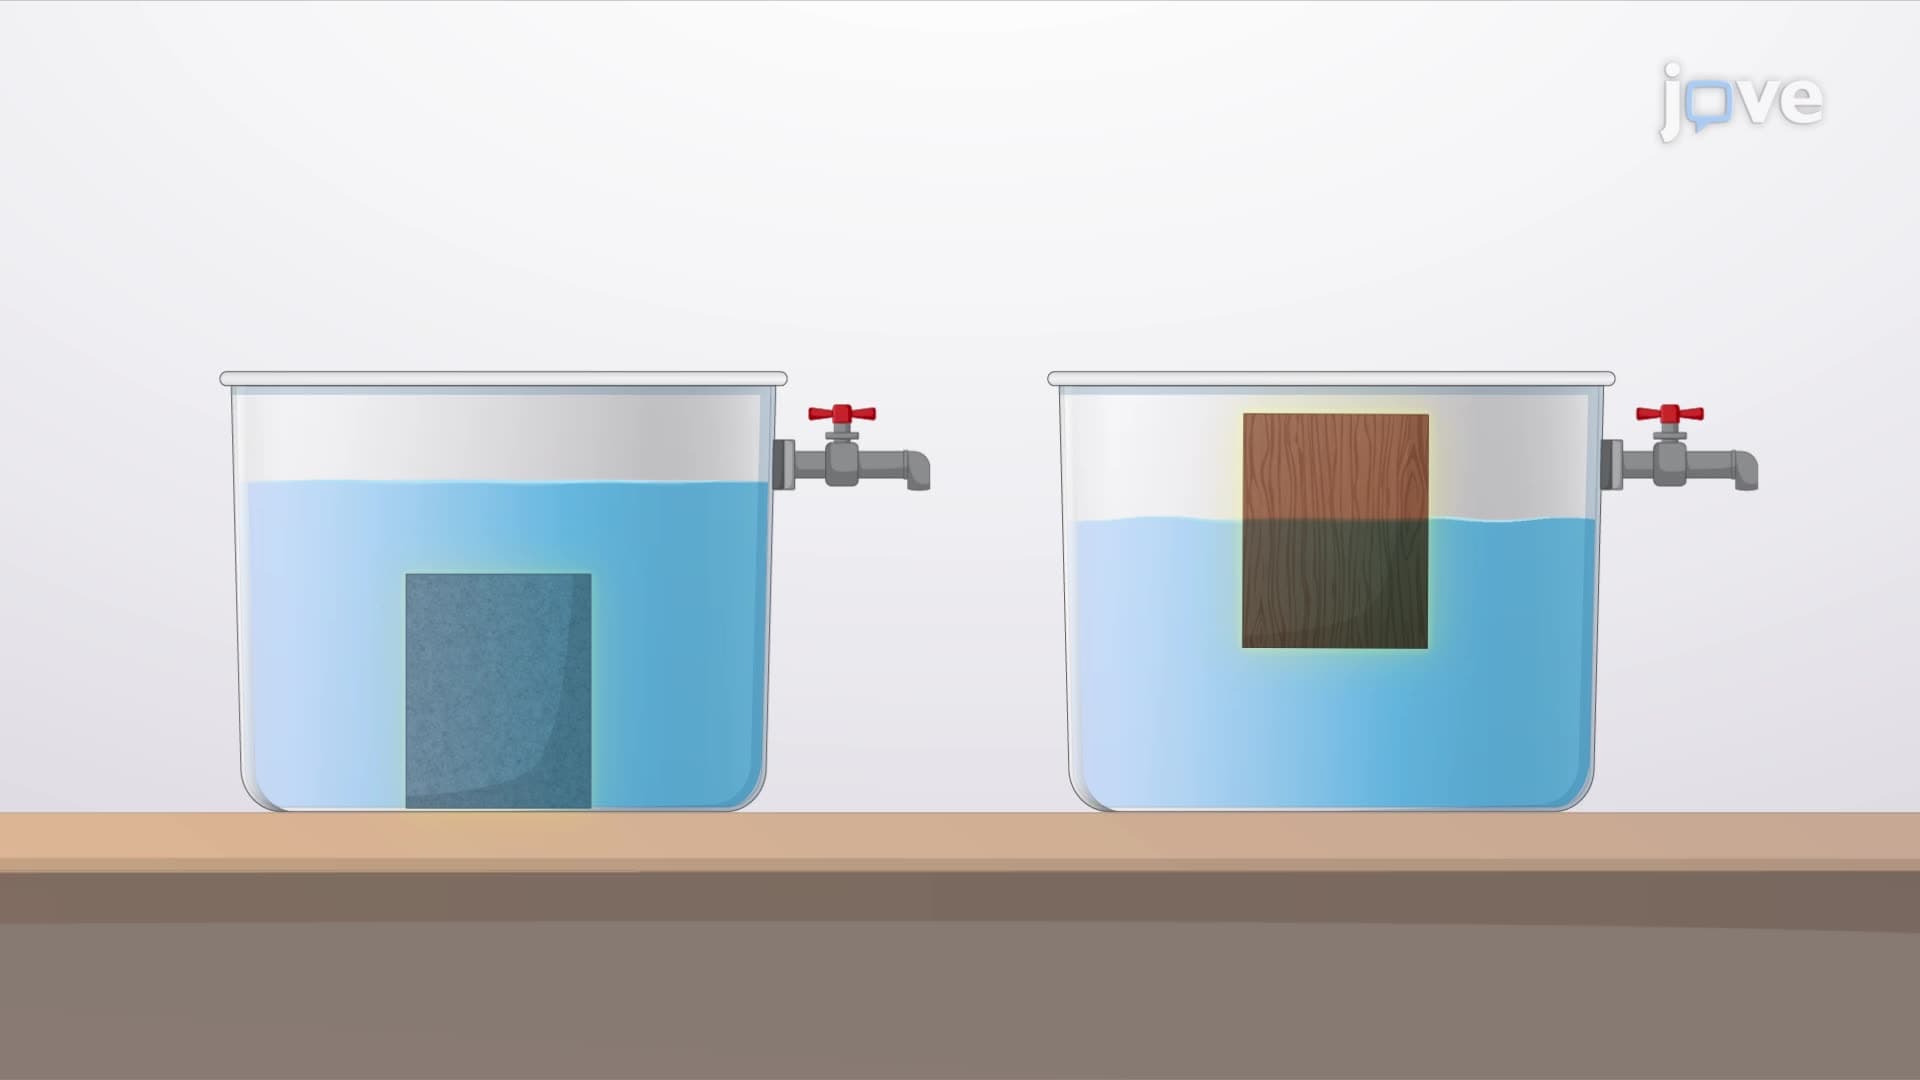
Buoyancy and Stability for Submerged and Floating Bodies
 01:14
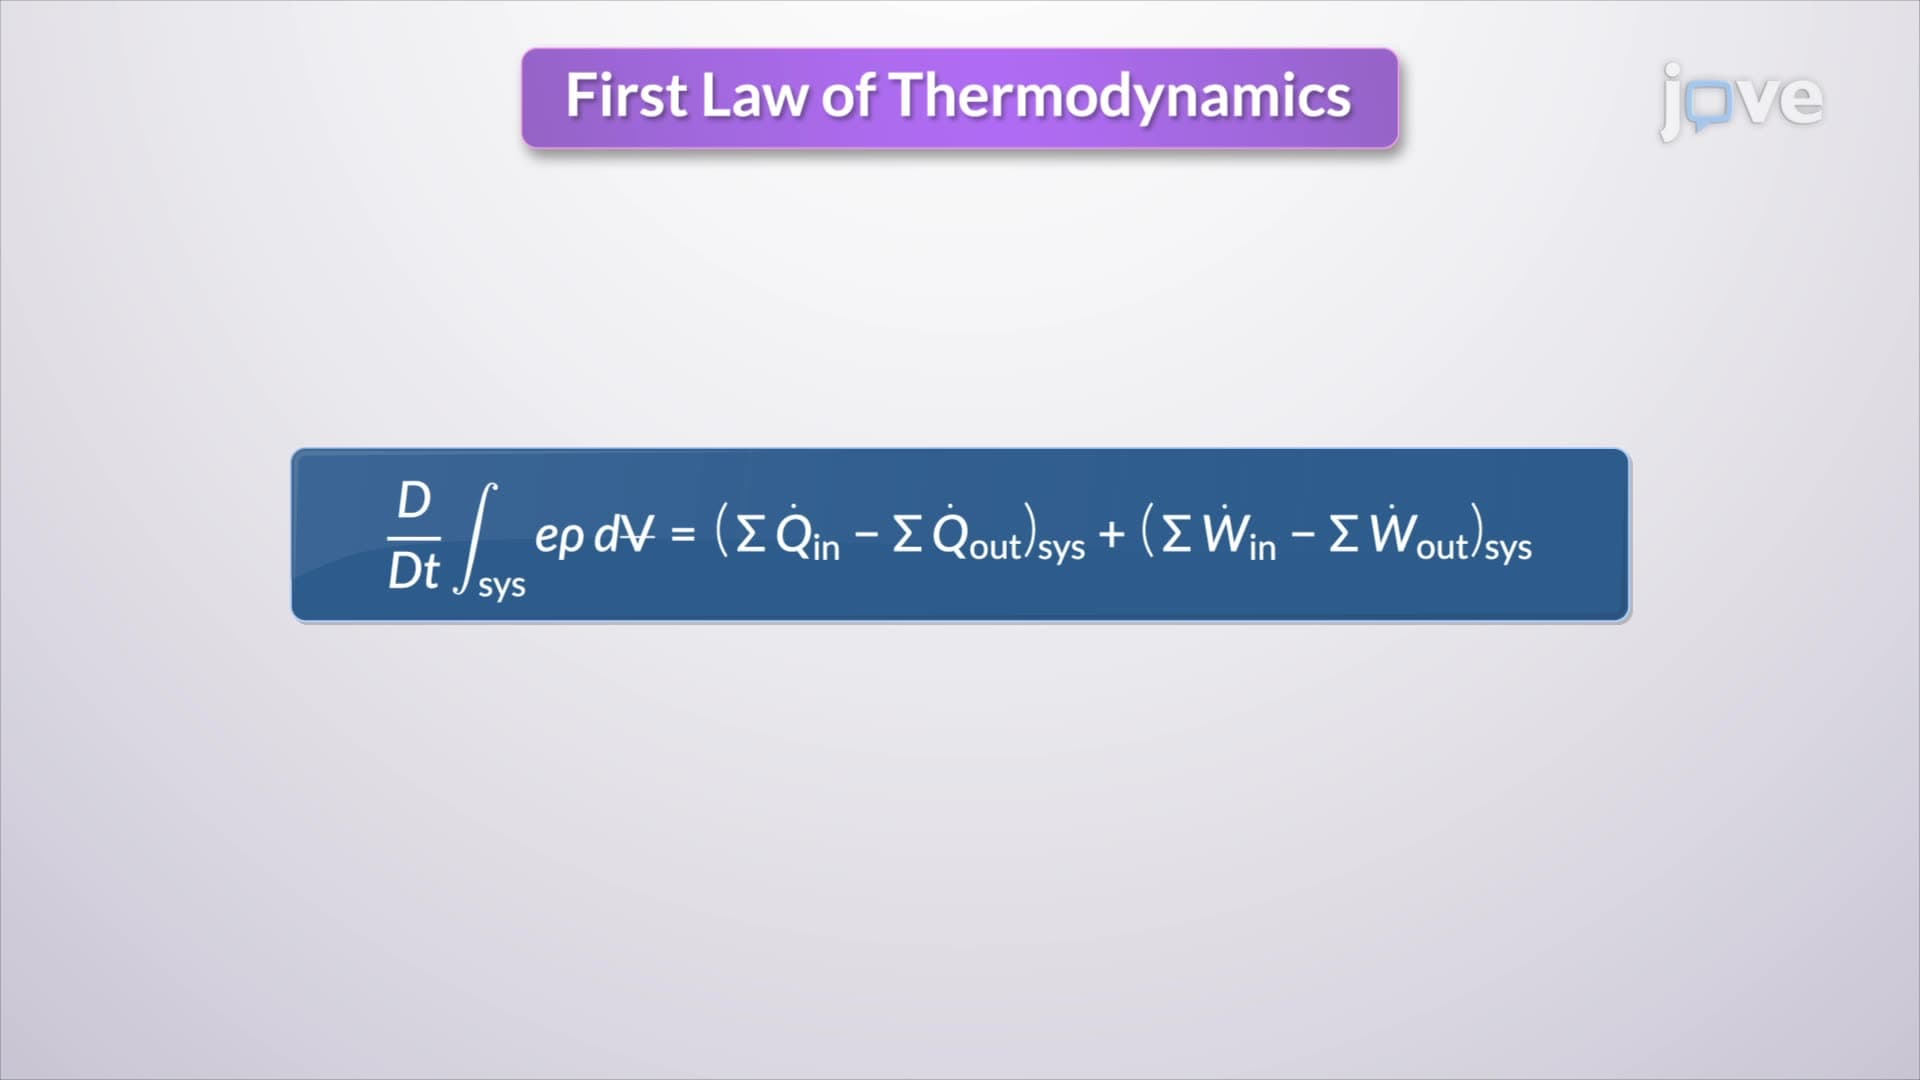
Conservation of Energy in Control Volume
For steady flow systems, the time derivative of the stored energy becomes zero since there is no energy accumulation within the control volume. This simplifies the energy equation to:
 01:27
Uniform Depth Channel Flow
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:30
Vector Functions and Motion: Problem Solving
 01:25
Maximizing the Directional Derivative