Related Experiment Video
Updated: Sep 15, 2025

Low-Cost Automated Flight Intercept Trap for the Temporal Sub-Sampling of Flying Insects Attracted to Artificial Light at Night
Published on: December 29, 2021
Barrier Lyapunov function based guidance law design for gap traversal of aerial vehicles
1Department of Aerospace Engineering, Indian Institute of Technology Bombay, Mumbai 400076, India.

Abstract:
This manuscript proposes a novel guidance design for the gap traversal of aerial vehicles. The guidance design is performed based on the barrier Lyapunov function using bearing information of the gap. The guidance law is meticulously crafted to operate in scenarios where determining gap edges relies on active vision methods, making it reliable in various real-world applications. What sets this guidance law apart from existing ones is its adherence to a nonlinear framework, refraining from the need to linearize the system dynamics. This remarkable feature allows the proposed guidance design to maintain its effectiveness even when the deviations in the heading and flight path angle are significant from their nominal values. The efficacy of the proposed guidance law is substantiated using a point mass vehicle and the quadrotor in the planar and three-dimensional scenarios. Extensive numerical simulations are conducted to validate the performance of the proposed design, considering wind gusts and Gaussian noise. The results obtained from these simulations demonstrate the efficacy of barrier Lyapunov function-based guidance for aerial vehicles in the context of gap traversal.
More Related Videos
 11:41
Evaluation of an Exclusive Spur Dike U-Turn Design with Radar-Collected Data and Simulation
Published on: February 1, 2020
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:23
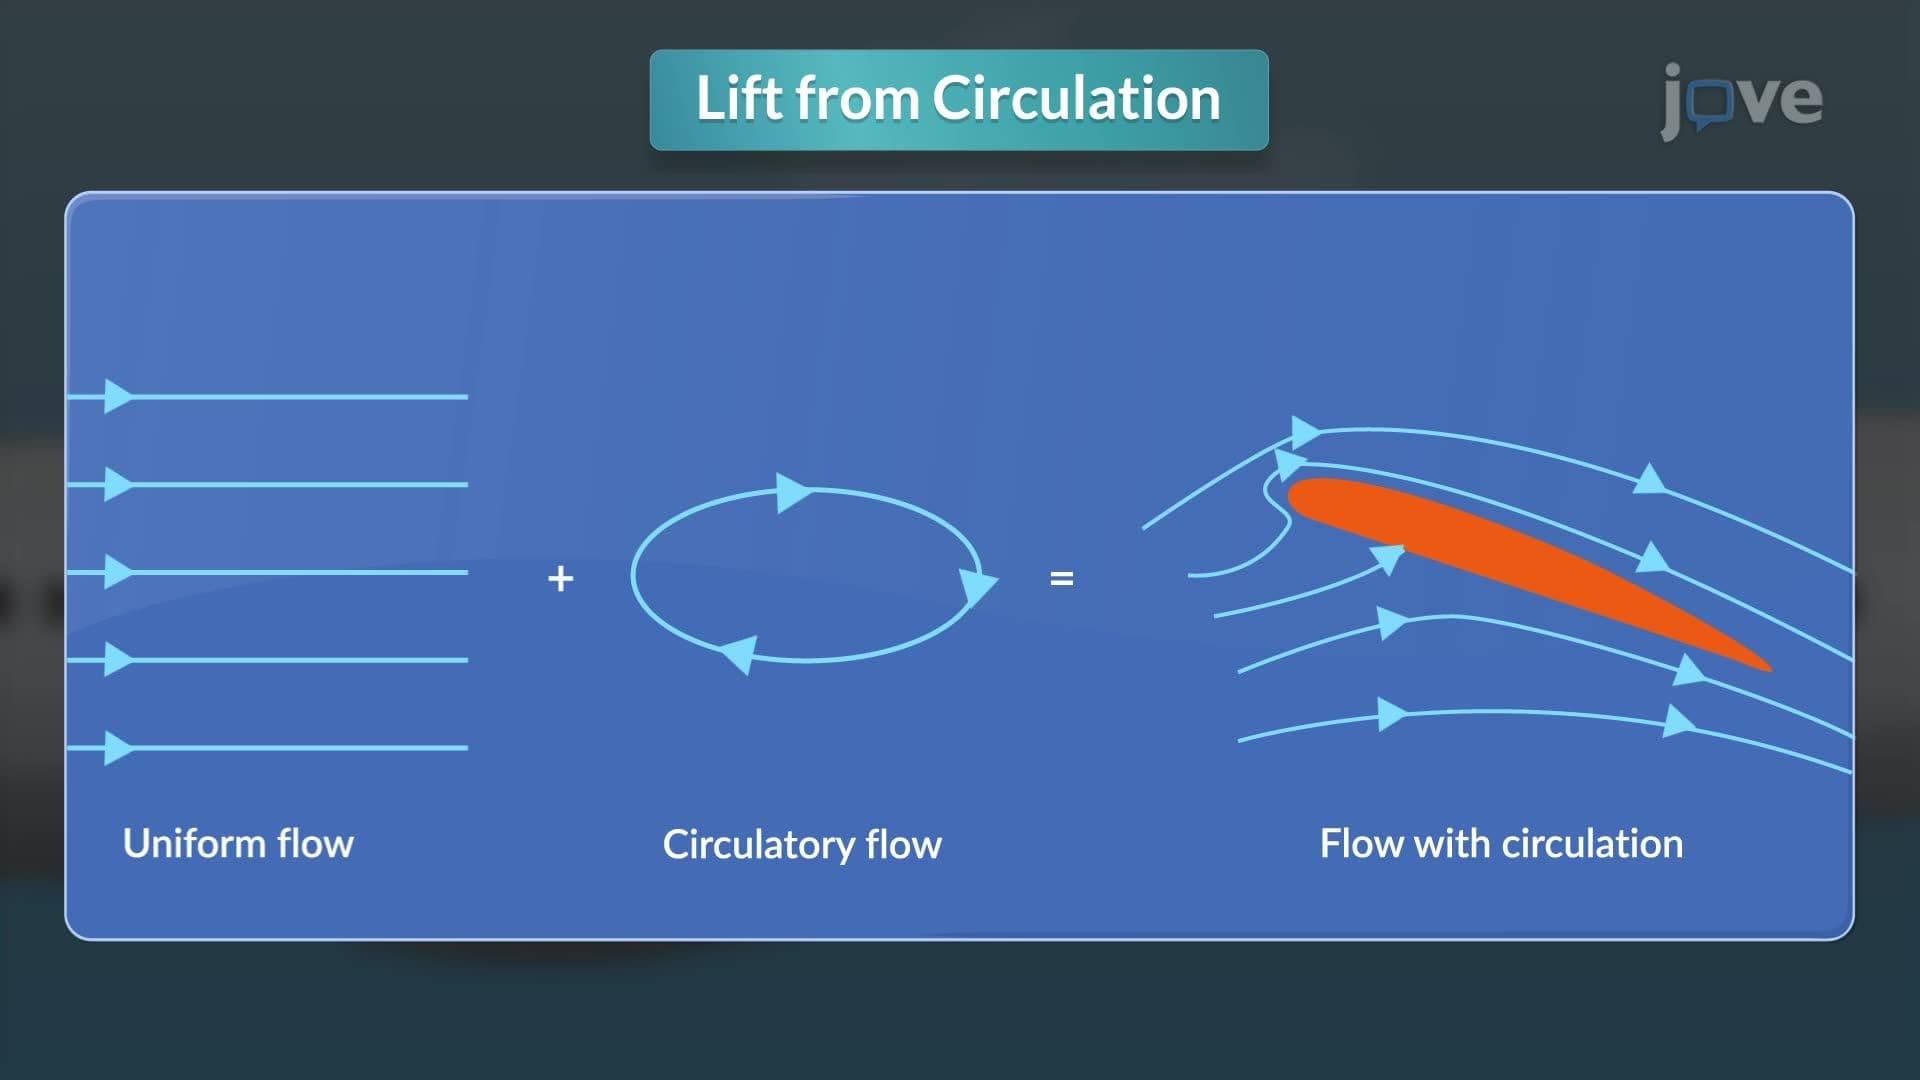
Lift
 01:16
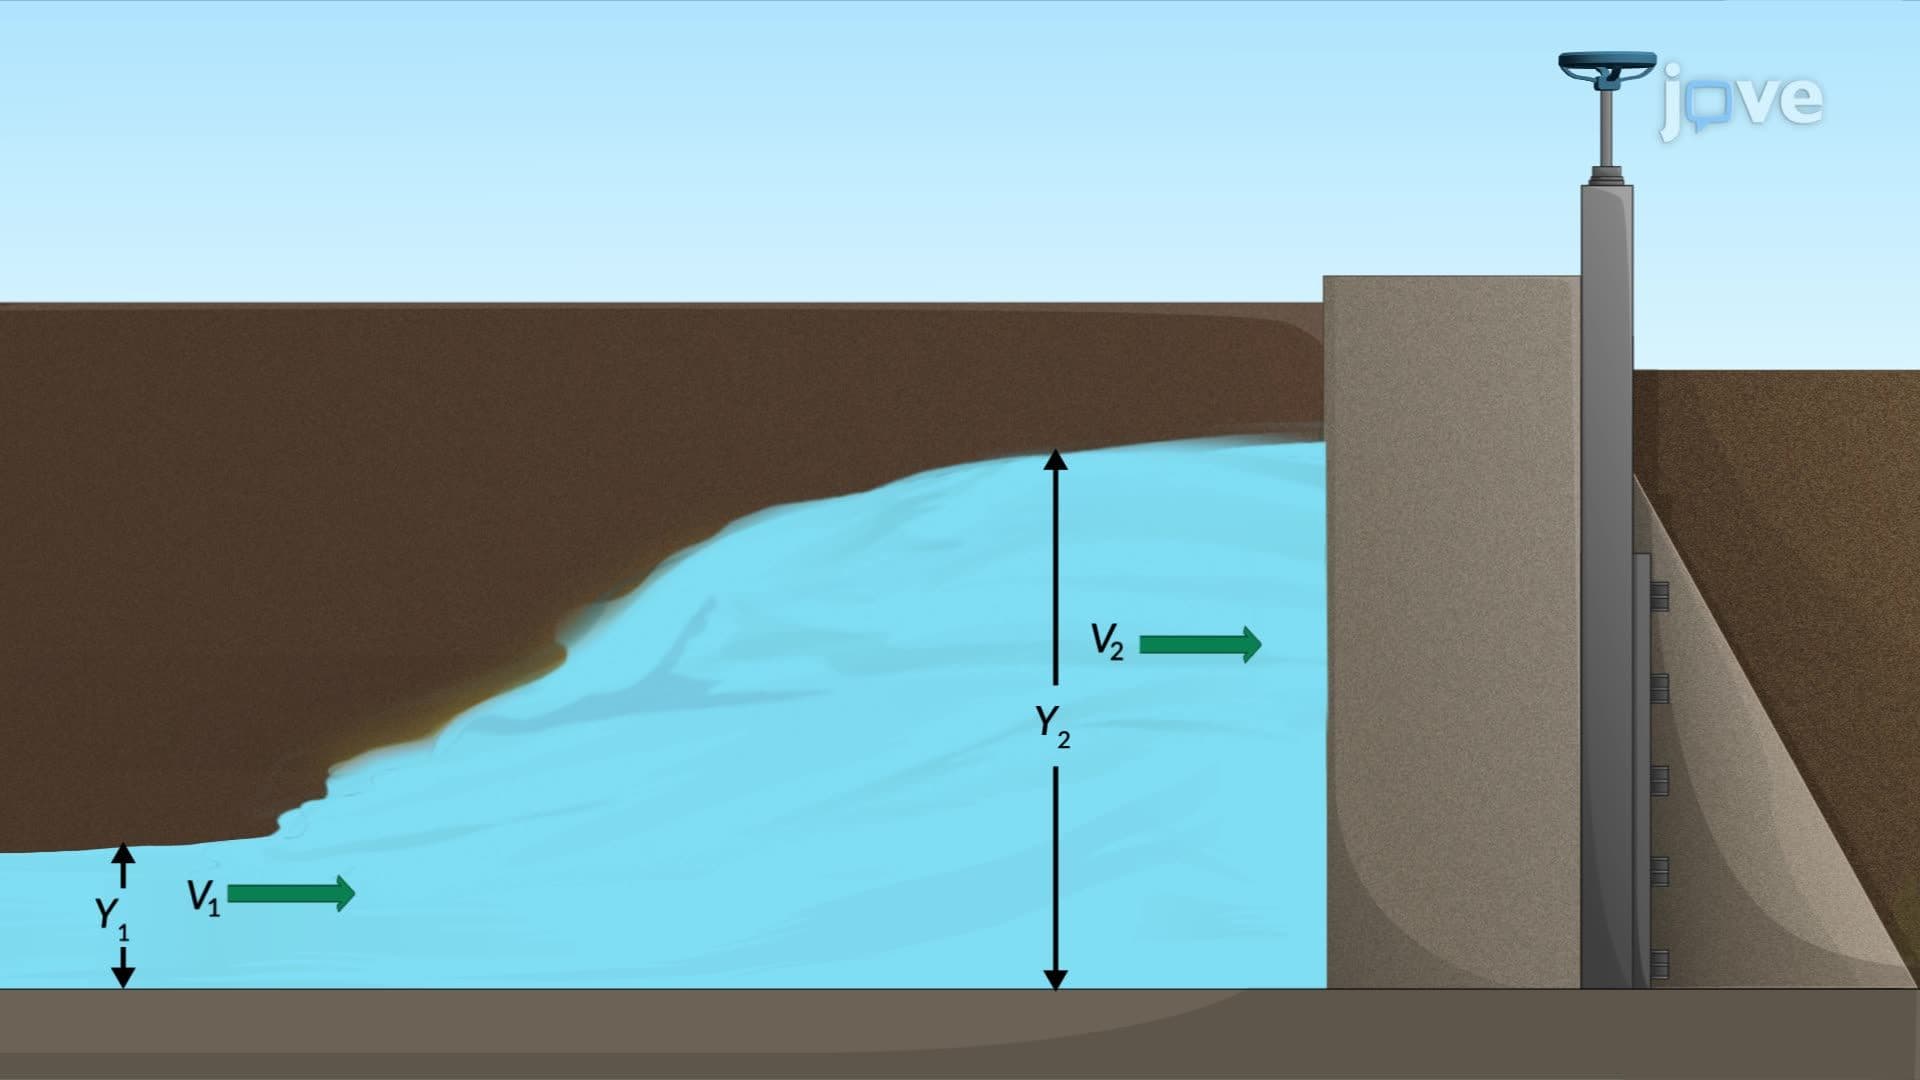
Hydraulic Jump: Problem Solving
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:09
Turbulent Flow: Problem Solving
Temperature is a key factor in CO2 solubility. In this case, the CO2 gas and the liquid are cooled to 20°C. Lower temperatures...