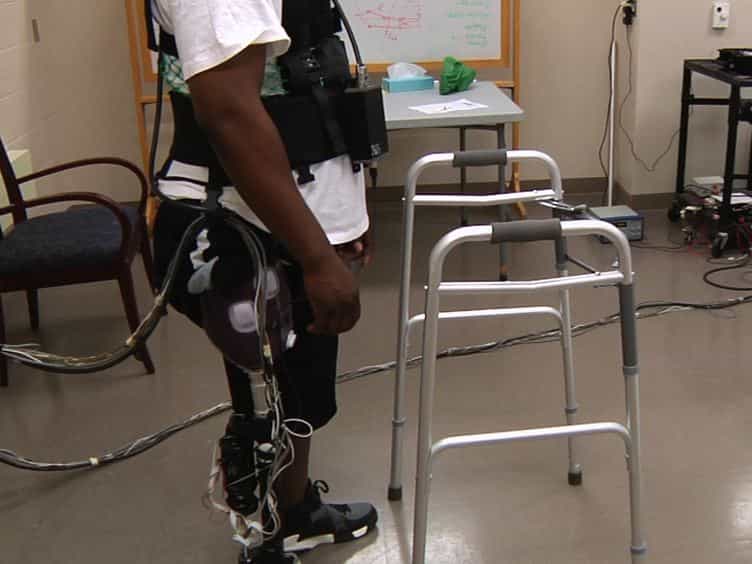
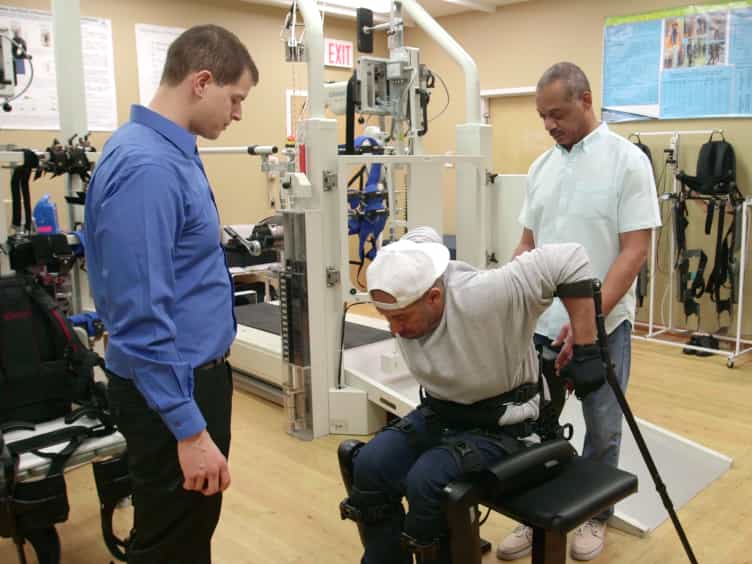
Adaptive sliding mode controller based on improved Sparrow search algorithm for tracking control of human lower limb exoskeleton
Related Experiment Video
Updated: Sep 15, 2025

A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Zhedong Xie1, Yingbo Li1, Bing Tian1
1College of Engineering and Technology, Jilin Agricultural University, Changchun130118, China.

Abstract:
This study presents an Adaptive Sliding Mode Controller enhanced by an Improved Sparrow Search Algorithm (ISSA-SMC) for accurate motion tracking of lower-limb assistive exoskeletons. By incorporating human joint torque inputs into the exoskeleton's dynamic model, ISSA-SMC achieves real-time adaptation to user variability, external disturbances, and modeling uncertainties. A softmax strategy combined with the branch and bound method efficiently optimizes controller parameters, enhancing tracking accuracy and robustness with low computational cost. Effectiveness is validated through simulations and physical experiments on a human-worn exoskeleton. Compared to conventional SMC and Adaptive Fuzzy Sliding Mode Control (AFSMC), ISSA-SMC notably reduces overshoot, steady-state error, and response time. This framework offers a practical, optimization-driven solution for wearable robotics, contributing valuable insights into intelligent rehabilitation and adaptive human-robot interaction.