Related Experiment Video
Updated: Sep 14, 2025

An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Fast calibration method for industrial robot kinematics based on motion capture system
Xiaolong Wang1, Wangqiang Jia1, Jianfu Cao1
1State Key Laboratory for Manufacturing System Engineering, Xi'an Jiaotong University, Xi'an, 710049, China.

Abstract:
This paper proposes a fast kinematics calibration method for industrial robots (IRs). Unlike existing approaches, the proposed method focuses on rapid calibration in complex and temporary IR-related scenarios. To achieve this purpose, the IR kinematic calibration is divided into four specific application situations, each using partial modules from the comprehensive calibration algorithm to streamline the process. The complete calibration method consists of two steps: first, determining the IR's joint axes through sequential joint movements and obtaining rough kinematic parameters, and second, refining these parameters using stochastic gradient descent within an optimization framework. In addition, the existing calibration methods typically ignore the positions of the intermediate links, which impacts IR obstacle avoidance. This paper proposes obstacle-avoidance auxiliary points to address this issue. Finally, simulation and experiment, conducted using a motion capture system, demonstrate that the proposed method can achieve fast, accurate calibration in complex scenarios.
Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
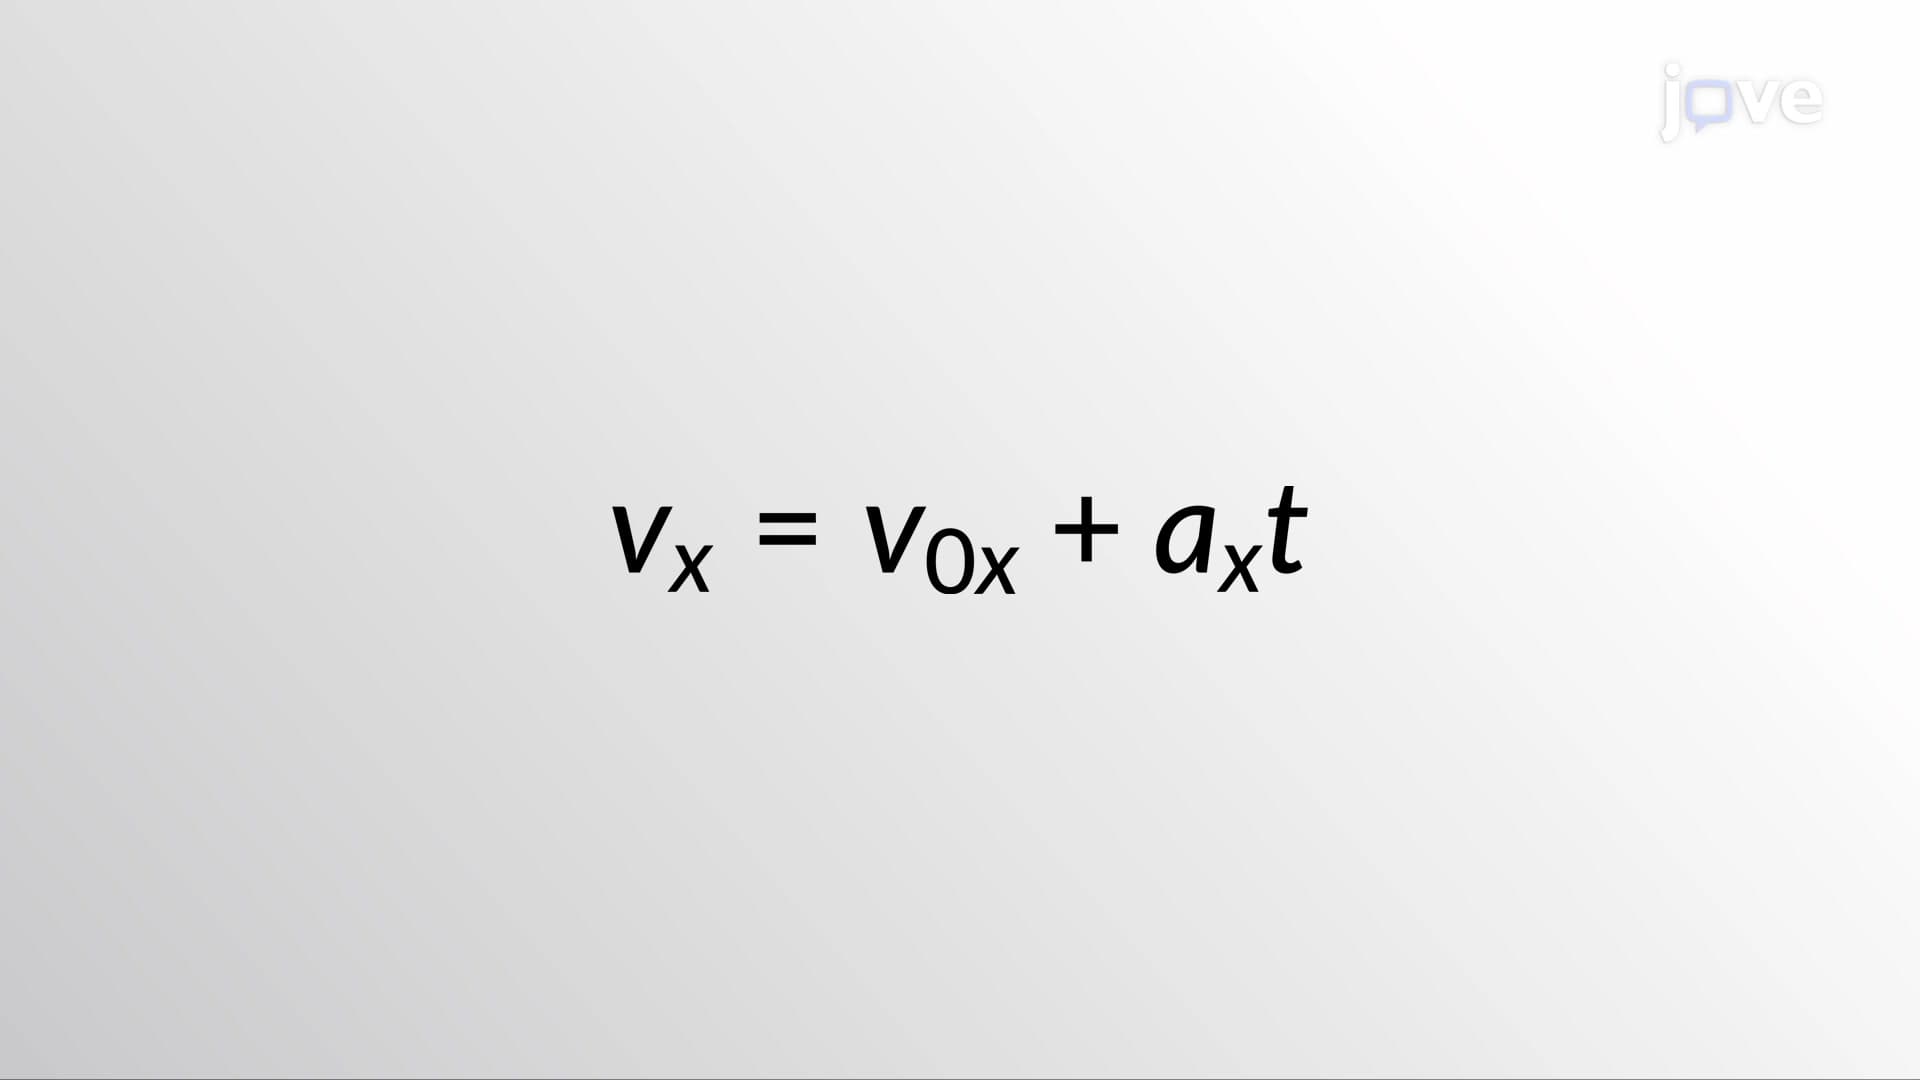 01:26
Kinematic Equations - I
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...