Related Experiment Video
Updated: Sep 13, 2025

Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
An Enhanced Dynamic Model of a Spatial Parallel Mechanism Receiving Direct Constraints from the Base at Two
Chen Cheng1, Xiaojing Yuan1, Yenan Li1
1Lab of Mechatronics, Rocket Force University of Engineering, Xi'an 710025, China.

Abstract:
In this paper, a biologically congruent parallel mechanism (PM) inspired by the masticatory system of human beings has been proposed to recreate complete chewing behaviours in three-dimensional space. The mechanism is featured by direct constraints from the base (DCFB) to its end effector at two higher kinematic pairs (HKPs), which greatly raise its topological complexity. Meanwhile, friction effects occur at HKPs and actuators, causing wear and then reducing motion accuracy. Regarding these, an inverse dynamic model that can raise the computational efficiency and the modelling fidelity is proposed, being prepared to be applied to realise accurate real-time motion and/or force control. In it, Euler parameters are employed to express the motions of the constrained end effector, and Newton-Euler's law is applied, which can conveniently incorporate friction effects at both HKPs and actuators into the dynamic model. Numerical results show that the time consumption of the model using Euler parameters is only approximately 23% of that of the model using Euler angles, and friction effects significantly increase the model's nonlinearity. Further, from the comparison between the models of the target PM and its counterpart free of DCFB, these constraints sharply raise the modelling complexity in terms of the transformation between Euler parameters and Euler angles in the end effector and the computational cost of inverse dynamics.
More Related Videos
Related Concept Videos
 01:29
Space Trusses: Problem Solving
Consider a tripod consisting of a tetrahedral space truss with a ball-and-socket joint at C. Suppose the height and lengths of the horizontal and vertical...
 01:30
Machines: Problem Solving II
 01:26
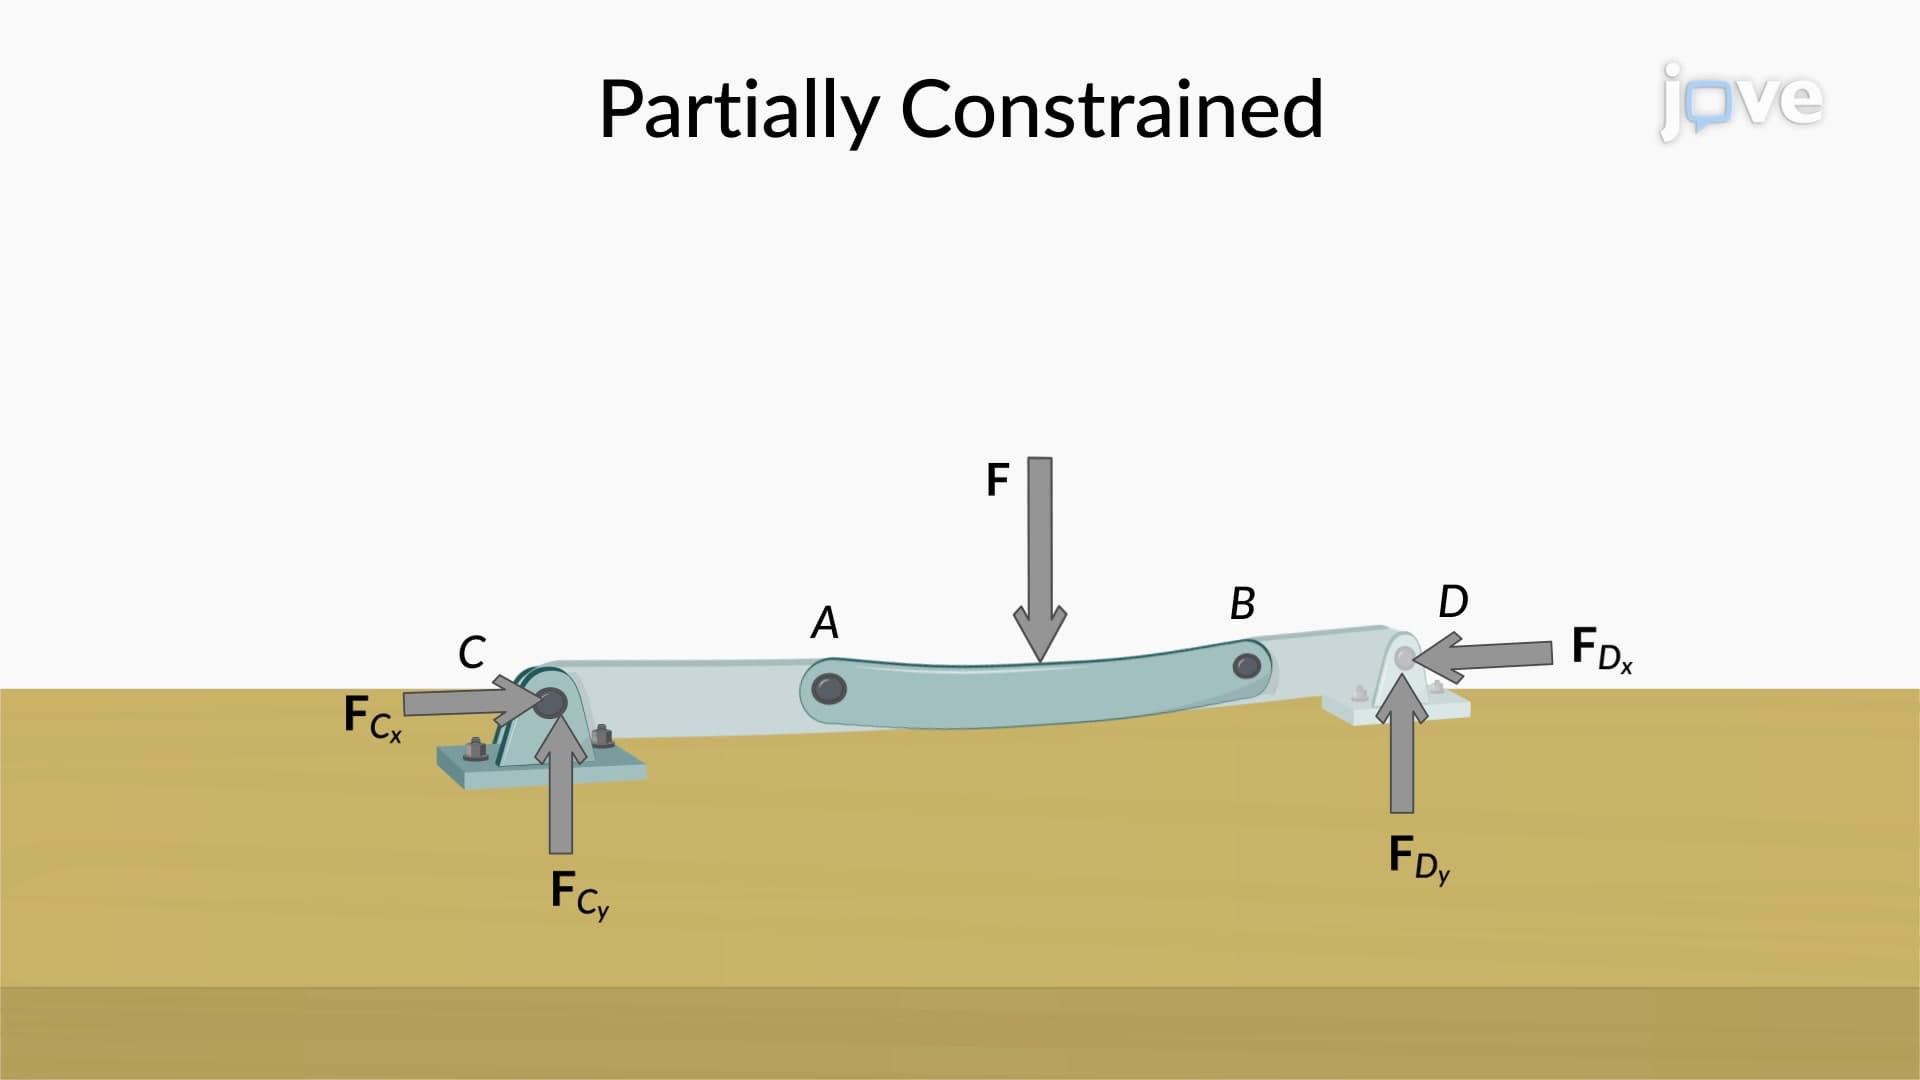
Constraints and Statical Determinacy
 01:30
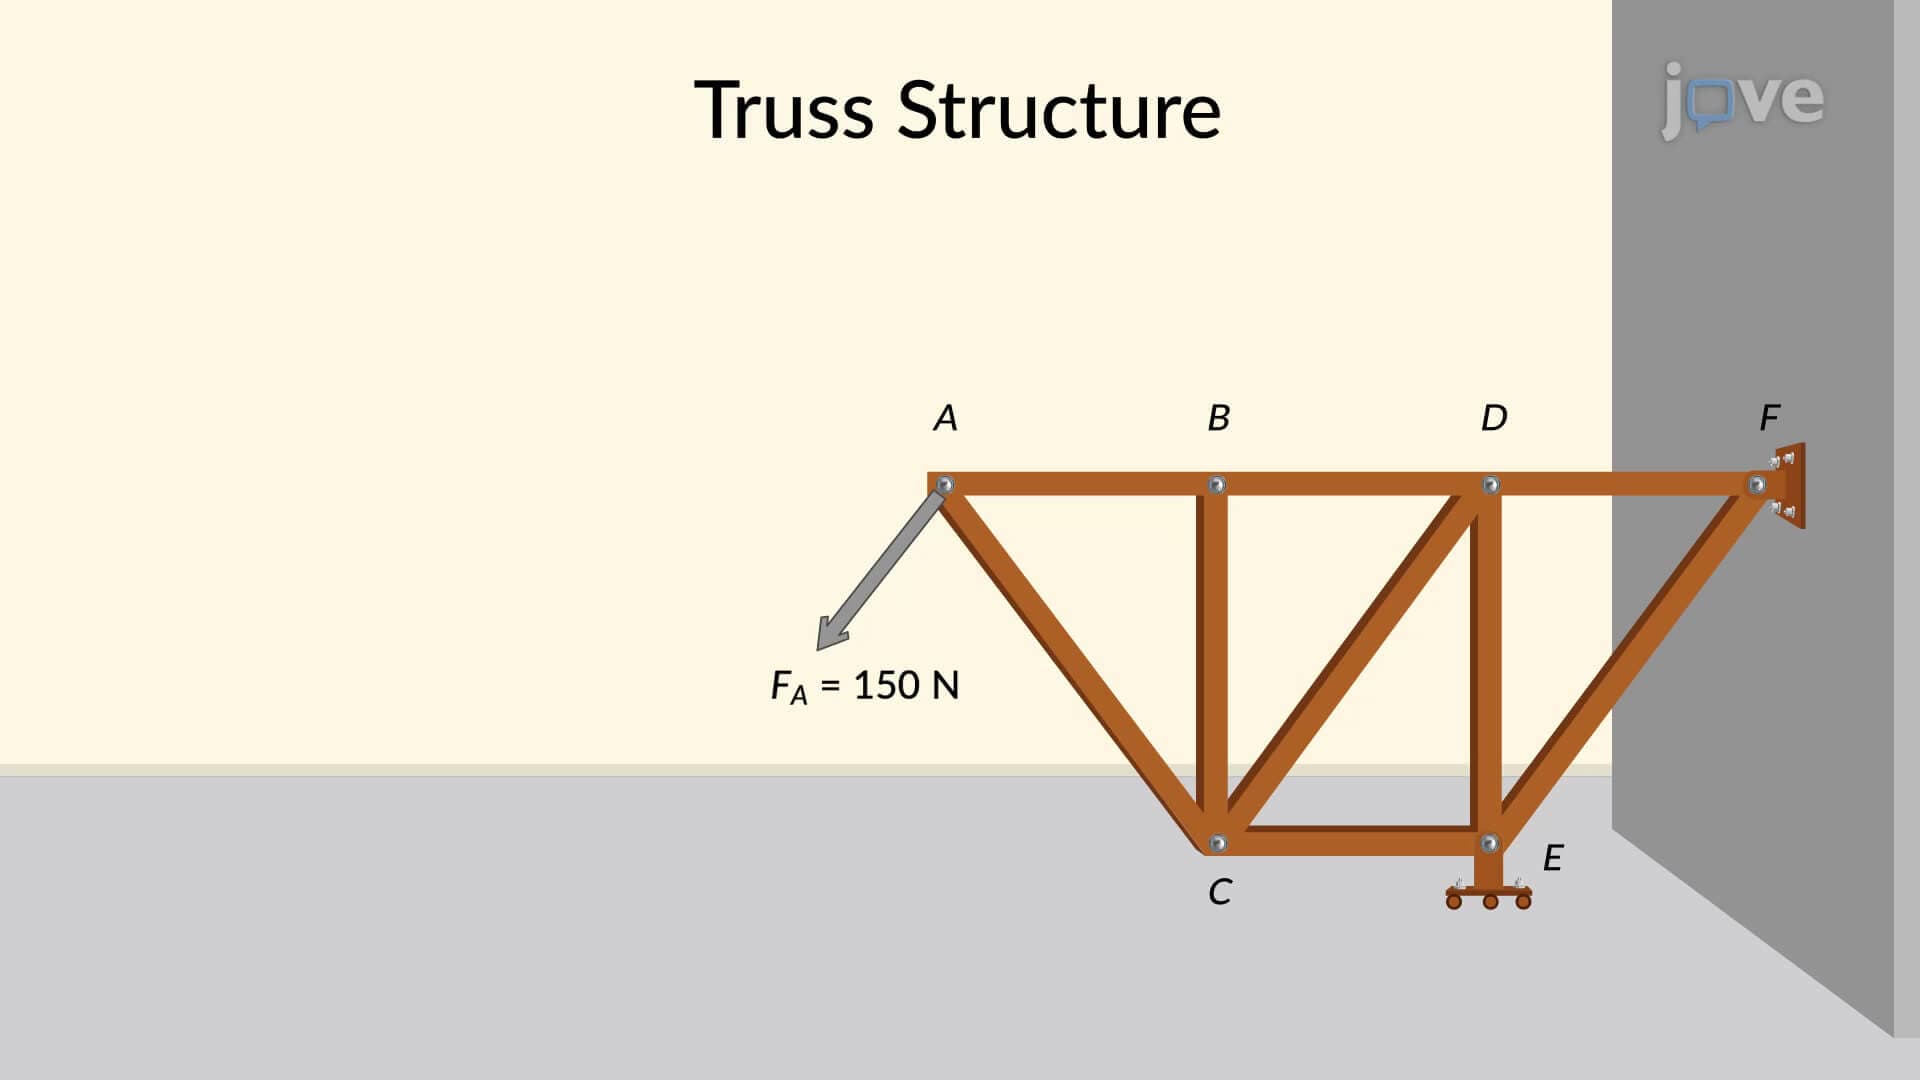
Method of Joints: Problem Solving II
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...