Related Experiment Video
Updated: Jul 2, 2026
Microfluidic Device for Recreating a Tumor Microenvironment in Vitro
Published on: November 20, 2011
Novel design of 3D printed tumbling microrobots for in vivo targeted drug delivery
Aaron C Davis1, Siting Zhang2, Adalyn Meeks2
1School of Mechanical Engineering, Purdue University, 585 Purdue Mall, West Lafayette, IN 47907, USA.

Abstract:
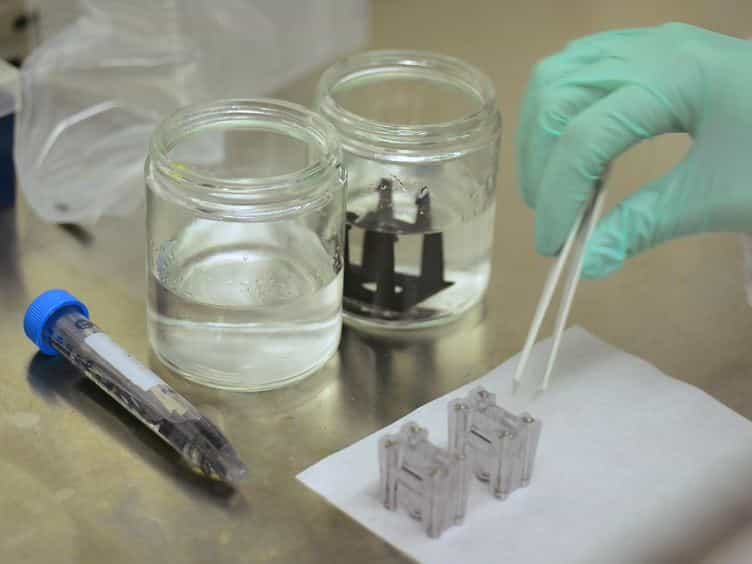
This paper presents innovative designs for 3D-printed tumbling microrobots, specifically engineered for targeted in vivo drug deliv- ery applications. The microrobot designs, created using stereolithography 3D printing technologies, incorporate permanent micro- magnets to enable actuation via a rotating magnetic field actuator system. The experimental framework encompasses a series of lo- comotion characterization tests to evaluate microrobot performance under various conditions. Testing variables include variations in microrobot geometries, actuation frequencies, and environmental conditions, such as dry and wet environments, and temperature. changes. The paper outlines designs for three drug loading methods, along with comprehensive assessments thermal drug release us- ing a focused ultrasound system, as well as biocompatibility tests. Animal model testing involves tissue phantoms and in vivo rat models, ensuring a thorough evaluation of the microrobots' performance and compatibility. The results highlight the robustness and adaptability of the proposed microrobot designs, showcasing the potential for efficient and targeted in vivo drug delivery. This novel approach addresses current limitations in existing tumbling microrobot designs and paves the way for advancements in targeted drug delivery within the large intestine.