Related Experiment Video
Updated: Sep 12, 2025
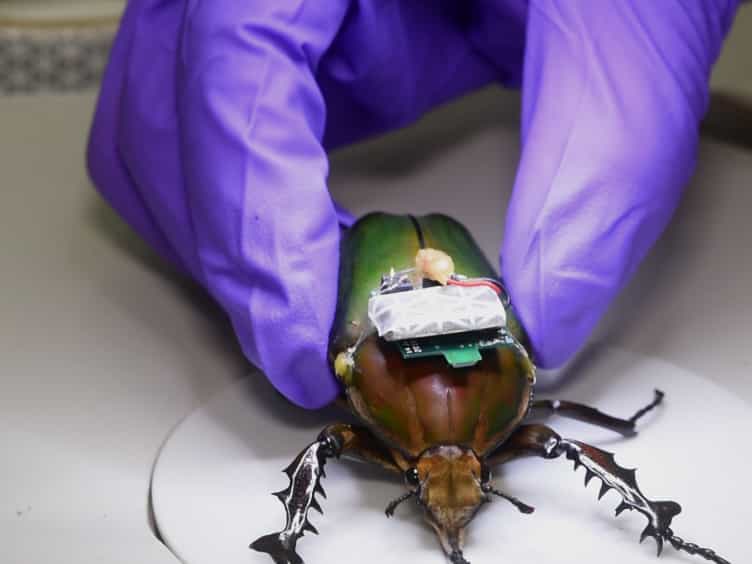

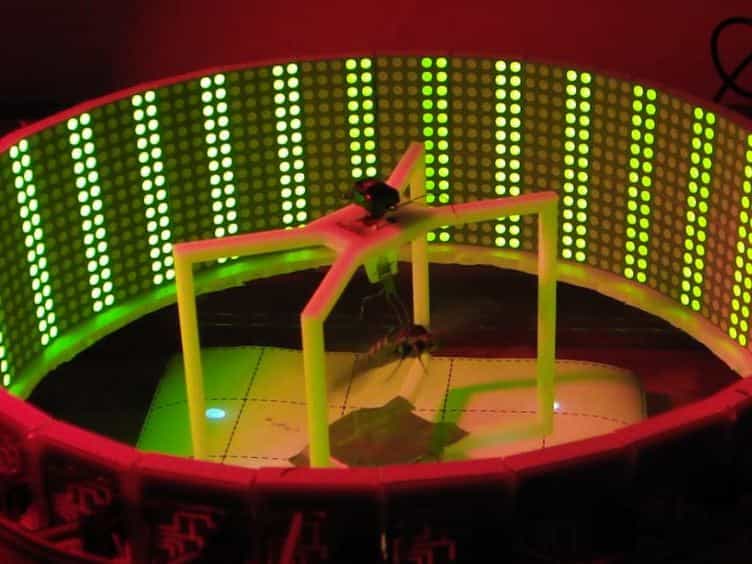
Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle Mercynorrhina torquata
Published on: September 2, 2016
Adaptive control strategies for button motor actuated insect scale flapping wing MAV mechanisms
Spoorthi Singh1,2, Meet Hitesh Jain1, Kanishk Kaushal3
1Department of Mechatronics, Manipal Institute of Technology, Manipal Academy of Higher Education, Manipal, Karnataka, 576104, India.

Abstract:
The development of Flapping Wing Micro Aerial Vehicles (FWMAVs) has gained significant attention due to their potential for energy-efficient, lightweight, and highly maneuverable flight inspired by nature. This study presents innovative designs and adaptive control strategies for insect-scale FWMAVs, utilizing compact button vibrator motors as actuators for wing flapping. These actuators offer advantages in size, weight, and power efficiency but pose challenges in achieving continuous and controlled motion due to mechanical, control, and durability constraints. The research explores multiple lever alignment configurations using simplified crank-slider mechanisms, driven by single and dual coreless DC motors powered by a 1-3.7 V DC supply. Detailed modeling in SIMSCAPE Multibody and structural movement analysis using Compmech GIM software facilitate the evaluation of variations in flapping frequency, velocity, and acceleration. Advanced control strategies, including Self-Regulatory Fractional Fuzzy Control (SRFFC) and Fractional PID (FPID), are assessed under simulated and real-world conditions to mitigate external disturbances. Additionally, an AI-based disturbance observer is implemented to enhance stability and optimize power efficiency by compensating for environmental disturbances. Performance metrics such as rise time, settling time, overshoot, and integral absolute error (IAE) demonstrate the superior efficiency and disturbance rejection capabilities of SRFFC compared to FPID. Experimental validation and real-time assessments of maneuvering capabilities, including leftward, rightward, and forward movements, further substantiate the proposed strategies. This study underscores the potential of SRFFC-driven designs and modular motor configurations to enhance the performance, control, and applicability of FWMAVs for advanced micro-aerial systems.
Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:19
PID Controller