Related Experiment Video
Updated: Sep 12, 2025
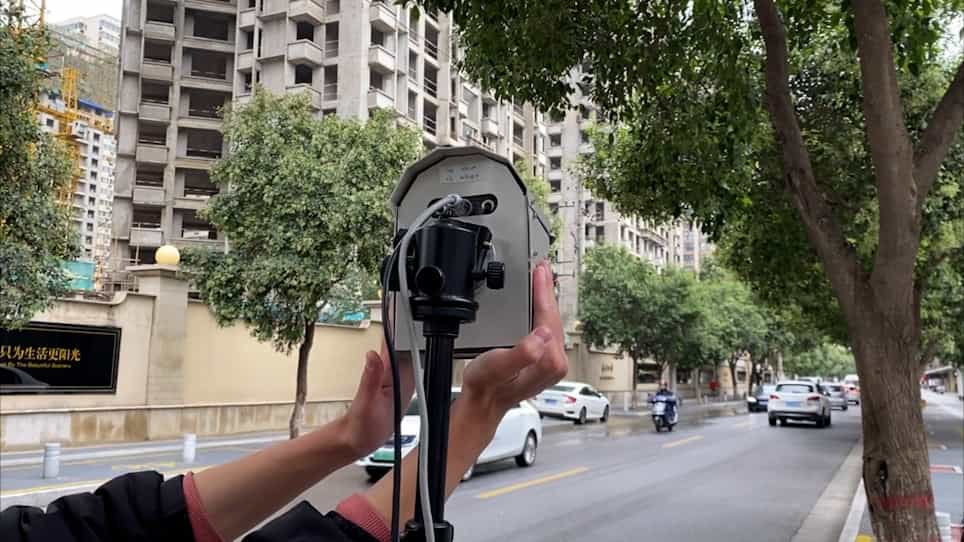

Evaluating the Effect of Roadside Parking on a Dual-Direction Urban Street
Published on: January 20, 2023
SGPLane: Efficient lane detection via sampled grid points for autonomous driving
Xuewei Tang1, Mengmeng Yang1, Kun Jiang1
1School of Vehicle and Mobility, Tsinghua University, Beijing 100084, China.

Abstract:
Lane detection is one of the critical tasks for autonomous driving. Earlier works revolved around semantic segmentation and object detection with a special program for lanes. However, most methods still suffer from unstable post-processing algorithms which leads to a gap between camera input and downstream applications. In this paper, we propose a novel detection presentation form for lanes and design a simple network without any complicated post-process. Specifically, we use sampled gird points to express lane lines and construct a network for the special lane format, which is called SGPLane. Therefore, the network learns a regression branch and a confidence branch to realize end-to-end lane detection by setting the threshold confidence value. Our model is validated on the typical dataset and real-world driving scenes. Experiments on lane detection benchmarks show that our method outperforms previous methods with accuracy score of 96.84 on Tusimple dataset with high FPS and 76.85 on our real-world dataset.

Related Concept Videos
 01:17
Design Example: Alignment of a Road Line Using GIS
 01:30
Types of Global Positioning System Surveys
 01:10
Design Example: Measuring Distance Between Two Points with Obstructions
 01:28
Field Application of Global Positioning System
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...