Related Experiment Video
Updated: Jul 28, 2026


Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
Impact of foot-transmitted vibration on gait metrics, kinematics, and dynamic stability
Flavia Marrone1, Nicole Sanna1, Elena Falchi1
1Politecnico di Milano, Dipartimento di Meccanica, Milano, Italy.

Abstract:
Transport operators face increased risks of injuries and falls while walking on a vibrating floor. No standards exist for human exposure to foot-transmitted vibration (FTV). In this study, twenty-one subjects walked on a treadmill constrained on a moving platform used to apply harmonic vibrations in four directions (mediolateral, anteroposterior, roll, and pitch) at four frequencies (0.5, 0.75, 1, and 1.5 Hz) with constant displacement (2 cm or 1°). The gait metrics, kinematic, and stability data were extracted in correspondence with the onset/offset of platform movement and when the steady-state of FTV was reached. Mediolateral vibration at the highest frequency was the most impactful condition, leading to the adoption of compensatory strategies to stabilize the center of mass closer to the floor and enlarge the base of support. These findings suggest that, from a normative perspective, a specific weighting curve is needed to assess human response to FTV while walking, since it varies as a function of vibration frequency and direction.
More Related Videos
 06:35
Using Gold-standard Gait Analysis Methods to Assess Experience Effects on Lower-limb Mechanics During Moderate High-heeled Jogging and Running
Published on: September 14, 2017
 06:21
Postural Organization of Gait Initiation for Biomechanical Analysis Using Force Platform Recordings
Published on: July 26, 2022
Related Concept Videos
 01:05
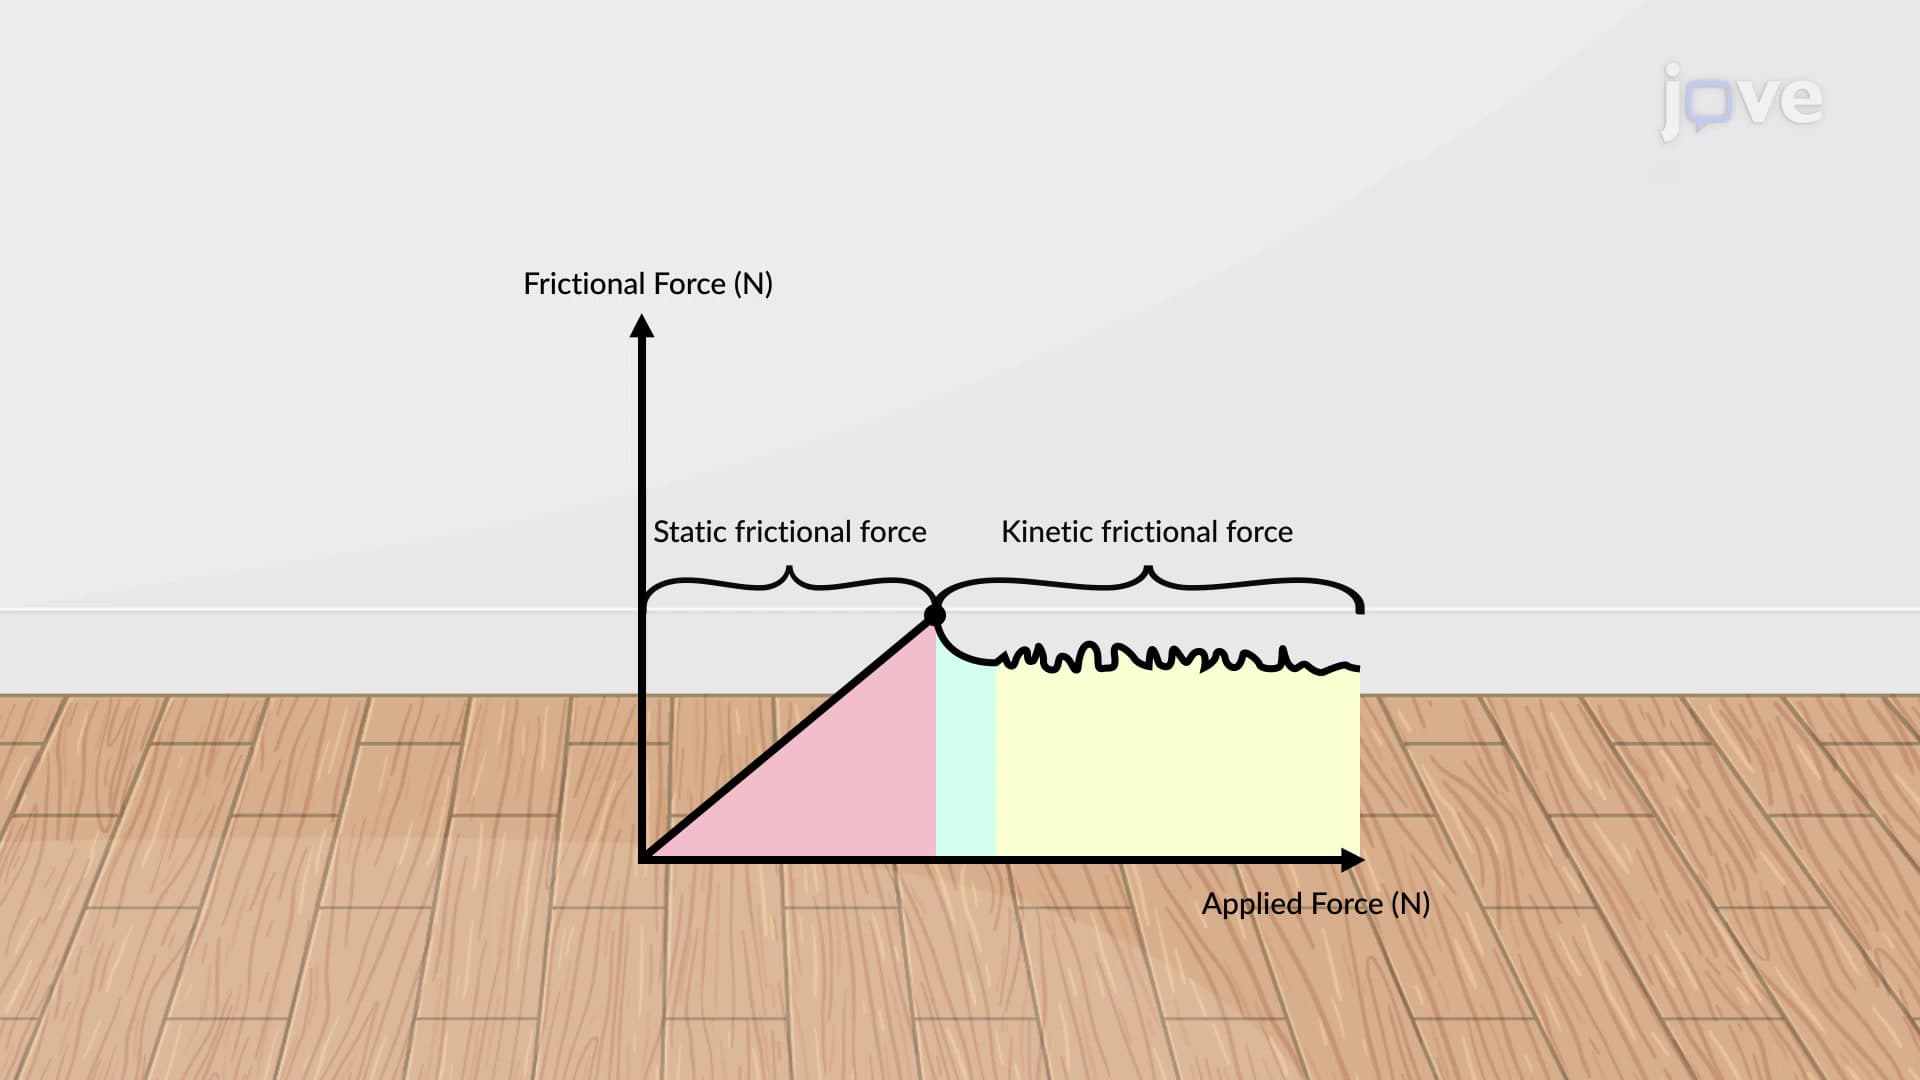
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:20
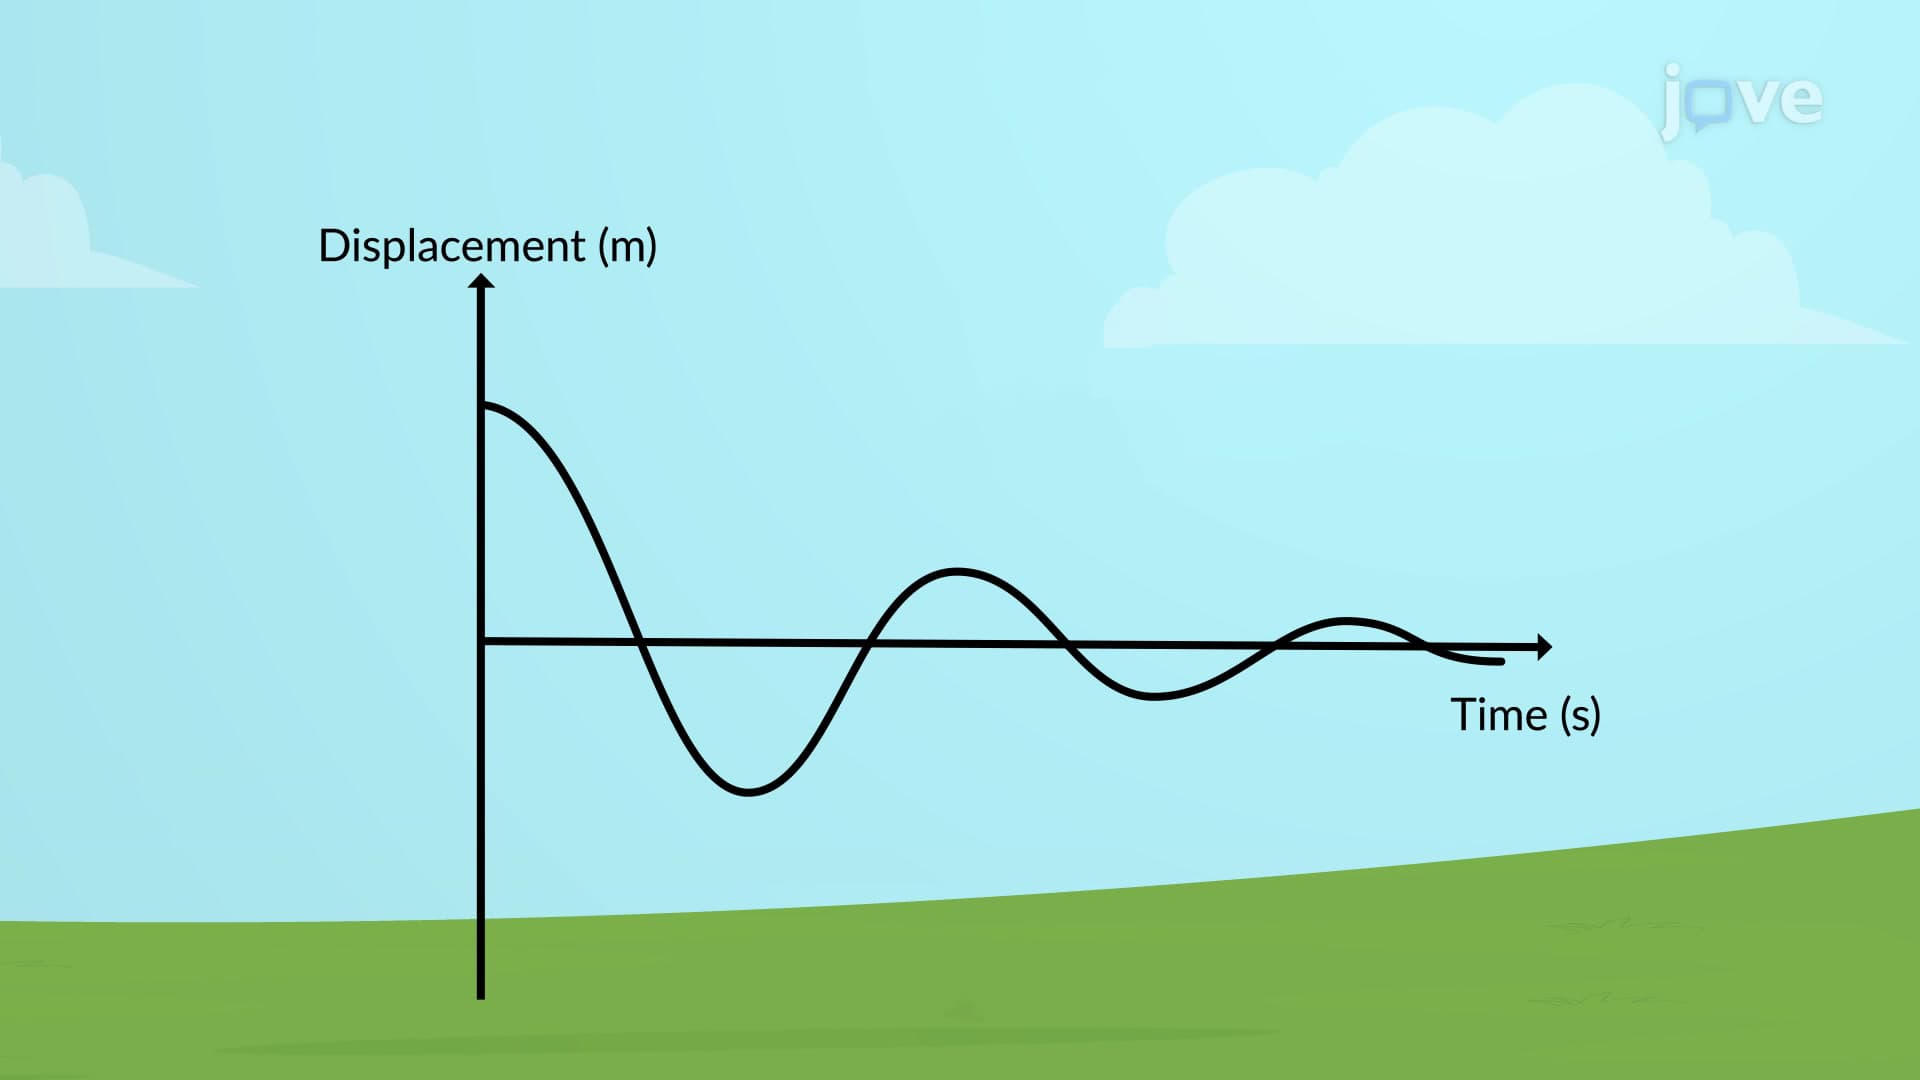
Types of Damping
 01:17
Friction: Problem Solving
Initially, a visual representation of the...
 01:14
Stability of structures
 01:28
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:19
Root-Locus Method
This system can be represented by a block diagram,...