Related Experiment Video
Updated: Sep 11, 2025
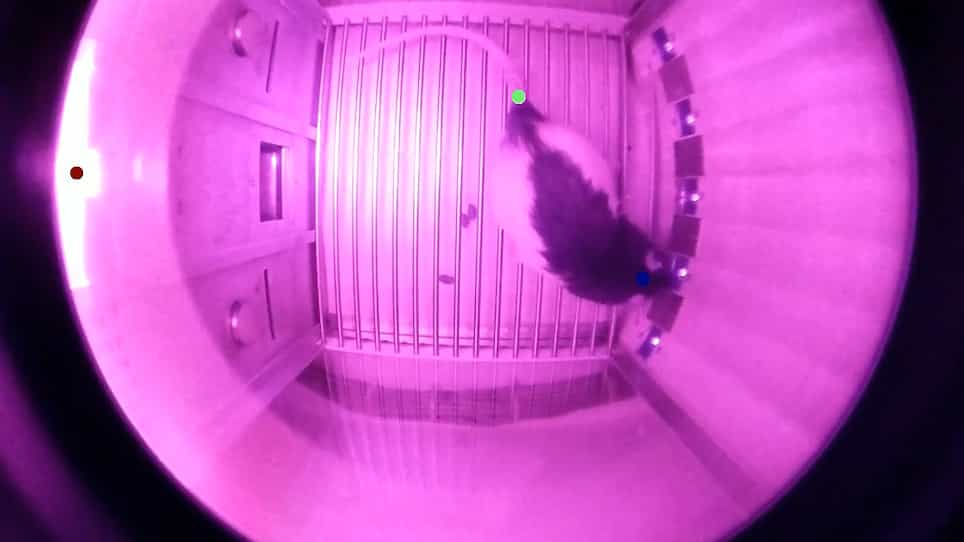
Tracking Rats in Operant Conditioning Chambers Using a Versatile Homemade Video Camera and DeepLabCut
Published on: June 15, 2020
Road-Adaptive Precise Path Tracking Based on Reinforcement Learning Method
1School of Information Science and Engineering, Fudan University, Shanghai 200433, China.

Abstract:
This paper proposes a speed-adaptive autonomous driving path-tracking framework based on the soft actor-critic (SAC) and pure pursuit (PP) methods, named the SACPP controller. The framework first analyzes the obstacles around the vehicle and plans an obstacle-free reference path with the minimum curvature using the hybrid A* algorithm. Next, based on the generated reference path, the current state of the vehicle, and the vehicle motor energy efficiency diagram, the optimal speed is calculated in real time, and the vehicle dynamics preview point at the future moment-specifically, the look-ahead distance-is predicted. This process relies on the learning of the SAC network structure. Finally, PP is used to generate the front wheel angle control value by combining the current speed and the predicted preview point. In the second layer, we carefully designed the evaluation function in the tracking process based on the uncertainties and performance requirements that may occur during vehicle driving. This design ensures that the autonomous vehicle can not only quickly and accurately track the path, but also effectively avoid surrounding obstacles, while keeping the motor running in the high-efficiency range, thereby reducing energy loss. In addition, since the entire framework uses a lightweight network structure and a geometry-based method to generate the front wheel angle, the computational load is significantly reduced, and computing resources are saved. The actual running results on the i7 CPU show that the control cycle of the control framework exceeds 100 Hz.
Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:23
Reinforcement
Positive reinforcement occurs when a behavior is followed by the presentation of a rewarding stimulus, increasing the frequency of that behavior. For example:
 01:12
Observational Learning
 01:24
Reinforcement Schedules
Once a behavior is learned,...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...