Universal response inequalities beyond steady states via trajectory information geometry
Related Experiment Video
Updated: Sep 11, 2025

Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
1University of North Carolina-Chapel Hill, Department of Chemistry, North Carolina.

Abstract:
Fluctuation-dissipation relations elucidate the response of near-equilibrium systems to environmental changes, with recent advances extending response theory to nonequilibrium steady states. However, a general response theory for systems evolving far from steady states has remained elusive. This letter presents a complete trajectory information geometric framework that generalizes response theory for nonstationary Markov processes. By constructing the full trajectory probability manifold and identifying a globally orthogonal coordinate system defined by transition rates, we derive a diagonal Fisher information metric that enables explicit calculations in this high-dimensional space. From the local metric structure, we obtain a Cramér-Rao-type inequality that bounds the linear response of arbitrary nonstationary observables. Furthermore, by analyzing the global geometry of this manifold, we derive a universal nonperturbative (nonlinear) response inequality in terms of geodesic length. This geometric framework reveals deep connections between dynamical activity, observable variance, and system sensitivity, and it encompasses or anticipates several recent results as special cases. Our approach offers new design principles for responsive behaviors in far-from-equilibrium systems.
More Related Videos
Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:21
Equations of Motion: Rectangular Coordinates and Cylindrical Coordinates
When a particle moves relative to an inertial frame, the equations of motion can be expressed using rectangular components. If the motion is confined to the x-y plane, the equations having the x and y coordinates only can be used to simplify the mathematical representation.
However, when particles...
 01:27
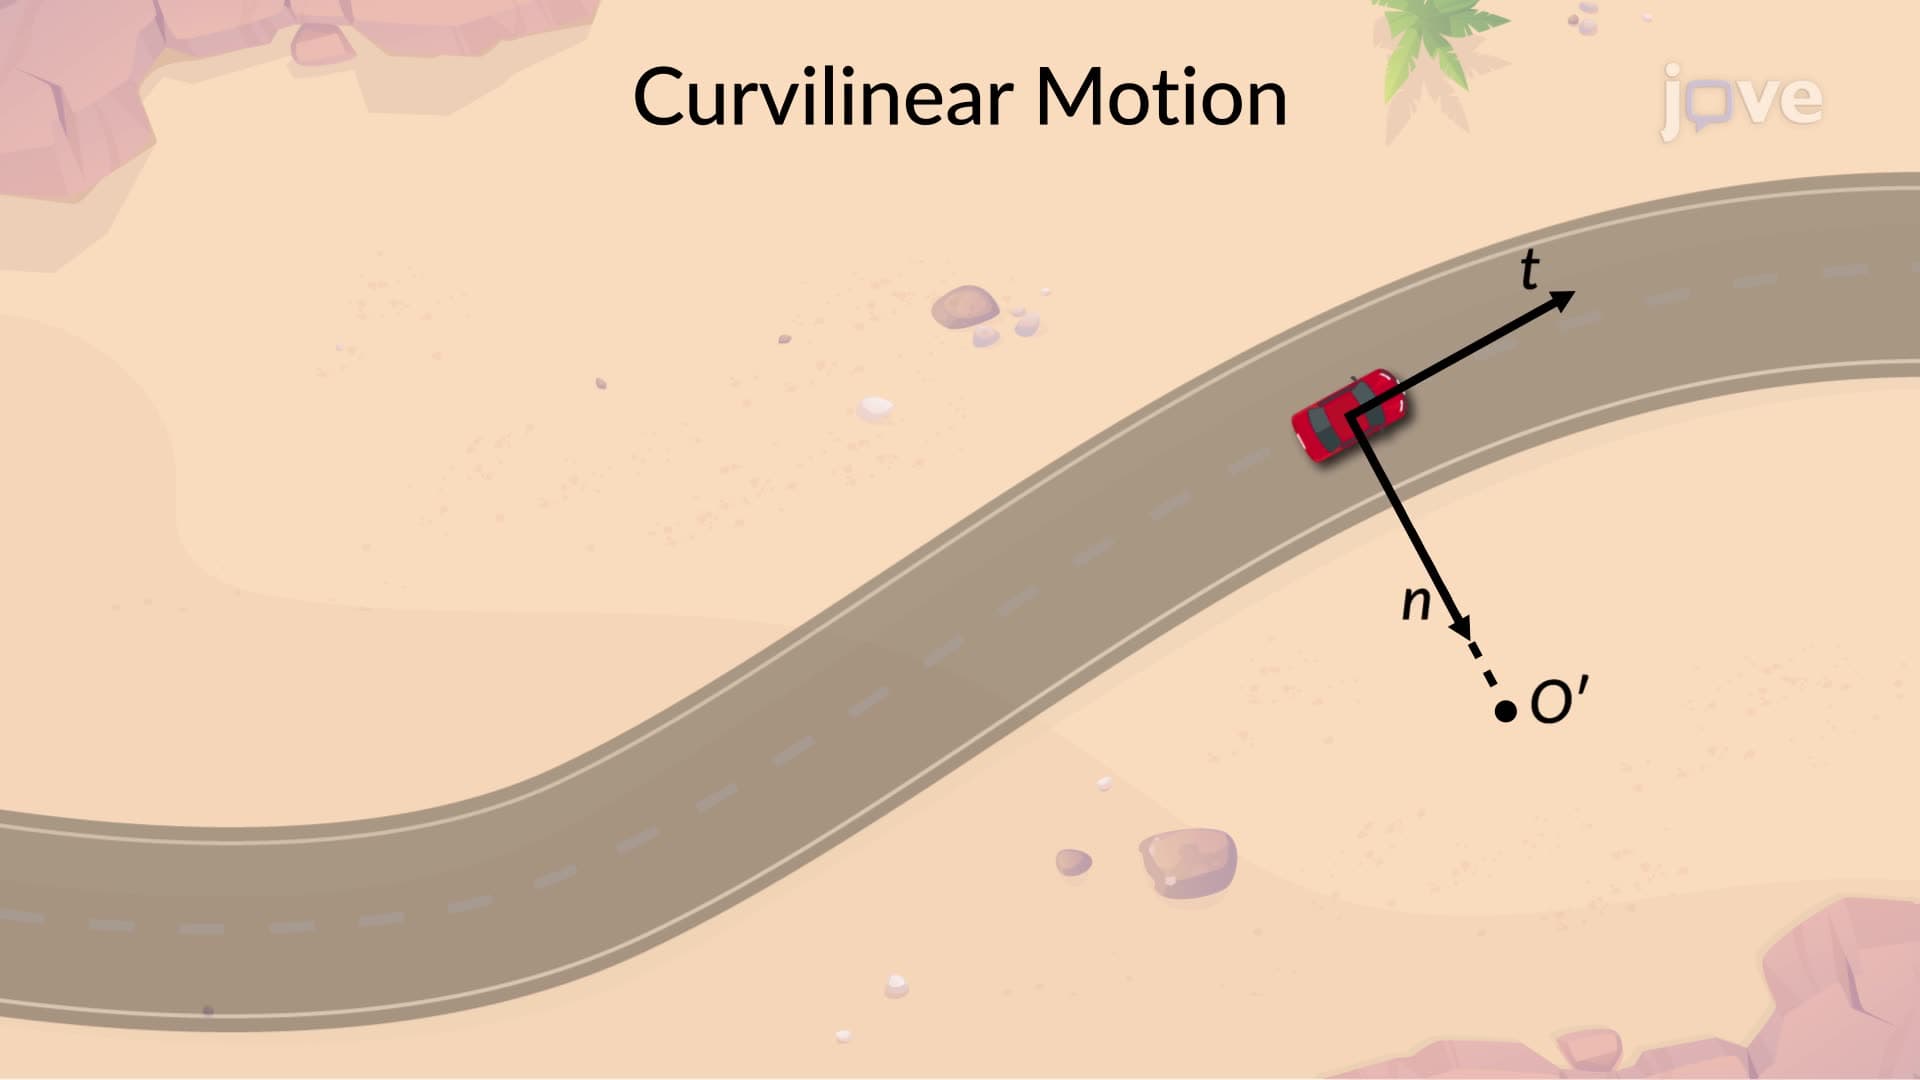
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 02:57
Coordination Number and Geometry