Toward autonomous robotic gastroscopy with a novel interventional keypoint and polyp detection system
Related Experiment Video
Updated: Sep 10, 2025
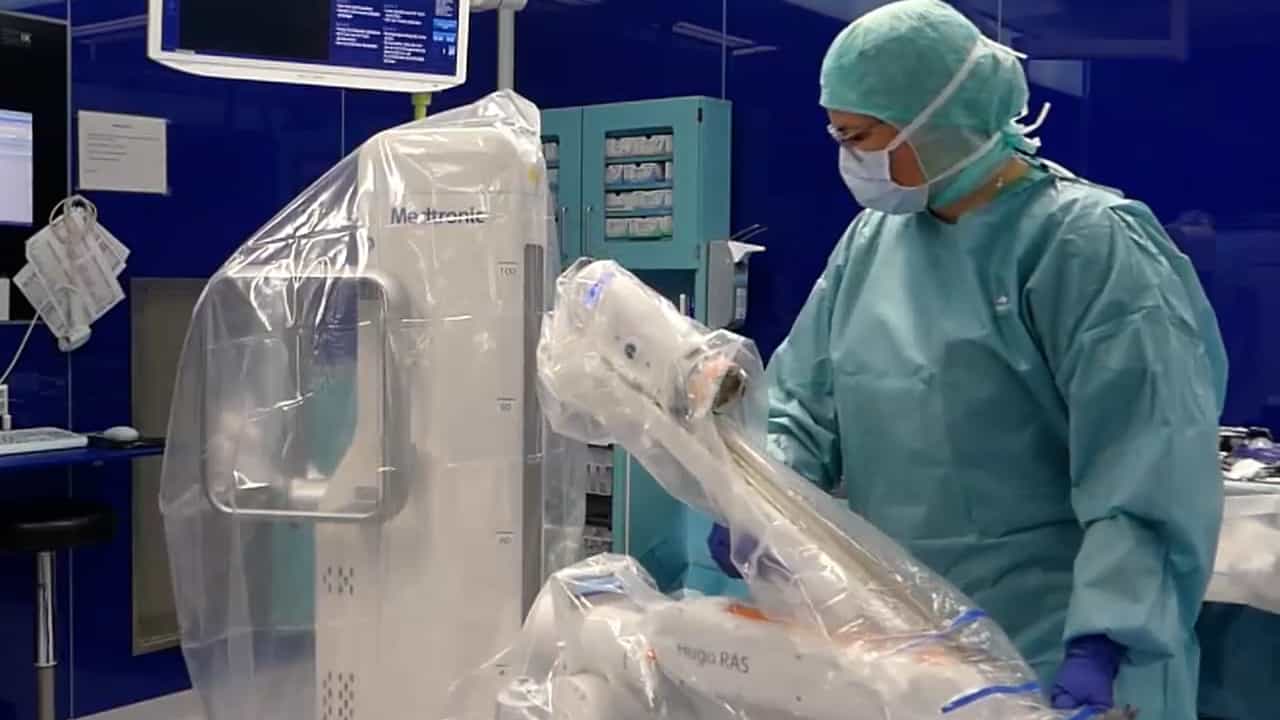
Robotics in Surgery: A Modular Robotic Platform Driven Gastric Wedge Resection
Published on: February 7, 2025
Yuying Liu1, Guang Feng1, Qi He1
1Key Laboratory of Mechanism Theory and Equipment Design of Ministry of Education, Tianjin University, Tianjin, China.

Background And Objective:
Gastric cancer has high incidence and mortality rates globally. Gastroscopy is widely considered the gold standard for screening gastric diseases. However, accurate and stable identification of gastric diseases under endoscopy remains challenging due to its heavy reliance on the experience and operational skills of the endoscopist. The development of robotic gastroscopes offers an effective solution for screening upper gastrointestinal diseases.
Methods:
In this paper, we propose an innovative deep learning-based framework for autonomous robotic gastroscopy, integrating a combined anchor point (intervention keypoint) and polyp detection system (named KP-YOLO). This system enables the robotic gastroscope to operate autonomously and intelligently, facilitating both intervention navigation and diagnostic tasks. To support this framework, we have created and made publicly available two fully annotated datasets: a real gastroscopy dataset containing 3,454 images and a high-fidelity upper gastrointestinal (UGI) phantom dataset with 2,144 images.
Results:
The detection model trained on the real gastroscopy dataset achieved a precision (P) of 0.987 and a mean average precision (mAP) of 0.985 for intervention keypoints. For polyp detection, the model attained a P of 0.994 and an mAP of 0.964. Experimental validation was conducted utilizing a high-fidelity UGI phantom equipped with a robotic arm, motion control module, and Olympus endoscopic system.
Conclusion:
Guided by the proposed detection system, the robotic gastroscope successfully performs autonomous intervention navigation and intelligent polyp detection on the UGI phantom. This work demonstrates the potential of leveraging artificial intelligence to enhance the autonomy and intelligence of robotic gastroscopy, paving the way for its future clinical application.
Related Concept Videos
 01:28
Endoscopic Procedures III: Video Capsule Endoscopy
 01:26
Endoscopic Procedures IV: Sigmoidoscopy and Laproscopy
Sigmoidoscopy
Sigmoidoscopy is a diagnostic procedure that uses a flexible sigmoidoscope equipped with a light source and camera to examine the rectum and sigmoid colon. The procedure involves inserting the tube through the anus...
 01:29
Endoscopic Procedures I: Esophagogastroduodenoscopy
During an EGD, the endoscope can be used to:
 01:26
Imaging Studies III: Gastrointestinal Motility Studies and Virtual Colonoscopy
Radionuclide Testing
Radionuclide testing is a sophisticated medical technique for assessing gastrointestinal motility. It focuses on gastric emptying and colonic transit time. Radioactive markers track the movement of food through the digestive system, providing insights into gastrointestinal disorders.
In gastric emptying studies, a meal's liquid and...
 01:25
Endoscopic Procedures II: Colonoscopy
 01:26
Endoscopic Procedures V: ERCP
Patient...