Related Experiment Video
Updated: Sep 10, 2025
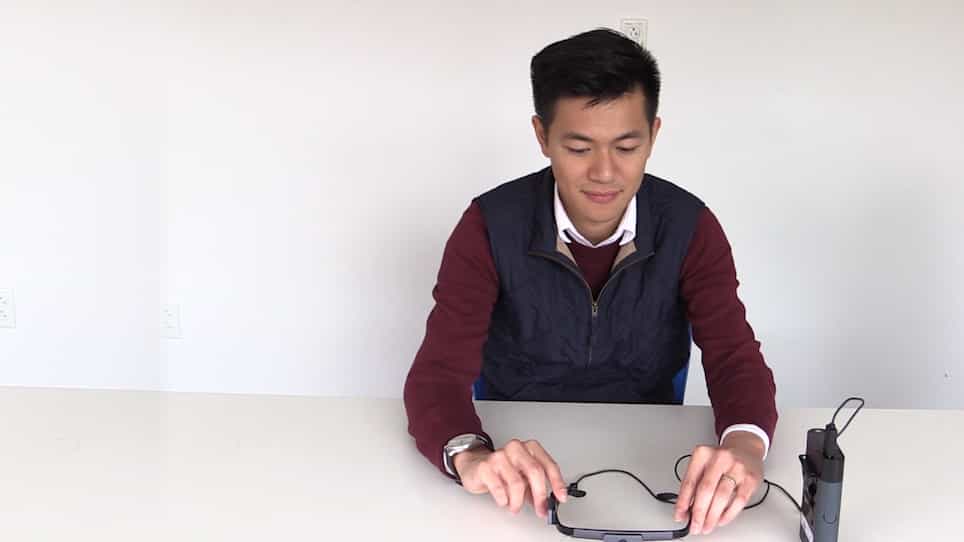

A Methodology for Capturing Joint Visual Attention Using Mobile Eye-Trackers
Published on: January 18, 2020
Satellite Pose Set Estimation by Uncertainty-Guided Conformal Keypoint Detection

Abstract:
Satellite pose estimation constitutes a critical technology in the aerospace tasks. The tradeoff between accuracy and efficiency becomes paramount for successful mission execution, due to the limited computational resources of on-board systems. Existing methods predominantly provide single-point estimations, which fall short of fulfilling the uncertainty quantification requirements demanded by safety-critical space operations. To address these problems, we first propose uncertainty-guided conformal keypoint detection to predict keypoint inductive conformal prediction (IndCP) set and then design a uncertainty propagation strategy to obtain pose uncertainty set. Specifically, we build our method upon a transformer-based keypoint predictor, which directly outputs uncertainty-guided keypoints. We first propose a nonconformal function to generate keypoint IndCP set to cover the ground-truth keypoint with a certain probability. We then apply Monte Carlo to sample within the keypoint IndCP set and estimate the poses by solving the perspective-n-point (PnP) problem. The top-n poses with the smallest conformal reprojection error are used to construct a convex hull, which are defined as the pose uncertainty set. Furthermore, we take the mean of the top-n poses as the average pose. Experiments on the Spacecraft PosE Estimation challenge Dataset (SPEED) and LineMOD Occlusion (LMO) dataset show that not only the average pose demonstrates higher accuracy but also the pose uncertainty sets can cover the true pose with the certain probability.

Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Design Example: Identifying the Locations of Monuments in the Field Using Global Positioning System Device
 00:59
Uncertainty: Overview
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:26
Errors in Global Positioning System
 01:20
Calibration Curves: Linear Least Squares
For data that follow a straight line, the standard method for fitting is the linear...