Weakly and Self-Supervised Class-Agnostic Motion Prediction for Autonomous Driving
Related Experiment Video
Updated: Sep 9, 2025
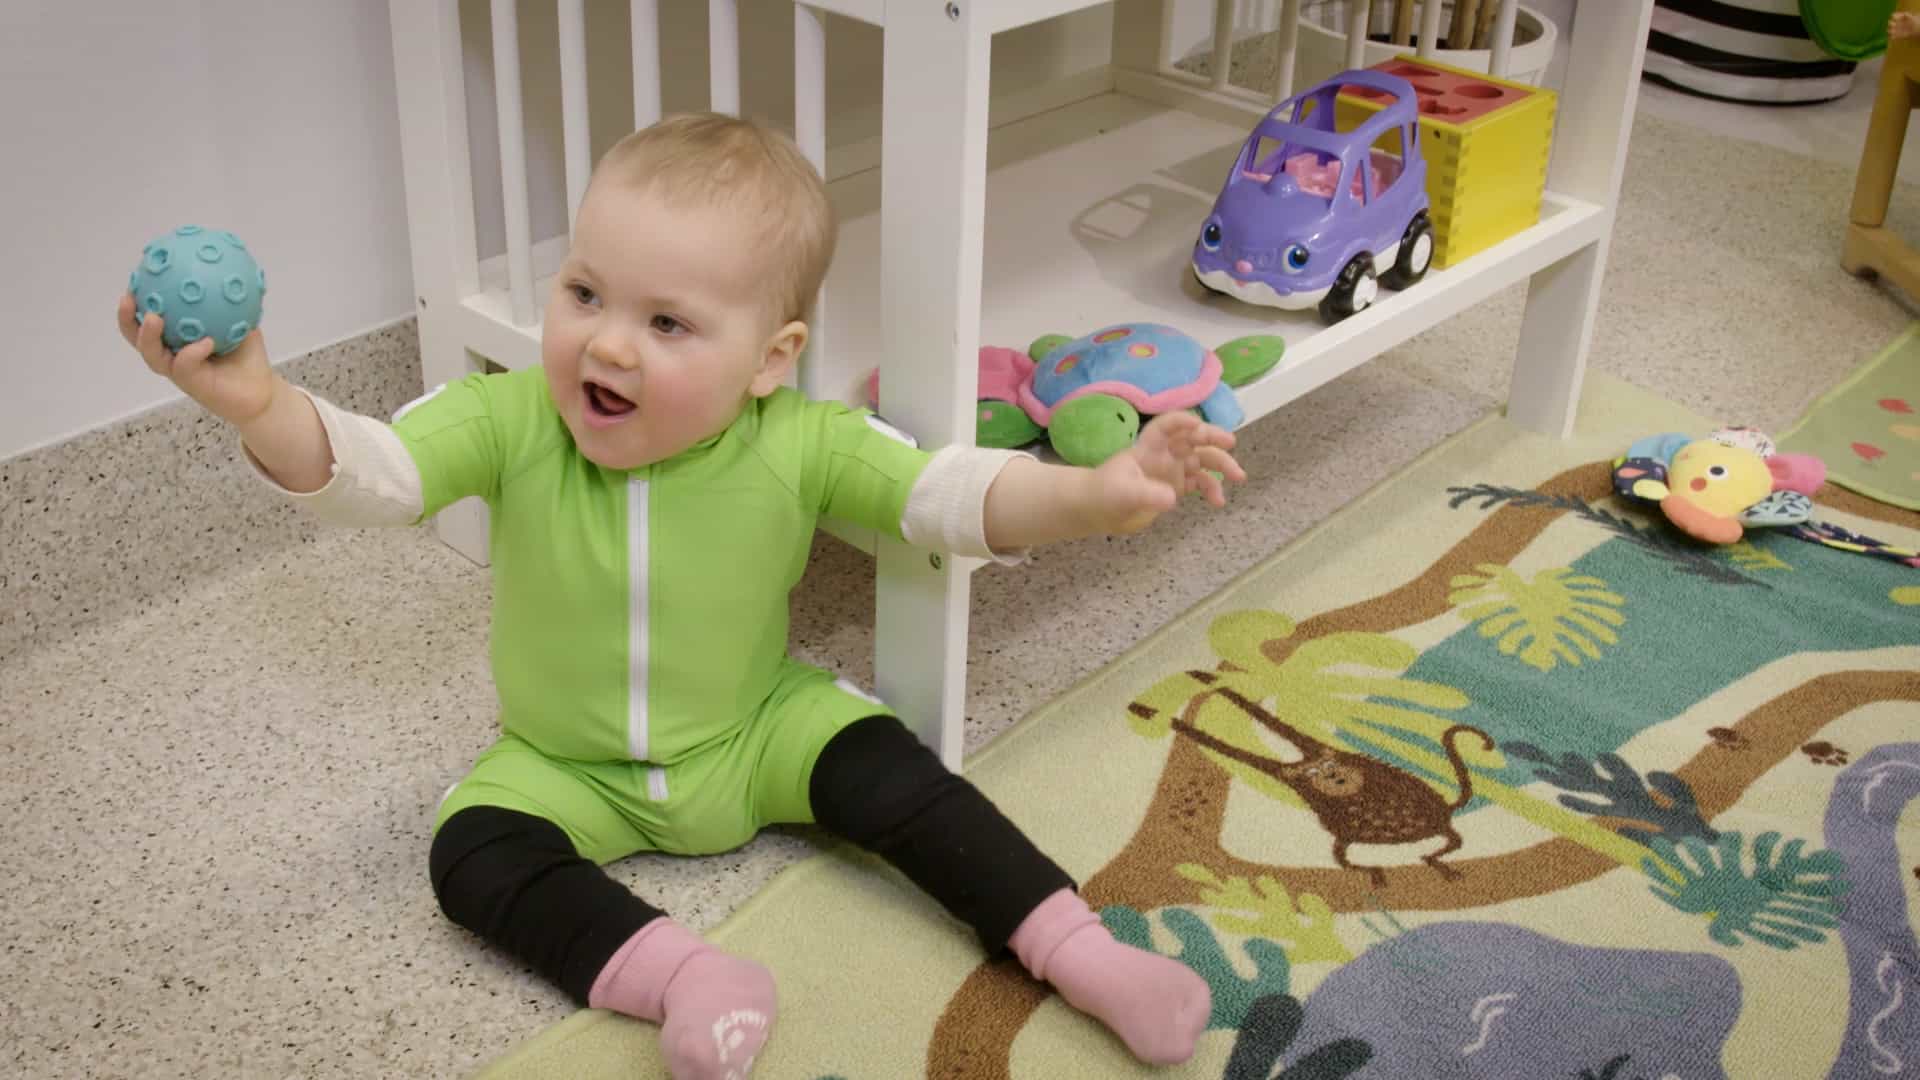
Quantified Assessment of Infant's Gross Motor Abilities Using a Multisensor Wearable
Published on: May 17, 2024

Abstract:
Understanding motion in dynamic environments is critical for autonomous driving, thereby motivating research on class-agnostic motion prediction. In this work, we investigate weakly and self-supervised class-agnostic motion prediction from LiDAR point clouds. Outdoor scenes typically consist of mobile foregrounds and static backgrounds, allowing motion understanding to be associated with scene parsing. Based on this observation, we propose a novel weakly supervised paradigm that replaces motion annotations with fully or partially annotated (1%, 0.1%) foreground/background masks for supervision. To this end, we develop a weakly supervised approach utilizing foreground/background cues to guide the self-supervised learning of motion prediction models. Since foreground motion generally occurs in non-ground regions, non-ground/ground masks can serve as an alternative to foreground/background masks, further reducing annotation effort. Leveraging non-ground/ground cues, we propose two additional approaches: a weakly supervised method requiring fewer (0.01%) foreground/background annotations, and a self-supervised method without annotations. Furthermore, we design a Robust Consistency-aware Chamfer Distance loss that incorporates multi-frame information and robust penalty functions to suppress outliers in self-supervised learning. Experiments show that our weakly and self-supervised models outperform existing self-supervised counterparts, and our weakly supervised models even rival some supervised ones. This demonstrates that our approaches effectively balance annotation effort and performance.


Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:10
Relative Motion Analysis - Acceleration
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...