Related Experiment Video
Updated: Sep 9, 2025


Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
A multi-strategy enhanced secretary bird optimization algorithm for high-precision inverse kinematics in robotic arms
Xuhao Chen1, Nuohan Lin2, Fan Zhang3
1Southwest University, College of Engineering and Technology, Chongqing, China.

Abstract:
The assembly of pyrotechnic grain demands high precision and stability in robotic arm motion control due to the small shell apertures and stringent assembly accuracy requirements. Inverse kinematics is a core technology in robotic arm motion control. This paper constructs a robotic arm inverse kinematics model by reformulating the inverse kinematics problem as a constrained optimization problem and employs a multi-strategy improved Secretary Bird Optimization Algorithm (ISBOA) to achieve high-precision solutions. Aiming at the problems of restricted solution set exploration, easy to fall into local optimization and slow convergence when solving the inverse kinematics of multi-DOF robotic arm by SBOA, this paper introduces the oppositional variational perturbation, golden sine development and evolutionary strategy to optimize the formation of ISBOA, and verifies its effectiveness through numerical experiments. Simulation experiments using 4, 6, and 7-DOF robotic arms are conducted, with inverse solution results analyzed via PCA dimensionality reduction and K-means clustering, demonstrating the superiority of ISBOA in inverse solution diversity. Finally, a MATLAB-CoppeliaSim-UR16e experimental platform is developed to compare ISBOA with traditional analytical and Newton iterative method. Results are analyzed in terms of assembly accuracy, singular position handling, grasping success rate, and assembly success rate, confirming ISBOA's advantages in pyrotechnic grain assembly and its potential for engineering applications.


Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
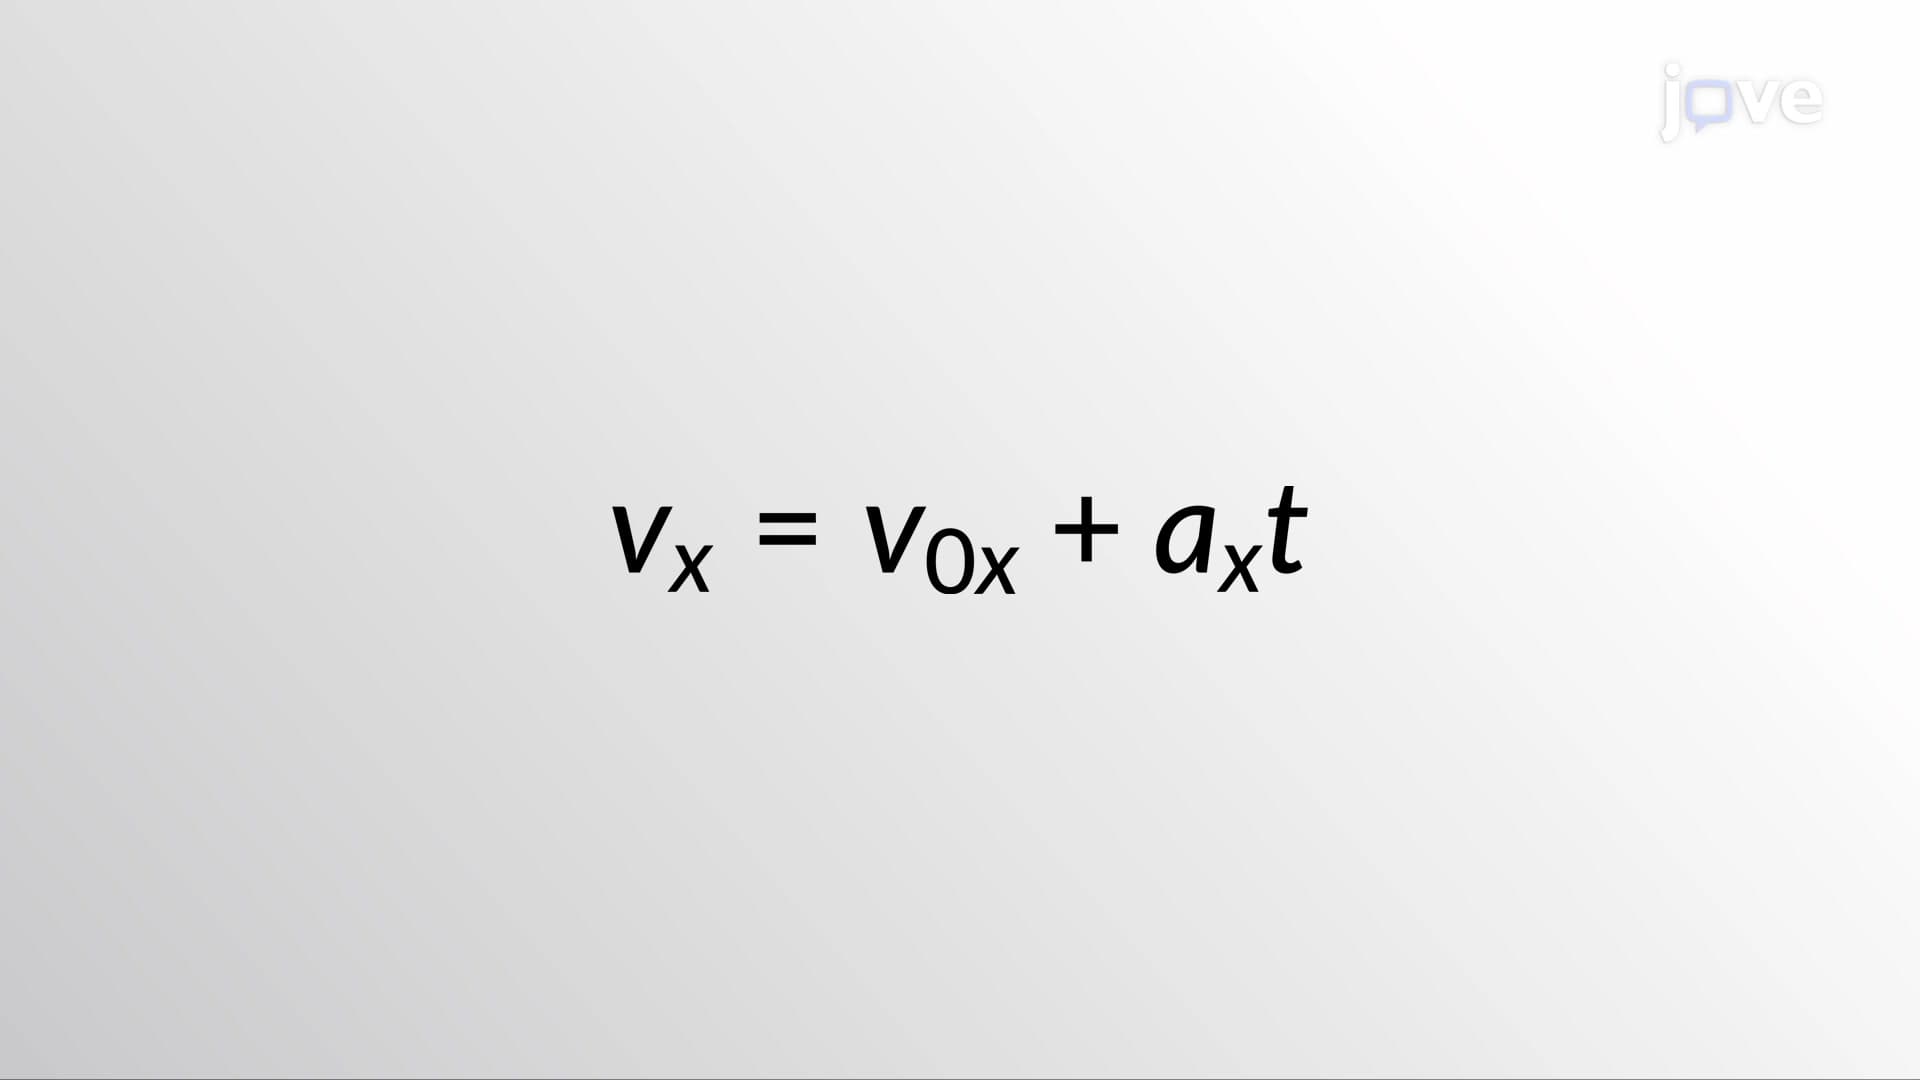 01:26
Kinematic Equations - I